Hi Lcvette,
Following up on your offer in this thread to test the multi-axis plotting / simulation branch — I'd like to put my machine forward as a test case. It's a different geometry from dredivan's MPCNC, so flagging that up front in case it's useful (or not) for what you're prototyping.
Machine: — 4-axis cylindrical/polar additive system tower-crane style. Not a wrapped-rotary gantry; the entire arm rotates around a stationary work area.
Configuration:
LinuxCNC 2.9.8 on Raspberry Pi 5 (Bookworm + PREEMPT_RT)
Mesa 7i96S
KINEMATICS = trivkins coordinates=XBZA kinstype=1 (joints 0–3 = X, B, Z, A)
Axes:
A — base rotation, 0–360° continuous, carries the entire Z tower + X arm + B head
Z — vertical linear, 0–2470 mm, rides up the rotating tower
X — radial linear, 952–2760 mm (radial distance from tower center to B housing — not Cartesian X)
B — end-of-arm rotation, ±90°, rotates about a vertical axis at the end of the X arm; B=0 means the 652 mm tool arm is aligned with the X arm (radially outward)
G-code is pre-computed in polar/cylindrical space by the CAM post-processor and emitted as dense waypoints in G93 inverse-time.
Sample line:
G93 G1 X2054.287 Z6 A118.183 B11.055 F423.731
→ B housing at radius 2054.287 mm, height 6 mm, base 118.183° CW, tool arm tilted +11.055° from radial; move duration ≈ 1/423.731 min ≈ 0.14 s.
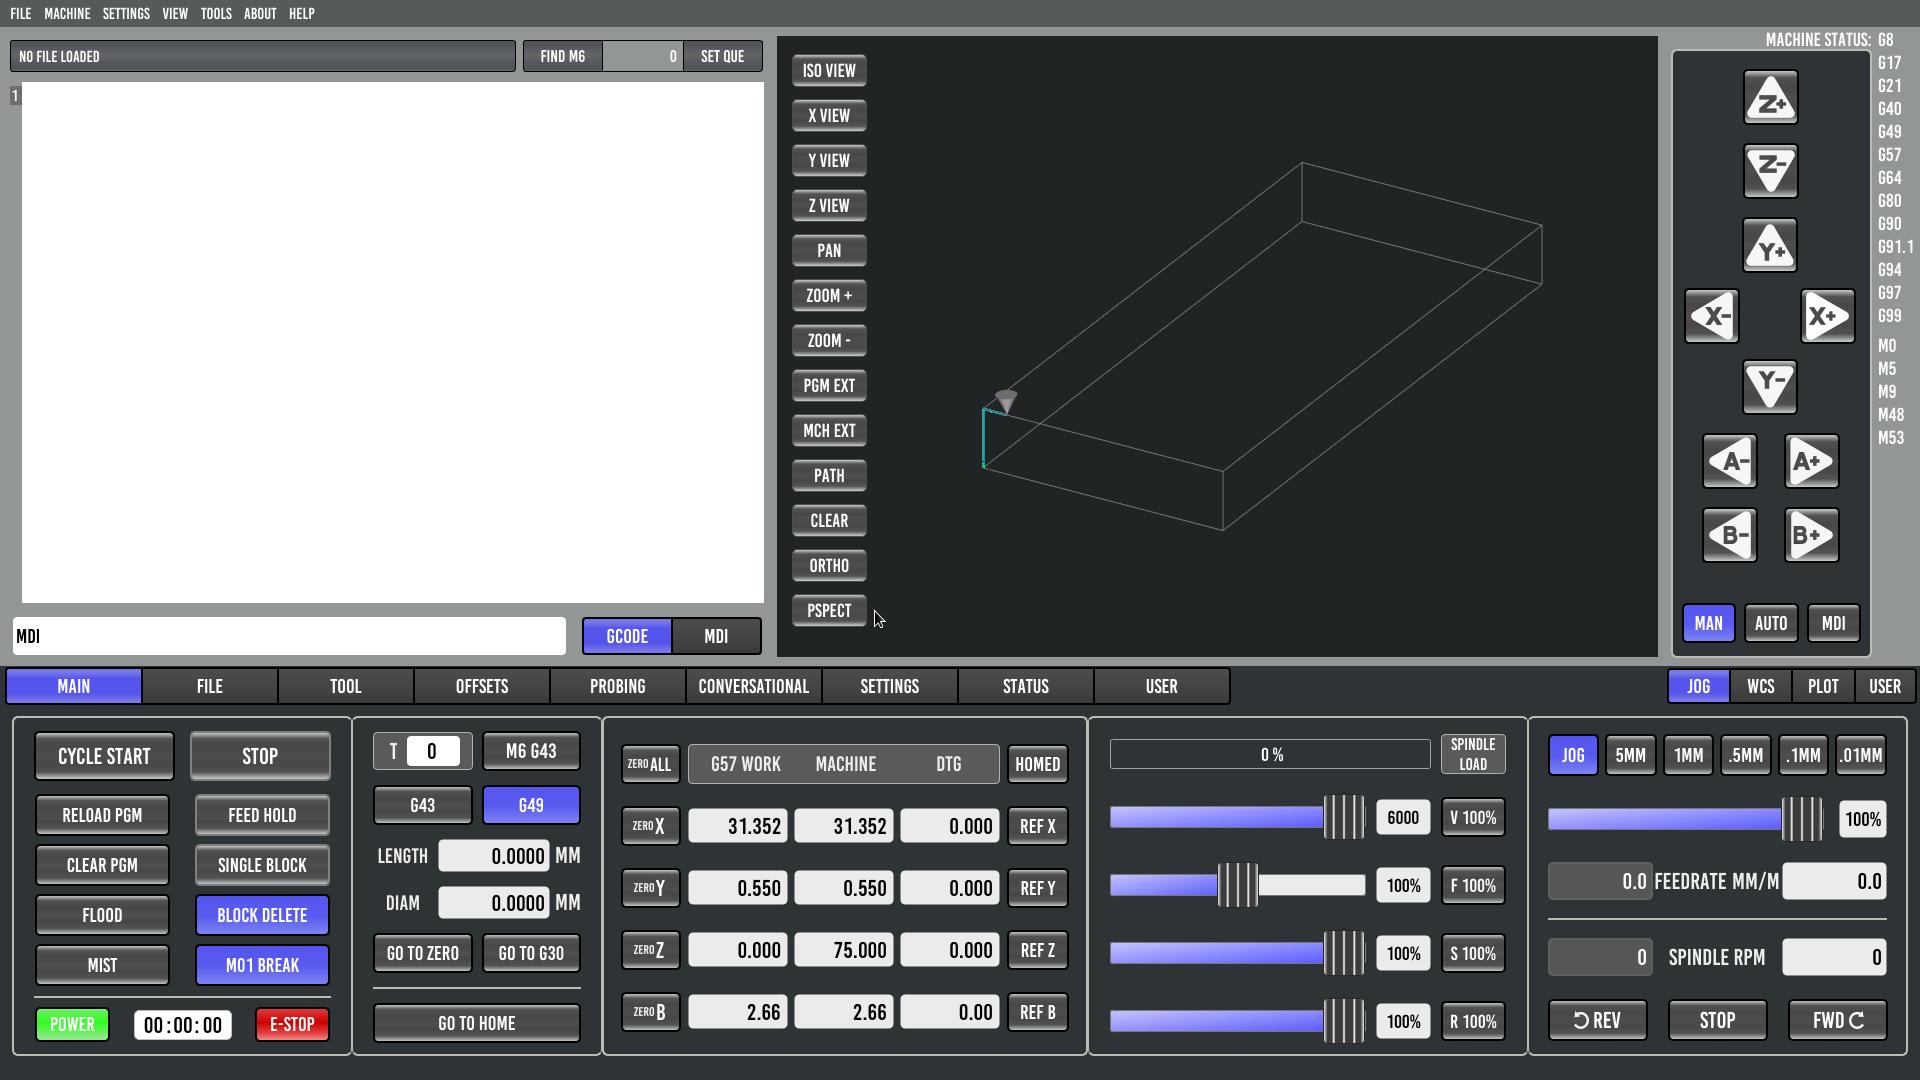
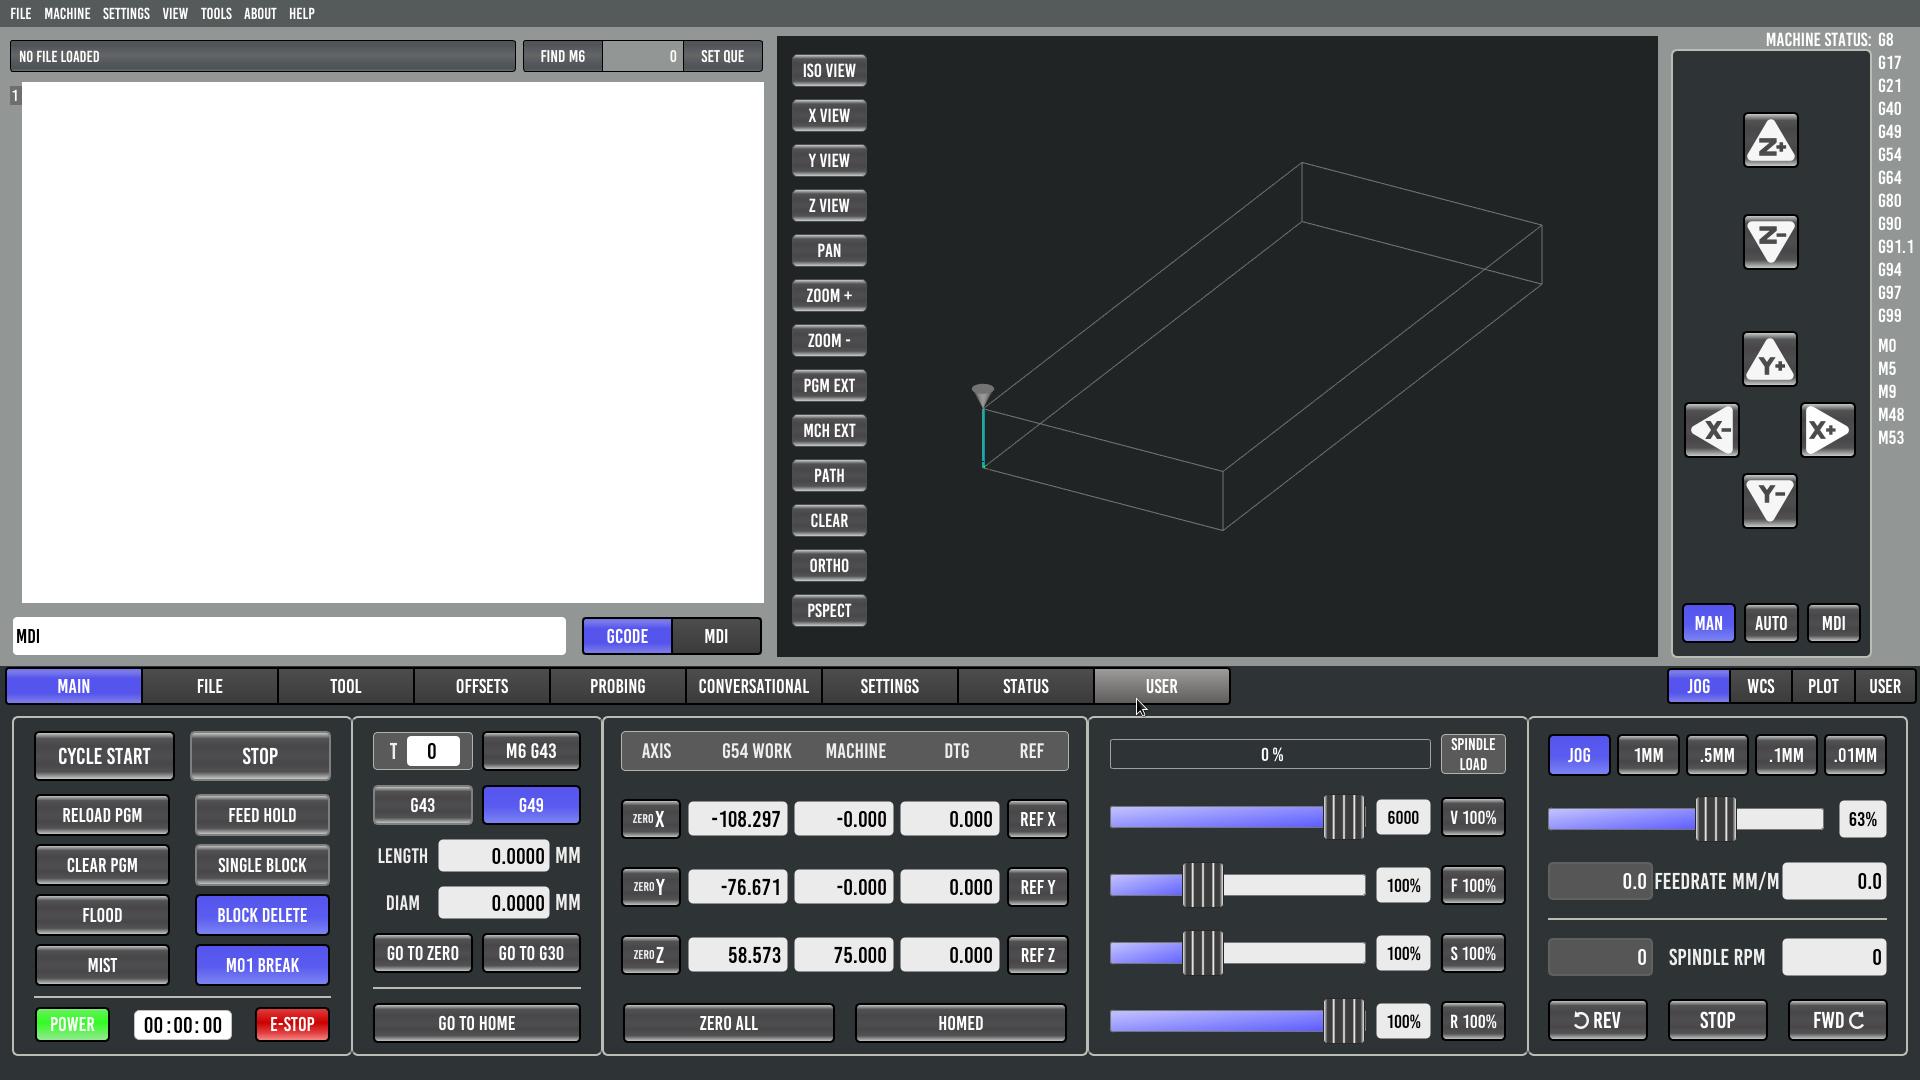
Stock backplots render this as joint space and produce nonsense, which is why a wrapped/transformed preview would be a big deal for us. If the test branch can accept a custom transform (or already exposes a forward-kinematics hook for the canon), I can supply realistic .ngc files and run them on the actual machine.
let me know how I can be useful. Hope we can find a way for me to be a tester for your multi axis plotter!
— David