Analog DC servo very big response delay

More
6 years 11 months ago #150240 by Glite
Sure, I will check that.

Please Log in or Create an account to join the conversation.
More
6 years 11 months ago #150246 by Glite
That's interesting, but this paper suggests to use derivative of jerk instead, do you think it's worth to try? Maybe even both can be used, I've seen that in a different paper too,

Please Log in or Create an account to join the conversation.
More
6 years 11 months ago #150249 by andypugh
Sometimes called "Jounce", if you want to Google for it.

Please Log in or Create an account to join the conversation.

More
6 years 11 months ago - 6 years 11 months ago #150254 by Glite
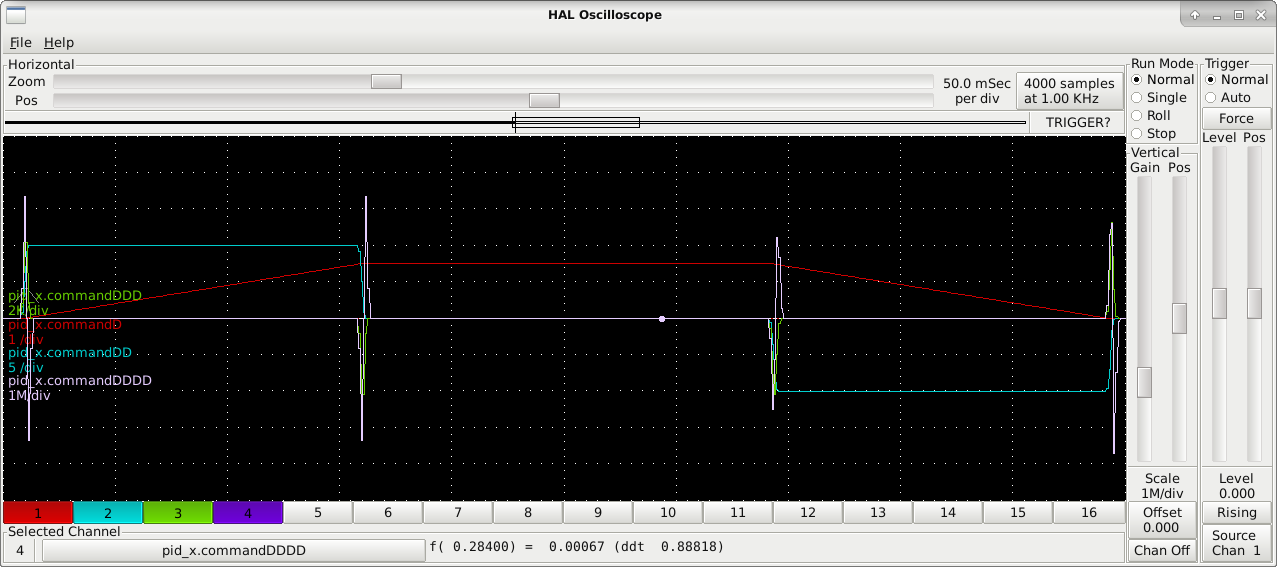
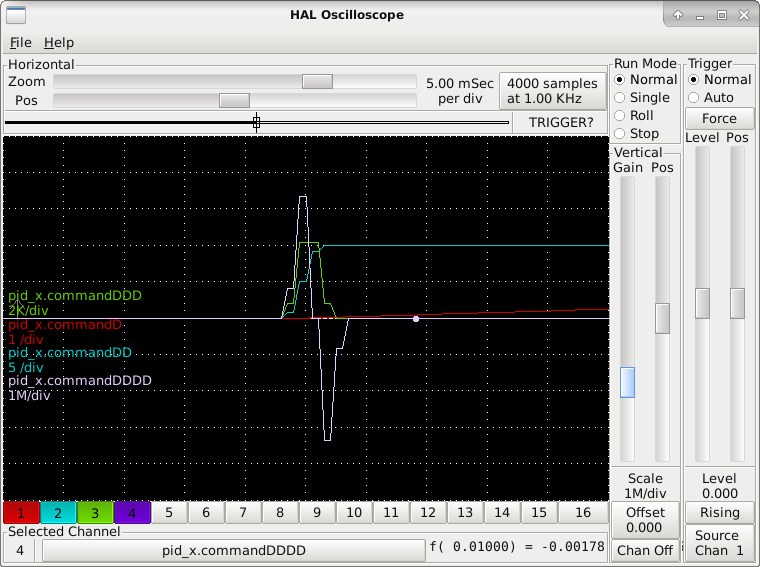
Did a quick test in servo sim:

Not sure about usability of this one(values are ridiculous). If used alone it will just make two spikes in different directions and in my opinion this will cause more troubles than help. If used with jerk, it will increase starting amplitude, but decrease it's duration. Looks like it is not usable with trapezoidal motion profile.
Last edit: 6 years 11 months ago by Glite.

Please Log in or Create an account to join the conversation.

More
6 years 11 months ago #150256 by andypugh
I suspect that once you are doing discrete differentiation on a real system twice you really can't trust the numbers.

Please Log in or Create an account to join the conversation.

More
6 years 11 months ago #150351 by Glite
Have some results on jerk feedforward in work, X axis is a bit too tight and FF3 value used for it was too big. I had to reduce it by half, because machine became too jerky on engraving work. But in overall it did a bit better with one problem on Z axis.
Also I did a check of snap(jounce) feedforward, values for it were 10^-9, but it didn't help in any way, increasing it only did worse.

Please Log in or Create an account to join the conversation.

Time to create page: 0.338 seconds
Powered by Kunena Forum
