
- Posts: 66
- Thank you received: 37
DIY Robot Kinematic parameters,
- emresensoy
- Topic Author
- Offline
- Senior Member
-

Less
More
2 months 2 weeks ago #348694
by emresensoy
DIY Robot Kinematic parameters, was created by emresensoy
Hello everyone,
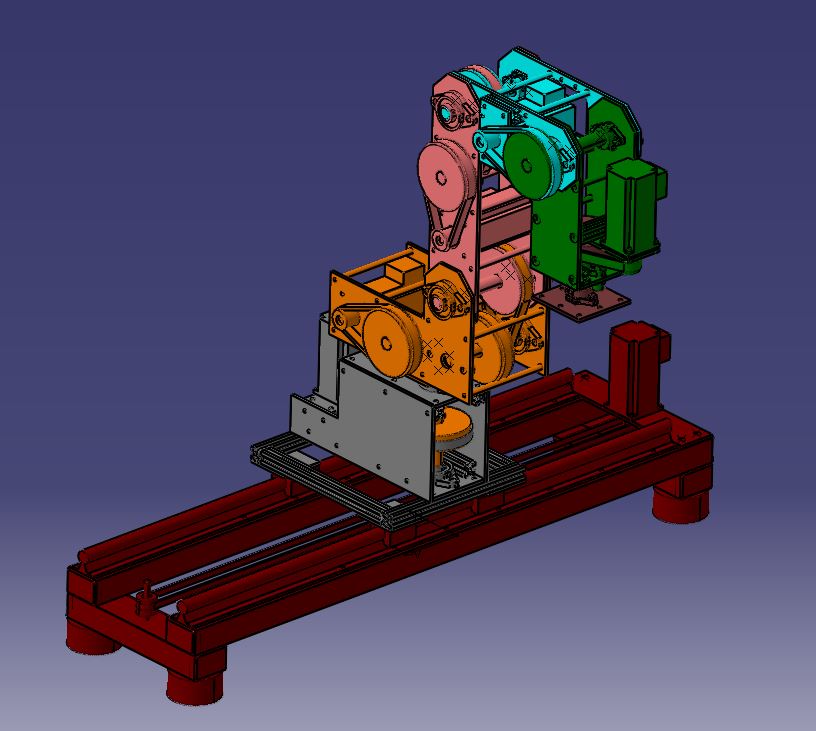
I'm working on a robot. There are some errors, and I want to verify the DH parameters to be sure. What should the axis placements and DH parameters of the robot, whose drawing is below, be?
I'm using Genserkins.
I'm working on a robot. There are some errors, and I want to verify the DH parameters to be sure. What should the axis placements and DH parameters of the robot, whose drawing is below, be?
I'm using Genserkins.

Please Log in or Create an account to join the conversation.
- NWE
-
- Offline
- Elite Member
-

Less
More
- Posts: 271
- Thank you received: 84
2 months 2 weeks ago #348703
by NWE
Replied by NWE on topic DIY Robot Kinematic parameters,
Looking at the drawing, it seems to be missing 1 degree of freedom. Is this intentional? Or am I overlooking something?
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
2 months 2 weeks ago #348707
by Aciera
Replied by Aciera on topic DIY Robot Kinematic parameters,
As NWE has already commented, 'genserkins' assumes 6 axes (yours seems to be missing the forearm twist).
There is a kinematic in linuxcnc for a 'scorbot er3' which looks like it might be adaptable for your case:
github.com/LinuxCNC/linuxcnc/blob/master...atics/scorbot-kins.c
There is a kinematic in linuxcnc for a 'scorbot er3' which looks like it might be adaptable for your case:
github.com/LinuxCNC/linuxcnc/blob/master...atics/scorbot-kins.c
Please Log in or Create an account to join the conversation.
- emresensoy
- Topic Author
- Offline
- Senior Member
-
Less
More
- Posts: 66
- Thank you received: 37
2 months 2 weeks ago #348715
by emresensoy
Replied by emresensoy on topic DIY Robot Kinematic parameters,
I forgot to mention. I'm calculating the 6th axis as a dummy axis.NWE post=348703 userid=46071Looking at the drawing, it seems to be missing 1 degree of freedom. Is this intentional? Or am I overlooking something?
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
2 months 2 weeks ago - 2 months 2 weeks ago #348733
by Aciera
Replied by Aciera on topic DIY Robot Kinematic parameters,
Suggestion for modified DH parameters as used in 'genserkins'
Note that your physical robot will need to have the same pose for J{0,1,2,3,4,5}=0 and the same joint rotation sense as in the DH model drawn below:

Note that your physical robot will need to have the same pose for J{0,1,2,3,4,5}=0 and the same joint rotation sense as in the DH model drawn below:
Last edit: 2 months 2 weeks ago by Aciera.
Please Log in or Create an account to join the conversation.
- emresensoy
- Topic Author
- Offline
- Senior Member
-
Less
More
- Posts: 66
- Thank you received: 37
2 months 2 weeks ago #348779
by emresensoy
Replied by emresensoy on topic DIY Robot Kinematic parameters,
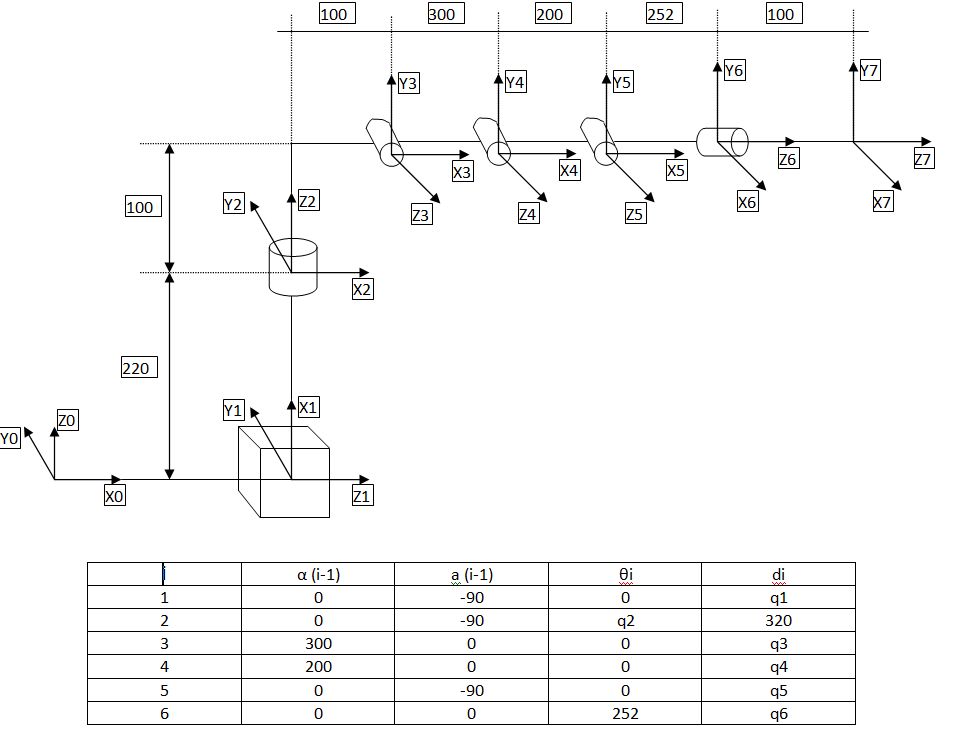
Is the DH parameters below right?
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
2 months 2 weeks ago #348783
by Aciera
Those won't work. First indication is the simple fact that you are mixing distances and angles. Also note that genserkins uses 'modified DH' parameters not the standard 'DH' parameters.
I already posted the parameters for your robot that should work for your robot, why don't you start by trying those?
Replied by Aciera on topic DIY Robot Kinematic parameters,
Is the DH parameters below right?
Those won't work. First indication is the simple fact that you are mixing distances and angles. Also note that genserkins uses 'modified DH' parameters not the standard 'DH' parameters.
I already posted the parameters for your robot that should work for your robot, why don't you start by trying those?
Please Log in or Create an account to join the conversation.
- emresensoy
- Topic Author
- Offline
- Senior Member
-
Less
More
- Posts: 66
- Thank you received: 37
2 months 2 weeks ago #348784
by emresensoy
Replied by emresensoy on topic DIY Robot Kinematic parameters,
First of all, thank you very much for your interest and support. The diagram you sent already formed my starting point. However, since there is a 90-degree difference between the slider joint and the next joint, I wanted to redo the calculations.
Also, since Genserkins only supports rotary axes, I will not be using it. I will recreate the kinematics according to my system.
Also, since Genserkins only supports rotary axes, I will not be using it. I will recreate the kinematics according to my system.
Please Log in or Create an account to join the conversation.
- emresensoy
- Topic Author
- Offline
- Senior Member
-
Less
More
- Posts: 66
- Thank you received: 37
2 months 2 weeks ago - 2 months 2 weeks ago #348827
by emresensoy
Replied by emresensoy on topic DIY Robot Kinematic parameters,
I made a simulation html with claude
Last edit: 2 months 2 weeks ago by emresensoy.
The following user(s) said Thank You: NWE
Please Log in or Create an account to join the conversation.
Time to create page: 0.313 seconds