
- Posts: 2
- Thank you received: 2
Testers wanted: LinuxCNC on Dynomotion KFLOP and Kogna
- Dynomotion
- Topic Author
- Offline
- New Member
-

Less
More
1 week 4 days ago #350411
by Dynomotion
Testers wanted: LinuxCNC on Dynomotion KFLOP and Kogna was created by Dynomotion
Hi everyone,
We're looking for testers for a new LinuxCNC interface to Dynomotion's KFLOP (USB) and Kogna (Ethernet) motion controllers.
LinuxCNC's G-code interpreter and user interfaces (AXIS, gmoccapy) drive our third-order, jerk-limited trajectory planner (TP3), with velocity, acceleration and jerk limits per axis or per actuator. Motion execution and servo control run on the controller, so the PC needs no realtime kernel. It installs as its own LinuxCNC build in your home folder, beside any LinuxCNC you already have: LinuxCNC 2.10 built from source with four small patches, its realtime motion module replaced by a userspace one that talks to the controller. Initialization and machine functions are C programs on the controller, and a simulation mode runs without hardware.
Demo, LinuxCNC in Debian inside VirtualBox on a Windows PC:
(Please set quality to 1080p for better viewing)
Getting started: the QuickStart covers the VM, the install, the controller firmware and the first runs; on a Debian 13 PC the same install script should do it without the VM. The source is TomKerekes/KMotionX on GitHub , and FEATURES.md lists what works and what does not yet.
This is under development, and we would like to hear how it does on different machines and configurations. Please post in this thread, successes as well as problems: which controller, what you were doing, any error messages and the relevant configuration files, and install.log for installation problems.
Thanks for helping us test it!
Tom Kerekes
Dynomotion, Inc.
We're looking for testers for a new LinuxCNC interface to Dynomotion's KFLOP (USB) and Kogna (Ethernet) motion controllers.
LinuxCNC's G-code interpreter and user interfaces (AXIS, gmoccapy) drive our third-order, jerk-limited trajectory planner (TP3), with velocity, acceleration and jerk limits per axis or per actuator. Motion execution and servo control run on the controller, so the PC needs no realtime kernel. It installs as its own LinuxCNC build in your home folder, beside any LinuxCNC you already have: LinuxCNC 2.10 built from source with four small patches, its realtime motion module replaced by a userspace one that talks to the controller. Initialization and machine functions are C programs on the controller, and a simulation mode runs without hardware.
Demo, LinuxCNC in Debian inside VirtualBox on a Windows PC:
(Please set quality to 1080p for better viewing)
Getting started: the QuickStart covers the VM, the install, the controller firmware and the first runs; on a Debian 13 PC the same install script should do it without the VM. The source is TomKerekes/KMotionX on GitHub , and FEATURES.md lists what works and what does not yet.
This is under development, and we would like to hear how it does on different machines and configurations. Please post in this thread, successes as well as problems: which controller, what you were doing, any error messages and the relevant configuration files, and install.log for installation problems.
Thanks for helping us test it!
Tom Kerekes
Dynomotion, Inc.
The following user(s) said Thank You: tommylight, COFHAL
Please Log in or Create an account to join the conversation.
- Dynomotion
- Topic Author
- Offline
- New Member
-
Less
More
- Posts: 2
- Thank you received: 2
4 hours 54 minutes ago #350582
by Dynomotion
Replied by Dynomotion on topic Testers wanted: LinuxCNC on Dynomotion KFLOP and Kogna
For existing Dynomotion KMotionCNC Users there is now a migration tool that can mostly convert a KMotionCNC configuration into a LinuxCNC configuration.
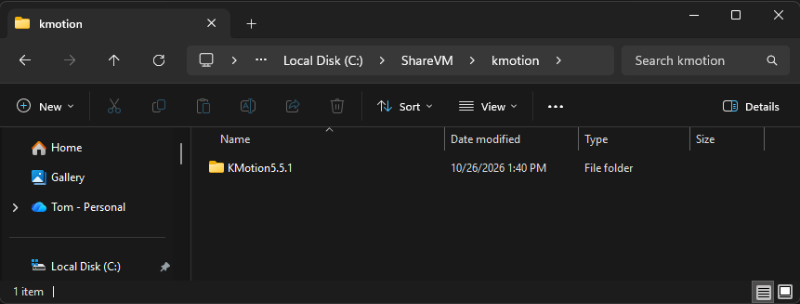
The Debian VB has a shared folder with Windows. Copy your KMotion installation to that folder. If your configuration references files outside of the installation folder copy those folders also. It is normally C:\ShareVM\kmotion
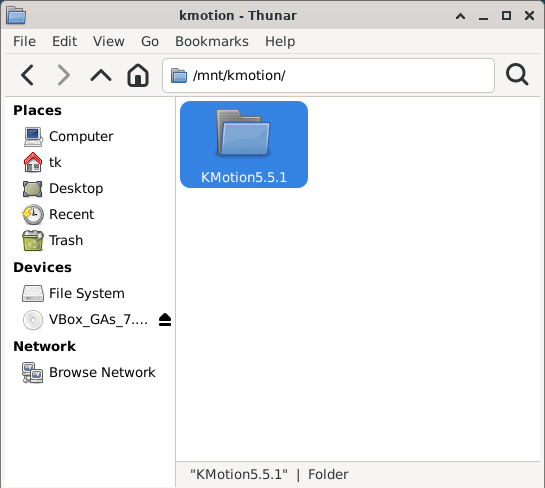
In Linux it is normally /mnt/kmotion
There is a desktop icon in Linux for the migration tool
Run the migration tool and it should find the configuration to convert. If there is more than one found it will ask you to choose. It will also ask for a name for the configuration. Here we entered TK
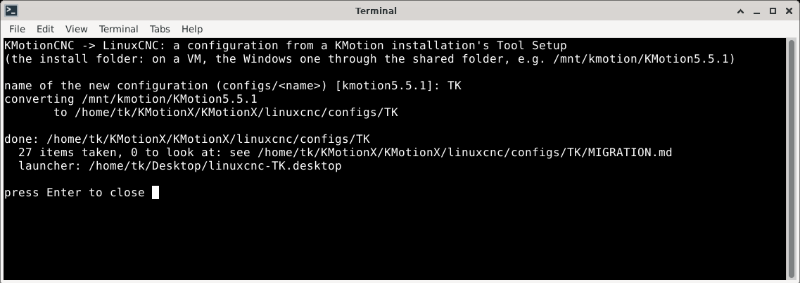
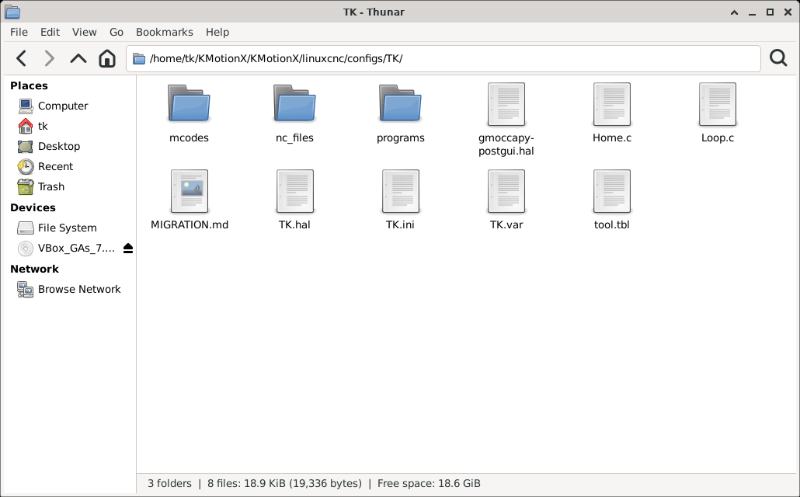
In this case the LinuxCNC Configuration is placed at /home/tk/KMotionX/KMotionX/linuxcnc/configs/TK/
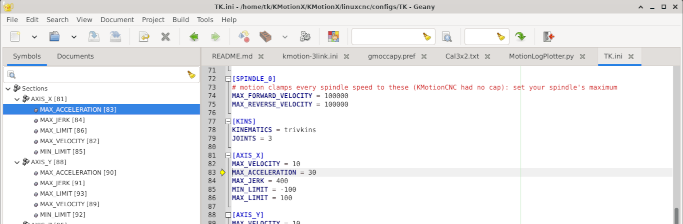
Note that the KMotionCNC settings such as X Acceleration has been migrated into the ini file
A Desktop Icon will be created to run LinuxCNC with the new Configuration
See Video - set Quality to 1080p or higher for best viewing
The Debian VB has a shared folder with Windows. Copy your KMotion installation to that folder. If your configuration references files outside of the installation folder copy those folders also. It is normally C:\ShareVM\kmotion
In Linux it is normally /mnt/kmotion
There is a desktop icon in Linux for the migration tool
Run the migration tool and it should find the configuration to convert. If there is more than one found it will ask you to choose. It will also ask for a name for the configuration. Here we entered TK
In this case the LinuxCNC Configuration is placed at /home/tk/KMotionX/KMotionX/linuxcnc/configs/TK/
Note that the KMotionCNC settings such as X Acceleration has been migrated into the ini file
A Desktop Icon will be created to run LinuxCNC with the new Configuration
See Video - set Quality to 1080p or higher for best viewing
Please Log in or Create an account to join the conversation.
Moderators: PCW, jmelson
Time to create page: 0.140 seconds