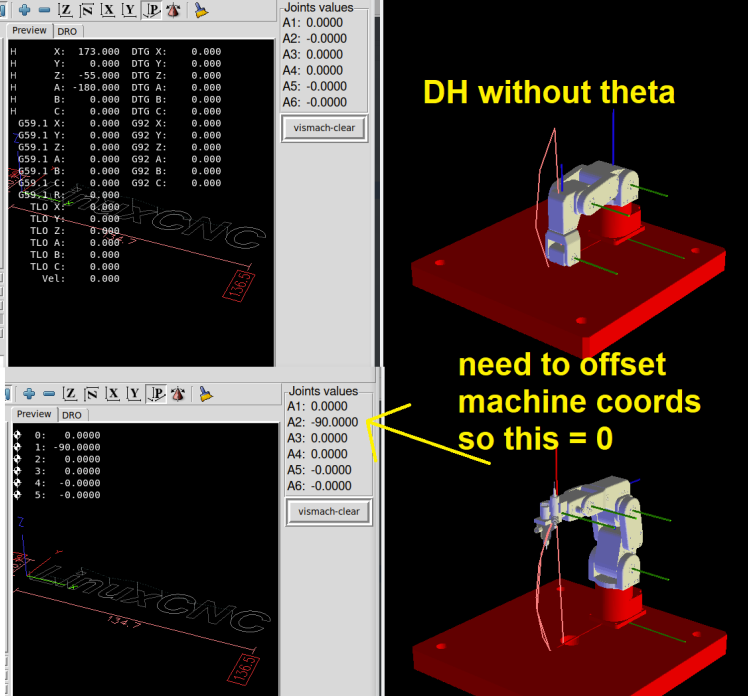
robot joint offsets required to overcome internal absolute encoder

More
4 years 2 months ago - 4 years 2 months ago #249821 by ftree
Hi!

I now have the DH params working well.

However as LinuxCNC does not see theta values I need to offset joint1 by 90 degrees at startup so that the robot posture is a true representation  to the encoders or real word position/posture.  I can't do G5* as internally the robot limits movement to -70/+90.  I need to add 90 to the encoder value before it gets to joint.1.motor-pos-fb - is there some motor or other offset feature in the ini file I can use here?

Best practice for this?


Last edit: 4 years 2 months ago by ftree.

Please Log in or Create an account to join the conversation.

More
4 years 2 months ago - 4 years 2 months ago #249824 by ftree
Code:
loadrt sum2 count=1 addf sum2.0 servo-thread setp                   sum2.0.in0 90.0 net a2-enc-fb       => sum2.0.in1 net a2-enc-fb-os    <= sum2.0.out  

can i use this somehow with a fake encoder for sim?
Last edit: 4 years 2 months ago by ftree.

Please Log in or Create an account to join the conversation.

More
4 years 2 months ago #249826 by andypugh
I don't think that you need a fake encoder, just use the sum2 output where needed.

Please Log in or Create an account to join the conversation.

More
4 years 2 months ago - 4 years 2 months ago #249831 by ftree
setp    a2-offset.offset 90
net     a2-pos-cmd            joint.1.motor-pos-cmd       a2-offset.in
net     a2-pos-cmd-comp       a2-offset.out               
net     a2-pos-fb-comp        a2-offset.fb-out            joint.1.motor-pos-fb

# --- closedloop signals ---
net a1-pos-cmd      joint.0.motor-pos-cmd  => joint.0.motor-pos-fb
# net a2-pos-cmd      joint.1.motor-pos-cmd  => joint.1.motor-pos-fb
net a3-pos-cmd      joint.2.motor-pos-cmd  => joint.2.motor-pos-fb
net a4-pos-cmd      joint.3.motor-pos-cmd  => joint.3.motor-pos-fb
net a5-pos-cmd      joint.4.motor-pos-cmd  => joint.4.motor-pos-fb
net a6-pos-cmd      joint.5.motor-pos-cmd  => joint.5.motor-pos-fb
Last edit: 4 years 2 months ago by ftree.

Please Log in or Create an account to join the conversation.

More
4 years 2 months ago - 4 years 2 months ago #249832 by ftree
then join up a2-pos-fb-comp with gui?

net :j0 <= joint.0.pos-fb => pyvcp.joint0 => meca500gui.joint1

# fix me change to a2-pos-fb-comp ??

net :j1 <= joint.1.pos-fb => pyvcp.joint1 => meca500gui.joint2

net :j2 <= joint.2.pos-fb => pyvcp.joint2 => meca500gui.joint3
net :j3 <= joint.3.pos-fb => pyvcp.joint3 => meca500gui.joint4
net :j4 <= joint.4.pos-fb => pyvcp.joint4 => meca500gui.joint5
net :j5 <= joint.5.pos-fb => pyvcp.joint5 => meca500gui.joint6

#net :vismach-clear <= pyvcp.vismach-clear => vismach.plotclear


Sadly I don't understand the arrows too well here in this postgui. How can I link up a2-pos-fb-comp to :j1 else it picks up the non compensated value I think.
Last edit: 4 years 2 months ago by ftree.

Please Log in or Create an account to join the conversation.

More
4 years 2 months ago #249835 by andypugh
The arrows don't do anything, so don't worry about them.

I am not sure about using colons in the signal names.

You don't seem to have the actual encoder feedback anywhere in the nets.

Please Log in or Create an account to join the conversation.

Time to create page: 0.164 seconds
Powered by Kunena Forum