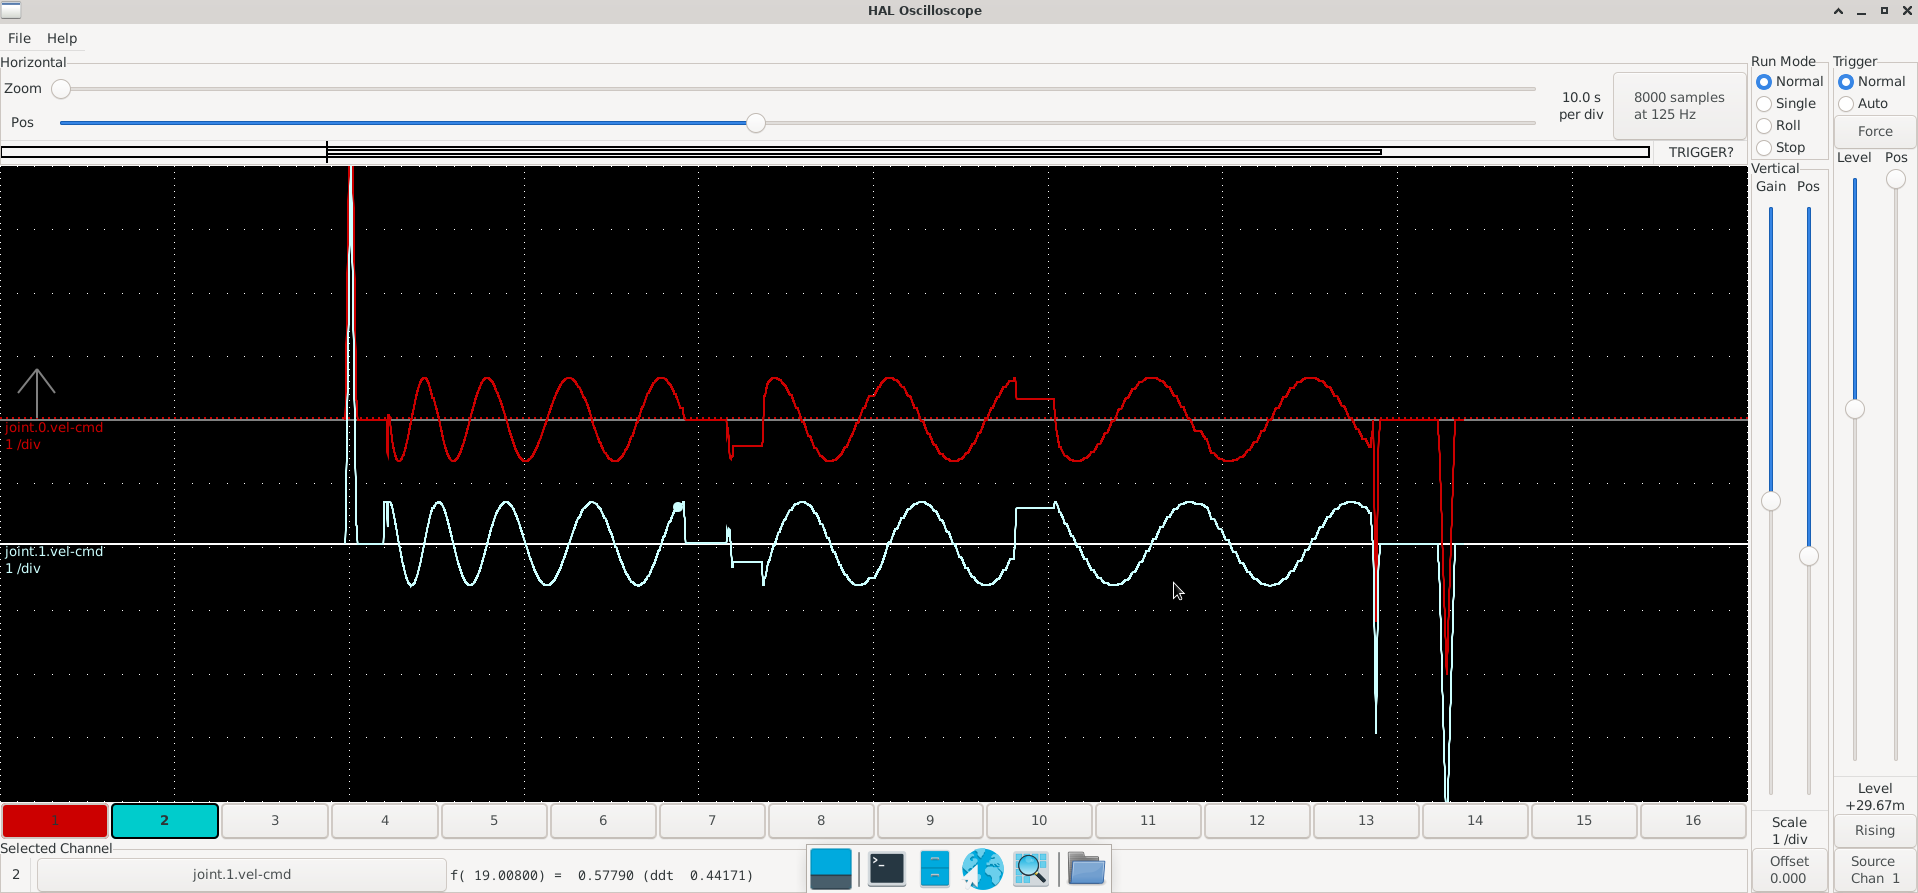
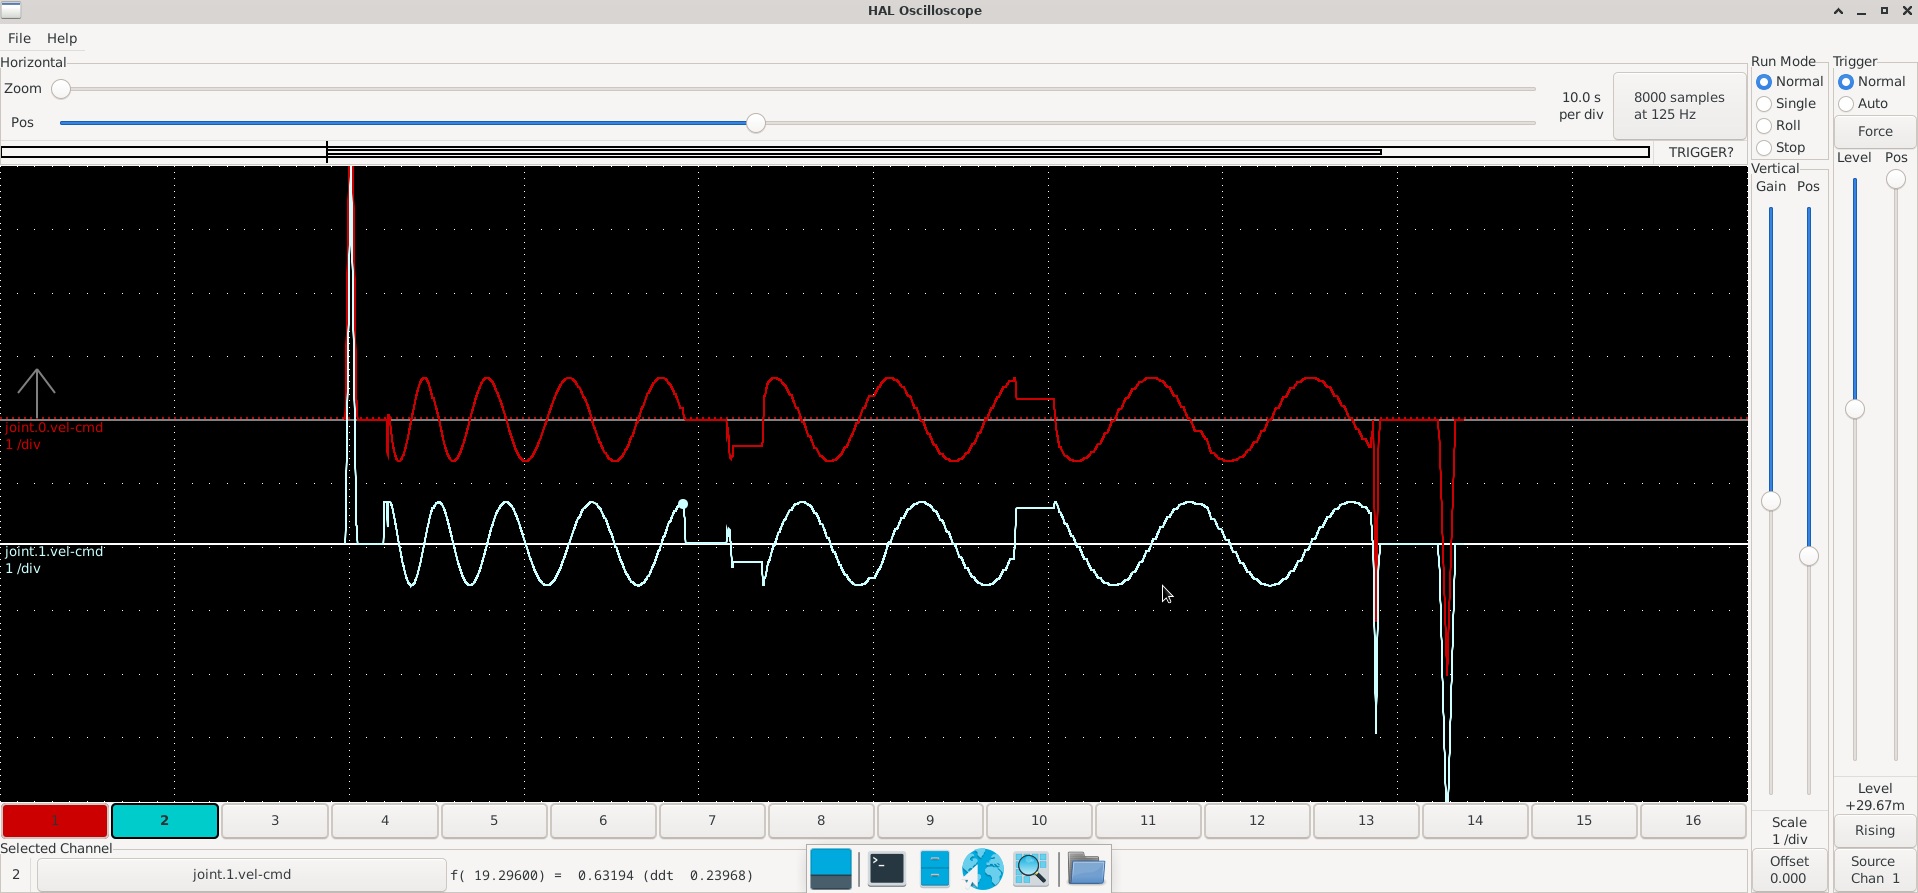
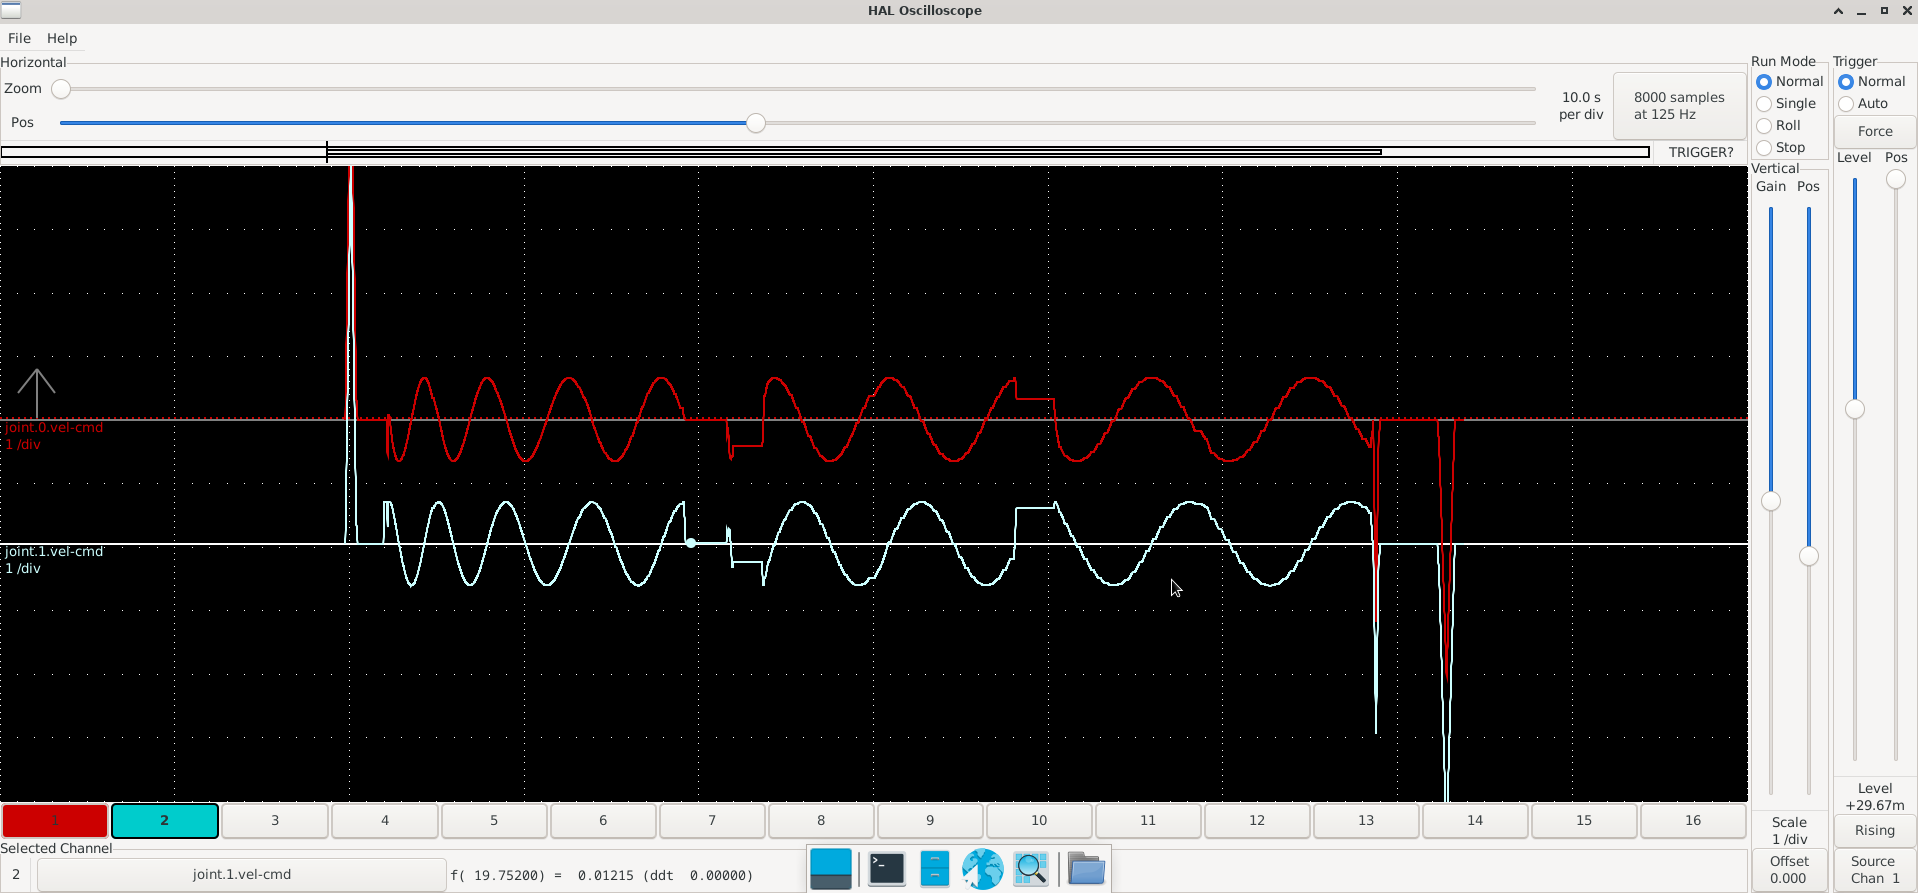
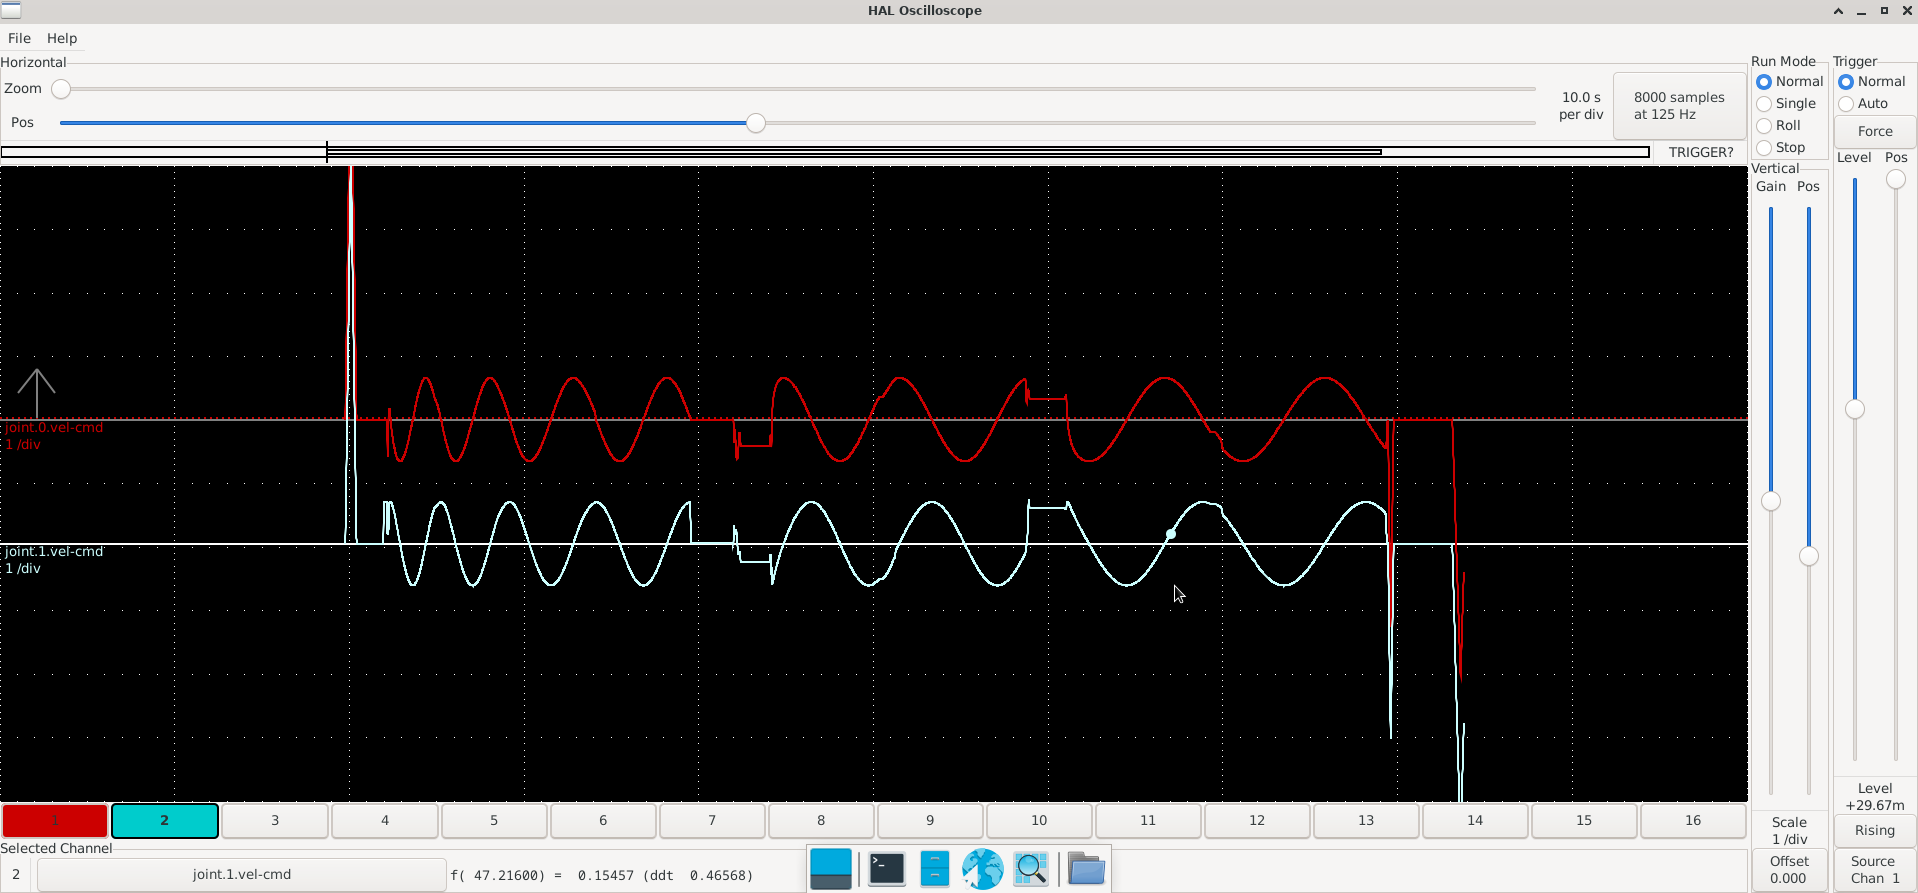
hello gentelmen,
Does somebody have time to help me tested some behaviour of the actual trajectory planner(trapeziodal)? maybe there is bug in the TP and I need more independent observations ...
Its just regular simulation setup with some precise steps to replicate ... the post the picture of the watched scope please
I need help from you please...
If you are ready, create axis.ini sim OR sim axis_mm.ini trivkins simulation UI ... then
- Start Lcnc
- Enable
- home all
- hal scope
- observation time as long as possible but period is fine 40ms
- add joint.0.vel-cmd.. scale 20
- add joint.1.vel-cmd.. scale 20
- split them to they own space
- Load Gcode program(from attachements but watched behaviour is present everywhere)
- hit play button alias program run
- observations the spline created by gcode (nice smooth steady - the first one)
- wait program end OR stop program by program stop/stop radio button
- break point 1(only for repeat command)
- return home G28 or rehome everything
- I press start button again at same code no change, no position change nothing just return to row 1 of gcode
- start program with play radio button
- observations the spline created by gcode (clingy - every other)
- wait program end OR stop program by program stop/stop radio button
- go to breakpoint 1(only for repeat command)
Please paste your scopes ... I hope your velocity splines will be exact same at rerun the gcode!!!
My scope is at rerun different each time ...
many thanks