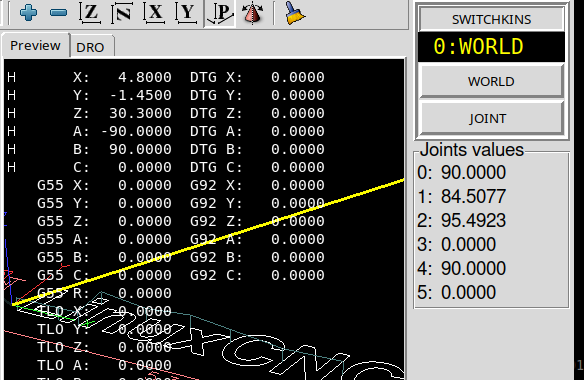
PUMA 200 Robotarm and some Hal/INI issues

More
2 months 3 weeks ago #348590 by Aciera
As for Step2:

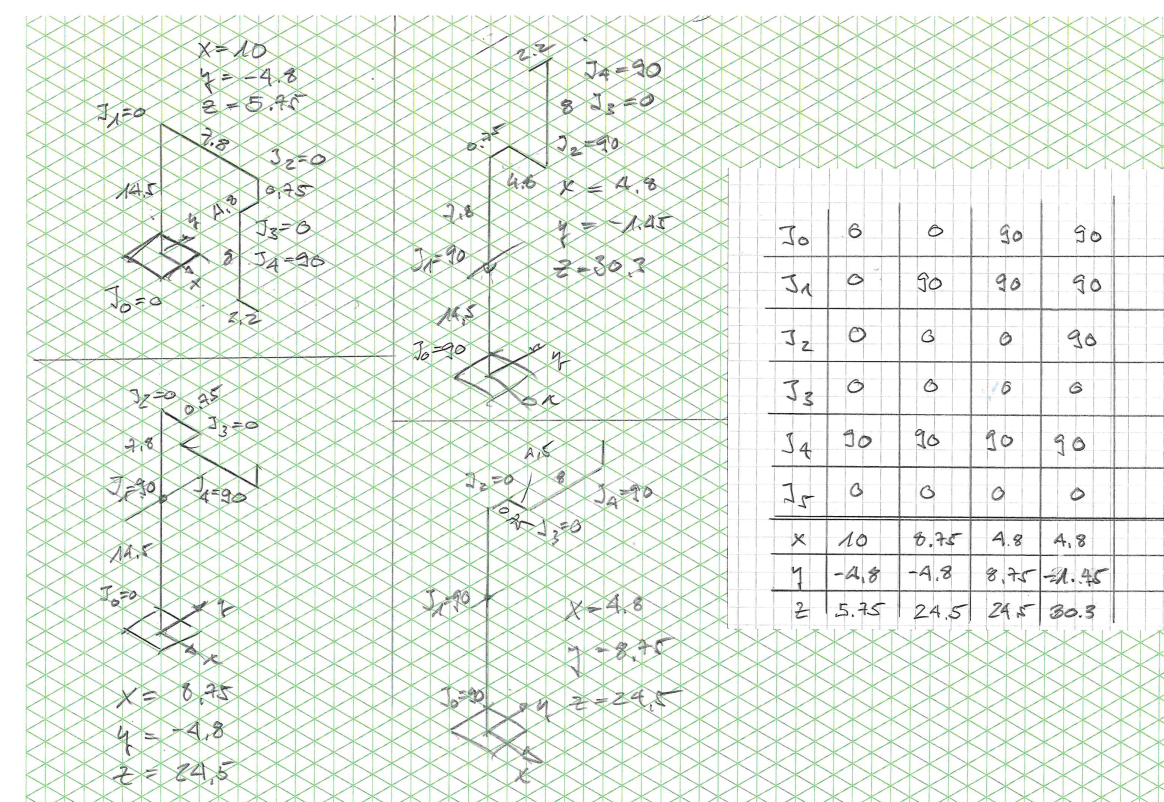
Draw some simple poses and calculate the expected x,y,z coordinates:


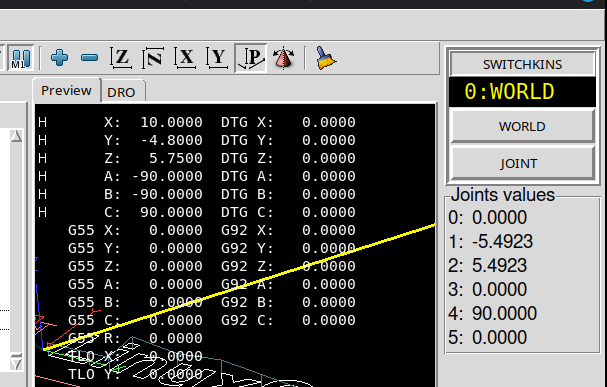
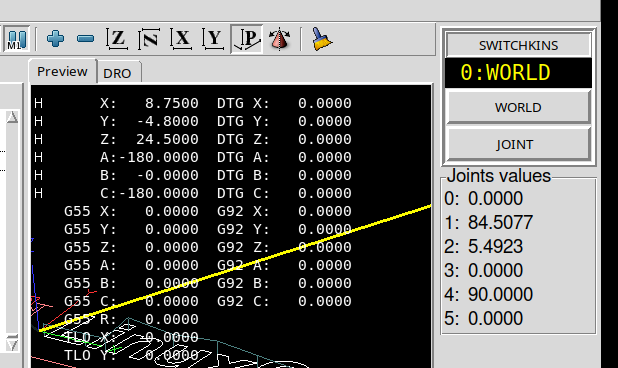
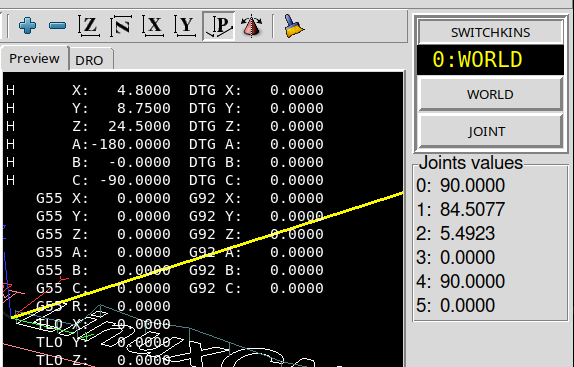
Then create a sim config for genserkins and feed in the derived DH parameters. then test the results by setting up the joint positions as in the chosen poses while keepin the angular offset for J1 and J2 in mind (+- 5.49°) :


The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
2 months 3 weeks ago #348593 by hitchhiker
wow... ok.... i thank you.. i understand now more...

but here are some news.....

today i start making a excel... because i wondering why the gear ratios not fit which i get from unimation.... and then.... i get it... i open the gear from joint 2.. count the teeths... suprise... they changed the gears...

i get gear ratio from a puma 250.. i have a puma 200... .. now i open every gear... and count...

when i start with the robot i done this:

open all covers... check encoders.. wiring.. lables.. all what i can get.

then i start in linux counting form index to index pulse and see what was the counting of a/b. ok i get 250 cpr encoder on joint 1 2 3 and 200 cpr on 4 5 6.

then i start with the motors and angles... i measured with inclinometer. parallel i wrote a mail to stäubli and unimation... stäubli give me contact to rp automation. rp automation share some details with me.. they only have what they have.. so all what i get was stuff for different puma 2xx versions.

i calculated then the scales for each axis... it never fit.. i was thinking ok.. lets stay at the values i measured... but today i start opening the gears and i was suprised.... the teeth counting i get doesnt fit my robot.

if i am done with counting every gear.. i come back and try what you wrote.. but i see my failures and i am happy that you teach it to me because now i understand it better..

thank you!

Please Log in or Create an account to join the conversation.
More
2 months 3 weeks ago - 2 months 3 weeks ago #348618 by hitchhiker
wow.. it works... now i understand my failure with the signs...

interesting part:

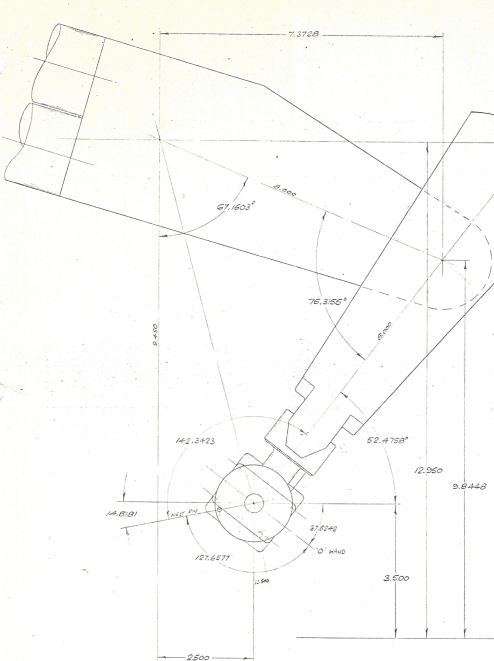
you calculate a different arm length for upper arm.. i got a drawing where the 0.75" are not realy present.

but yes its first time the moves are correct. thats so nice... i was fighting with the right hand rule and know i understand my failure... the rotations arround the X axis are not correct.. and thats why i have the TCP upside down.. and the signs for the d3 and d5....

now i am near to get the real ratios... issue are the encapsulated gearboxes.. my solution... add a second encoder to the outputshaft and work with the index signals of the encoder on the motor to get a start and end point for counting but the mesuring with the incinometer was a good starter.

aciara!!! thank you...!!!!!!!! nice lesson! 

Last edit: 2 months 3 weeks ago by hitchhiker.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
2 months 3 weeks ago #348626 by Aciera
You are very welcome!

you calculate a different arm length for upper arm.. i got a drawing where the 0.75" are not realy present.


Note though that the line from center to center is not parallel to the underside of the upper arm, so there is also a vertical offset when the arm is horizontal. But, yes, the center distance is given here as 8" so you might want to check that on the actual arm and adjust the A2 value accordingly.
The following user(s) said Thank You: NWE

Please Log in or Create an account to join the conversation.

More
2 months 3 weeks ago #348627 by hitchhiker
Right, and up there is also the value of 7.3728 inches. But one thing does stand out to me... the distance to the tabletop remains virtually constant when I move along the X and Y axes.

This was without j2 and j3 +- 5.49
J2 upper arm J3 lower arm.

J5 5. Deg offset:

youtube.com/shorts/0iBH6llVtzk?is=Uy8PDOtG_uMjC4hk

Please Log in or Create an account to join the conversation.

More
2 months 2 weeks ago #348752 by hitchhiker
Hey!

I am back on project.
I played a little bit with the arm.. adjust the backlash/teeth play and get now the correct scales for all joints.

In the next days i will machine a sharpie holder... then i will starting with first trails drawing on cardboard. I checked all movements in world mode.. x y z... and it looks good.. tomorrow i will test with a dial.

For my understanding:
The dh parameters doesnt changed... i must set the arm to different ready position over the homeoffset. Right?

Thanks

Please Log in or Create an account to join the conversation.

Time to create page: 0.371 seconds
Powered by Kunena Forum