This might be the point where I can give my software-expertise to this project

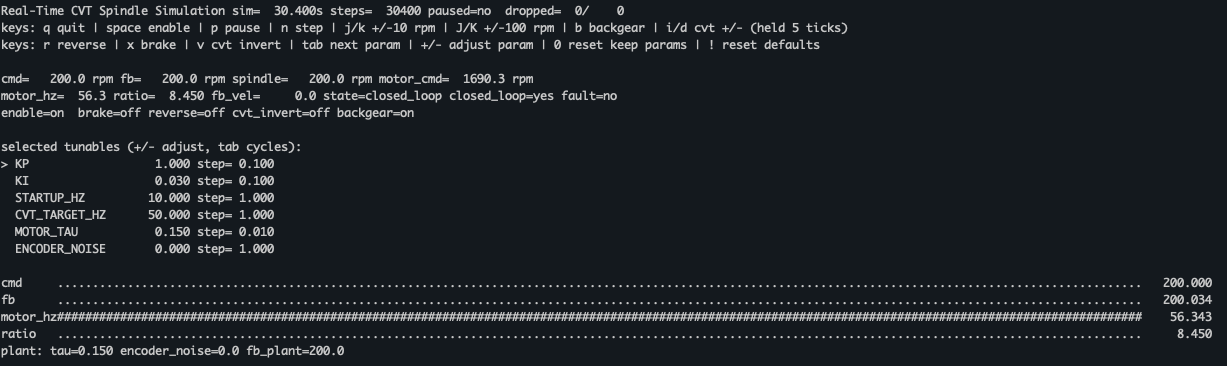
I wrote some software which simulates the spindle control behavior based on the files uploaded here 17.5.2026. I have very little understanding of actual linuxcnc, so take everything with a grain of salt. The simulator is quite crude and it's translated in python, as I do not have access to a physical LinuxCNC machine for now. I'll need some confirmation that it somehow resembles the actual behavior of the Schaublin now before I dig in further. It does look like that the pid works "ok'ish" on low gear, only a minor overshoot, but it's way off on high gear. There's some possibility that the simulator could be useful when developing a state of the art control. I would also say that no extra hardware is needed, many things can be deducted from the spindle speed, cvt end switches and the motor hz.
The thingy is now there, I did not spend too much time on it, it's also mainly vibe-coded. The translation of the .comp logic is in spindle_supervisor_model.py lines 161:582
github.com/heff3/schaublin-cvt-simulator
Easiest way to get it working is to use "uv", it's a modern python virtual environment manager (does not break your machine). AI will help with this one, but on mac the most convenient way is with "brew install uv". Brew is the most common package manager for osx.
After cloning the repository, one should be able to:
uv run python spindle_realtime_simulator.py
q - quits the application (or the usual ctrl+c)
space - starts the motor
k / j - tunes the target spindle rpm
The simulator behaves better once it has run awhile with a few toggles on/off, dunno if the real lathe behaves the same?
ALERT: The real lathe might have insufficient max rpm limit now. For example if one targets 2000rpm, the pid might overshoot it quite a lot.