

- Posts: 2419
- Thank you received: 2349
ROS LinuxCNC Link
5 years 5 months ago - 5 years 5 months ago #209915
by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,
I have now tested the halstreamer. It works excellent.
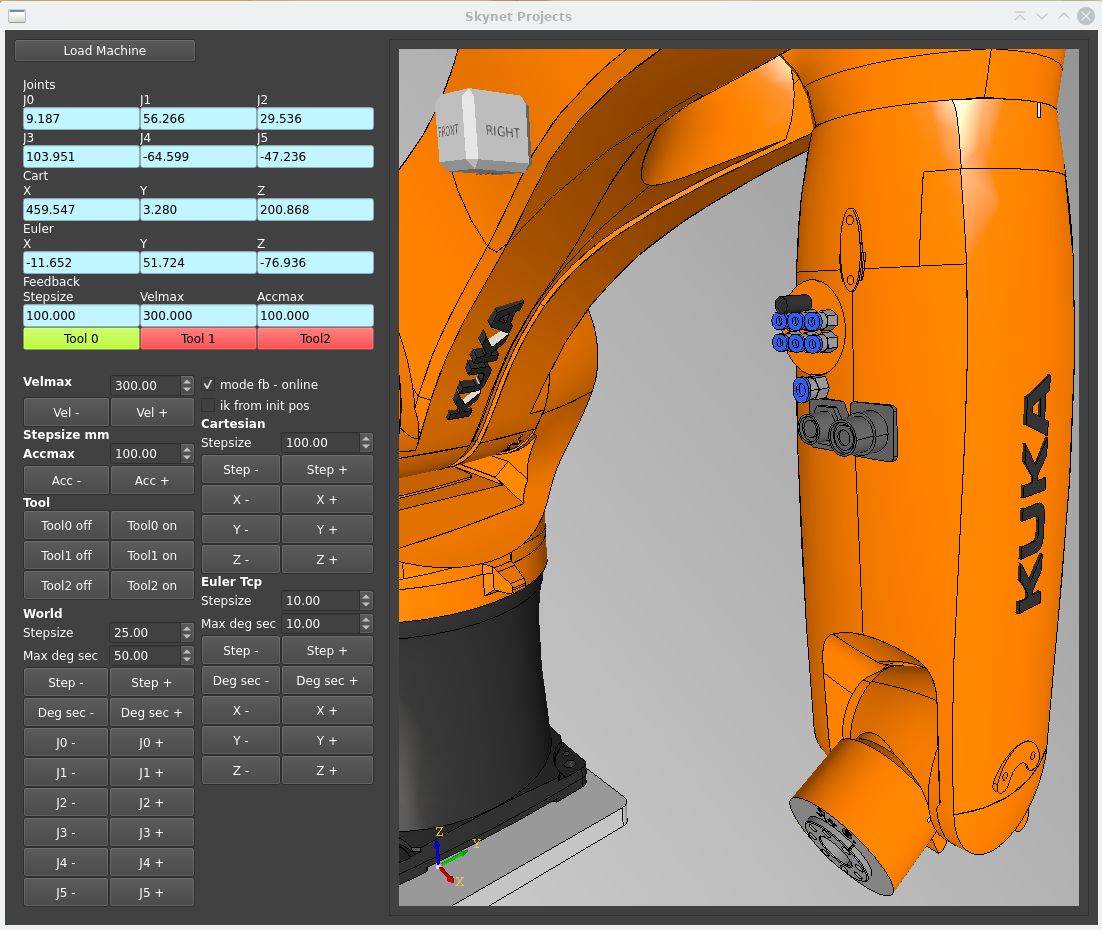
For testing and moving the robot i have created a little program.
This program has under the hood:
- Hal connection ( base threat + servo thread + halstreamer )
- Forward + Inverse interpolation based on kdl
- Respect's joint limits.
- Cartesian s-curve moves, based on this algoritme
- Euler angles rotating at fixed (user defined) degrees a second ( ** cool option ** )
- Joint angles rotating at fixed (user defined) degrees a second. => used when only rotating joints.
- Opencascade cad machine preview, updated by stepgen feedback value's results in realistic motion preview.
- Live mode (hal stream) and demo (playing) mode.
Used hardware :
Ethercat beckhoff + 5us stepper outputs.
Used software :
Linux-cnc source : Linuxcnc at master
Linux software : Linux-11-pro
There was quite a lot to code. This took me 2 day's.
I am quite happy with this result so far. The best kinematic result so far.
Next thing to do:
1. Make a working gripper, wich can open and close in preview.
- Maybe make a program for a piano?
- If you have any request for a program, please post your request.
2. Record the halstreamer movements to a single play-off file, and then execute this file.
3. So far so good. Up to the next day !
* Attached my hal file. It's quite clean.
I have now tested the halstreamer. It works excellent.
For testing and moving the robot i have created a little program.
This program has under the hood:
- Hal connection ( base threat + servo thread + halstreamer )
- Forward + Inverse interpolation based on kdl
- Respect's joint limits.
- Cartesian s-curve moves, based on this algoritme
- Euler angles rotating at fixed (user defined) degrees a second ( ** cool option ** )
- Joint angles rotating at fixed (user defined) degrees a second. => used when only rotating joints.
- Opencascade cad machine preview, updated by stepgen feedback value's results in realistic motion preview.
- Live mode (hal stream) and demo (playing) mode.
Used hardware :
Ethercat beckhoff + 5us stepper outputs.
Used software :
Linux-cnc source : Linuxcnc at master
Linux software : Linux-11-pro
There was quite a lot to code. This took me 2 day's.
I am quite happy with this result so far. The best kinematic result so far.
Next thing to do:
1. Make a working gripper, wich can open and close in preview.
- Maybe make a program for a piano?
- If you have any request for a program, please post your request.
2. Record the halstreamer movements to a single play-off file, and then execute this file.
3. So far so good. Up to the next day !
* Attached my hal file. It's quite clean.
Last edit: 5 years 5 months ago by Grotius.
The following user(s) said Thank You: tommylight
Please Log in or Create an account to join the conversation.

5 years 5 months ago #209921
by Aciera
Replied by Aciera on topic ROS LinuxCNC Link
Nice!
I'd still be very much interested in testing your app on my Mitsubishi robot. But, as discussed earlier, I'd need Dmitry's SSCNET drivers from his nyx branch built in to do so.
I'd still be very much interested in testing your app on my Mitsubishi robot. But, as discussed earlier, I'd need Dmitry's SSCNET drivers from his nyx branch built in to do so.
Please Log in or Create an account to join the conversation.
5 years 5 months ago #209924
by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi Arciera,
github.com/grotius-cnc/linuxcnc
I think it is oke now. I see multiple hal files appearing into the source.


github.com/grotius-cnc/linuxcnc
I think it is oke now. I see multiple hal files appearing into the source.
Please Log in or Create an account to join the conversation.
5 years 5 months ago - 5 years 5 months ago #210467
by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi Arciera,
Did you had a look at the github code, if it compiles?
If not, i have to look at it.
At the moment finishing the mdi commands. Have to do the cartesian mdi.
What's left to do is moving in tool direction, Arciera's request.
I am really impressed by the realtime performance. Later on next week i will make some video's to show it.
Now also showing when joint limit is reached. Then the button color become's red. Implementing this failsafe logic
into the program is quite a lot of work.
For the controls i now have working :
1. joint move, j0,j1,j2,j3,j4,j5 with max deg a second.
2. cart move x,y,z with max lineair speed and acc-dcc in s-curve
3. tcp rotation in euler x,y,z with max deg a second.
4. joint limits
5. mdi joint command. The joint's will end at the same time.
6. live hal mode - demo mode
7. tools
8. realtime position stream in base-thread.
9. testing on ethercat hardware
When the controls are done and everything works how it should. I will integrate the pendant style again.
I got more and more the feeling this is a very good solution. It's just like streaming a netflix movie.

Most of the readers know we have managed to implement the dxfrw library this week with another program.
This break's open a way that we can load 3d dxf files into this program and for example generate a 3d cut path for the robot.
So we can go quite advanched soon !
Did you had a look at the github code, if it compiles?
If not, i have to look at it.
At the moment finishing the mdi commands. Have to do the cartesian mdi.
What's left to do is moving in tool direction, Arciera's request.
I am really impressed by the realtime performance. Later on next week i will make some video's to show it.
Now also showing when joint limit is reached. Then the button color become's red. Implementing this failsafe logic
into the program is quite a lot of work.
For the controls i now have working :
1. joint move, j0,j1,j2,j3,j4,j5 with max deg a second.
2. cart move x,y,z with max lineair speed and acc-dcc in s-curve
3. tcp rotation in euler x,y,z with max deg a second.
4. joint limits
5. mdi joint command. The joint's will end at the same time.
6. live hal mode - demo mode
7. tools
8. realtime position stream in base-thread.
9. testing on ethercat hardware
When the controls are done and everything works how it should. I will integrate the pendant style again.
I got more and more the feeling this is a very good solution. It's just like streaming a netflix movie.
Most of the readers know we have managed to implement the dxfrw library this week with another program.
This break's open a way that we can load 3d dxf files into this program and for example generate a 3d cut path for the robot.
So we can go quite advanched soon !
Last edit: 5 years 5 months ago by Grotius.
Please Log in or Create an account to join the conversation.
5 years 5 months ago #210493
by Aciera
I'm sorry, I have somehow missed your post. I'll try to compile again and report back.
Thanks
Replied by Aciera on topic ROS LinuxCNC Link
Did you had a look at the github code, if it compiles?
I'm sorry, I have somehow missed your post. I'll try to compile again and report back.
Thanks
Please Log in or Create an account to join the conversation.
5 years 5 months ago #210495
by Aciera
Replied by Aciera on topic ROS LinuxCNC Link
Ok, it has compiled successfully.
How do I now start your application?
How do I now start your application?
Please Log in or Create an account to join the conversation.
Time to create page: 0.350 seconds