- LinuxCNC
- General LinuxCNC Questions
- Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface
Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface
- fmueller
- Away
- New Member
-

Less
More
- Posts: 2
- Thank you received: 2
03 Oct 2026 12:54 - 03 Oct 2026 13:27 #350079
by fmueller
Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface was created by fmueller
Hi,
I've been working on a standalone CNC machine simulator for LinuxCNC and have now published the first experimental version.
The main idea is that the simulator does NOT interpret G-code itself.
LinuxCNC remains responsible for G-code interpretation, trajectory planning, coordinate systems, offsets and compensation. The simulator sits behind LinuxCNC where real motion hardware would normally be connected.
Currently I use the original Stepper-Ninja HAL driver and its UDP protocol as the interface:
The important part of this approach is that the simulator sees the motion that LinuxCNC actually sends to the virtual hardware instead of trying to reproduce LinuxCNC's trajectory planner.
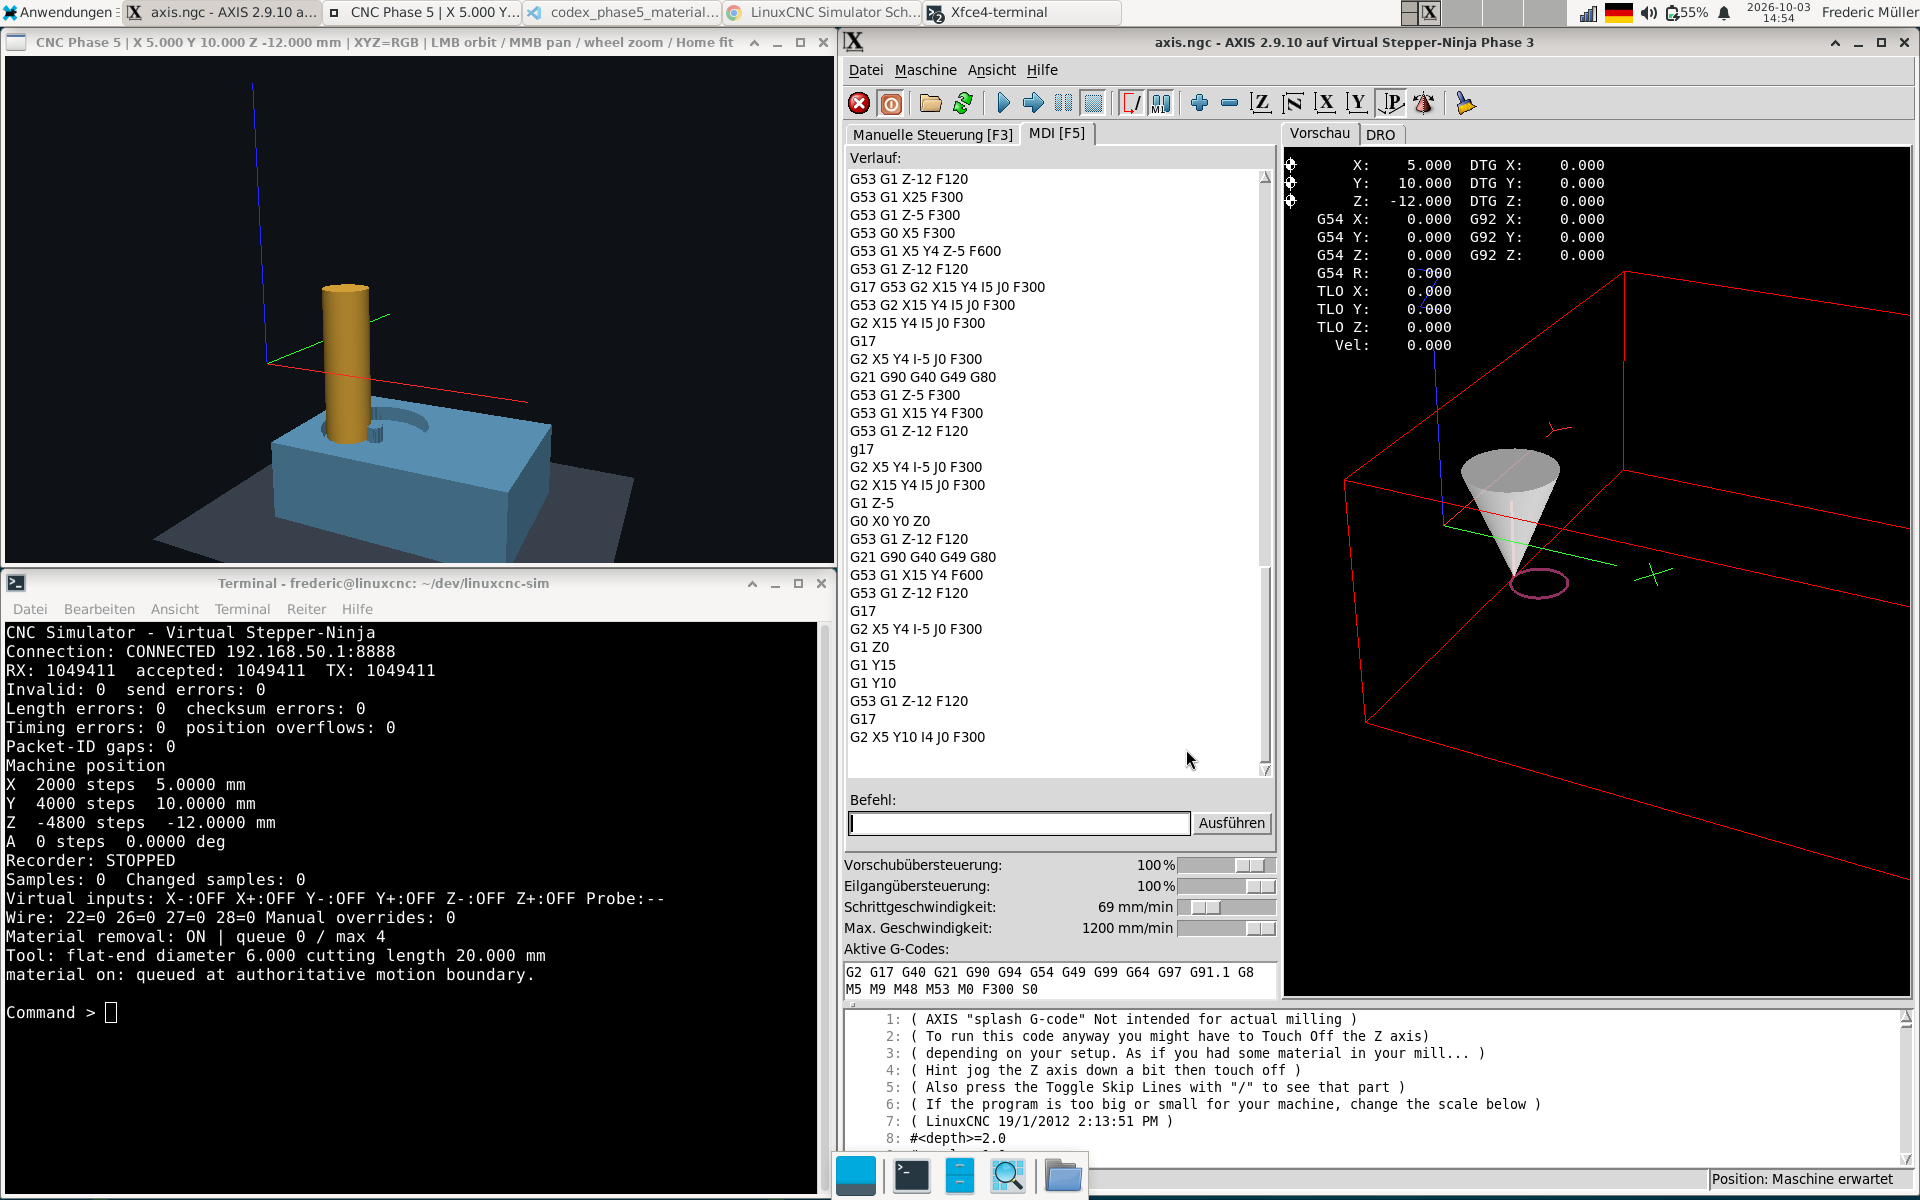
Communication is bidirectional. The simulator can also send virtual machine inputs back to LinuxCNC. I can already use this for limit switches, homing and a simple configurable probe plane.
The current version also contains a sparse voxel workpiece and persistent material removal. Tool movement is processed as continuous swept volumes rather than just removing material at individual sampled positions.
One interesting problem was performance during curved motion. LinuxCNC can generate many small motion segments. Instead of approximating those segments with a larger chord, I batch the actual swept segments for a short time window and calculate the union of their removal volumes. This keeps the resulting voxel state identical while greatly reducing repeated work.
At the moment the simulation is still quite limited:
- flat-end cutter only
- no geometric stock probing yet
- no toolsetter yet
- no spindle/holder model
- no general collision detection
- no rotary material transform
The next area I would like to work on is geometric contact detection. My idea is to use the same contact system later for workpiece probing, a machine-fixed toolsetter and eventually collision detection.
Stepper-Ninja is currently just the interface between LinuxCNC and the simulator. A physical machine does not need to use Stepper-Ninja hardware. I chose it because an existing LinuxCNC HAL driver and a small bidirectional protocol already existed, so I did not have to invent another LinuxCNC hardware interface.
This is my first public release and I consider it experimental development software, not a machine safety system.
Source and v0.1.0:
github.com/FredericM88/linuxcnc-sim
I would be particularly interested in feedback about the architecture. Does placing the simulator behind LinuxCNC at the hardware interface make sense to you? Are there LinuxCNC behaviours or use cases that would be especially useful to test with this approach?
Frederic
I've been working on a standalone CNC machine simulator for LinuxCNC and have now published the first experimental version.
The main idea is that the simulator does NOT interpret G-code itself.
LinuxCNC remains responsible for G-code interpretation, trajectory planning, coordinate systems, offsets and compensation. The simulator sits behind LinuxCNC where real motion hardware would normally be connected.
Currently I use the original Stepper-Ninja HAL driver and its UDP protocol as the interface:
G-code
|
v
LinuxCNC
|
v
Trajectory planner / compensation
|
v
Original Stepper-Ninja HAL driver
|
| UDP
v
linuxcnc-sim
|
+-- virtual machine motion
+-- virtual digital inputs
+-- limit switches
+-- probe input
+-- OpenGL visualization
+-- voxel workpiece
+-- material removal
The important part of this approach is that the simulator sees the motion that LinuxCNC actually sends to the virtual hardware instead of trying to reproduce LinuxCNC's trajectory planner.
Communication is bidirectional. The simulator can also send virtual machine inputs back to LinuxCNC. I can already use this for limit switches, homing and a simple configurable probe plane.
The current version also contains a sparse voxel workpiece and persistent material removal. Tool movement is processed as continuous swept volumes rather than just removing material at individual sampled positions.
One interesting problem was performance during curved motion. LinuxCNC can generate many small motion segments. Instead of approximating those segments with a larger chord, I batch the actual swept segments for a short time window and calculate the union of their removal volumes. This keeps the resulting voxel state identical while greatly reducing repeated work.
At the moment the simulation is still quite limited:
- flat-end cutter only
- no geometric stock probing yet
- no toolsetter yet
- no spindle/holder model
- no general collision detection
- no rotary material transform
The next area I would like to work on is geometric contact detection. My idea is to use the same contact system later for workpiece probing, a machine-fixed toolsetter and eventually collision detection.
Stepper-Ninja is currently just the interface between LinuxCNC and the simulator. A physical machine does not need to use Stepper-Ninja hardware. I chose it because an existing LinuxCNC HAL driver and a small bidirectional protocol already existed, so I did not have to invent another LinuxCNC hardware interface.
This is my first public release and I consider it experimental development software, not a machine safety system.
Source and v0.1.0:
github.com/FredericM88/linuxcnc-sim
I would be particularly interested in feedback about the architecture. Does placing the simulator behind LinuxCNC at the hardware interface make sense to you? Are there LinuxCNC behaviours or use cases that would be especially useful to test with this approach?
Frederic
Attachments:
Last edit: 03 Oct 2026 13:27 by fmueller.
Please Log in or Create an account to join the conversation.
- tuxcnc
- Away
- Elite Member
-

Less
More
- Posts: 267
- Thank you received: 50
03 Oct 2026 14:32 #350080
by tuxcnc
Replied by tuxcnc on topic Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface
Can't compile ninja hal driver for LinuxCNC 2.10, so your hard work is useless for me.
Building LinuxCNC HAL module stepgen-ninja
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:34:13: note: ‘#pragma message: Ethernet version’
   34 |     #pragma message "Ethernet version"
      |             ^~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:99:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
   99 |     hal_float_t *command[stepgens];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:100:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  100 |     hal_float_t *feedback[stepgens];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:101:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  101 |     hal_float_t *scale[stepgens];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:102:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  102 |     hal_bit_t *mode[stepgens];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:103:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  103 |     hal_bit_t *enable[stepgens];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:104:5: error: unknown type name ‘hal_u32_t’; did you mean ‘hal_uint_t’?
  104 |     hal_u32_t *pulse_width;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:107:5: error: unknown type name ‘hal_s32_t’; did you mean ‘hal_sint_t’?
  107 |     hal_s32_t *raw_count[encoders];
      |     ^~~~~~~~~
      |     hal_sint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:108:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  108 |     hal_float_t *enc_scale[encoders];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:109:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  109 |     hal_float_t *enc_position[encoders];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:110:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  110 |     hal_float_t *enc_velocity[encoders];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:111:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  111 |     hal_bit_t *enc_index[encoders];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:112:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  112 |     hal_bit_t *enc_reset[encoders];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:113:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  113 |     hal_float_t *enc_rpm[encoders];
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:131:5: error: unknown type name ‘hal_s32_t’; did you mean ‘hal_sint_t’?
  131 |     hal_s32_t *jitter;
      |     ^~~~~~~~~
      |     hal_sint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:132:5: error: unknown type name ‘hal_u32_t’; did you mean ‘hal_uint_t’?
  132 |     hal_u32_t *step_ring_fill;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:133:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  133 |     hal_bit_t *step_ring_active;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:134:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  134 |     hal_bit_t *step_ring_underflow;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:135:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  135 |     hal_bit_t *step_ring_overflow;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:136:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  136 |     hal_bit_t *input[96];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:137:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  137 |     hal_bit_t *input_not[96];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:138:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  138 |     hal_bit_t *rpi_input[32];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:139:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  139 |     hal_bit_t *rpi_input_not[32];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:141:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  141 |     hal_bit_t *output[64];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:142:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  142 |     hal_bit_t *rpi_output[32];
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:157:5: error: unknown type name ‘hal_float_t’; did you mean ‘hal_port_t’?
  157 |     hal_float_t *debug_freq;
      |     ^~~~~~~~~~~
      |     hal_port_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:158:5: error: unknown type name ‘hal_s32_t’; did you mean ‘hal_sint_t’?
  158 |     hal_s32_t *debug_steps[stepgens];
      |     ^~~~~~~~~
      |     hal_sint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:159:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  159 |     hal_bit_t *debug_steps_reset;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:161:5: error: unknown type name ‘hal_u32_t’; did you mean ‘hal_uint_t’?
  161 |     hal_u32_t *period;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:162:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  162 |     hal_bit_t *connected;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:163:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  163 |     hal_bit_t *io_ready_in;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:164:5: error: unknown type name ‘hal_bit_t’; did you mean ‘hal_uint_t’?
  164 |     hal_bit_t *io_ready_out;
      |     ^~~~~~~~~
      |     hal_uint_t
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c: In function ‘watchdog_process’:
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:367:39: warning: unused parameter ‘period’ [-Wunused-parameter]
  367 | void watchdog_process(void *arg, long period)
      |                                  ~~~~~^~~~~~
In file included from /usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:441:
/usr/src/stepper-ninja-hal/hal-driver/modules/breakoutboard_hal_0.c: In function ‘bb_hal_setup_pins’:
/usr/src/stepper-ninja-hal/hal-driver/modules/breakoutboard_hal_0.c:23:13: error: implicit declaration of function ‘hal_pin_bit_newf’ [-Wimplicit-function-declaration]
   23 |         r = hal_pin_bit_newf(HAL_OUT, &d->input[i], comp_id, name, j);
      |             ^~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c: In function ‘_receive’:
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:445:27: warning: unused parameter ‘arg’ [-Wunused-parameter]
  445 | static int _receive(void *arg)
      |                     ~~~~~~^~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c: In function ‘udp_io_process_recv’:
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:480:42: warning: unused parameter ‘period’ [-Wunused-parameter]
  480 | void udp_io_process_recv(void *arg, long period)
      |                                     ~~~~~^~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c: In function ‘udp_io_process_send’:
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:630:29: warning: comparison of integer expressions of different signedness: ‘uint32_t’ {aka ‘unsigned int’} and ‘int’ [-Wsign-compare]
  630 |         if (old_pulse_width != *d->pulse_width) {
      |                             ^~
In file included from /usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:49:
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c: In function ‘rtapi_app_main’:
/usr/src/stepper-ninja-hal/hal-driver/hal_pin_macros.h:65:13: error: implicit declaration of function ‘hal_pin_u32_newf’ [-Wimplicit-function-declaration]
   65 |         r = hal_pin_u32_newf(dir, ptr, comp_id, name, j); \
      |             ^~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:882:9: note: in expansion of macro ‘PIN_U32_INIT’
  882 |         PIN_U32_INIT(&hal_data[j].pulse_width, HAL_IN, default_pulse_width, module_name ".%d.stepgen.pulse-width", j);
      |         ^~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/hal_pin_macros.h:77:13: error: implicit declaration of function ‘hal_pin_float_newf’ [-Wimplicit-function-declaration]
   77 |         r = hal_pin_float_newf(dir, ptr, comp_id, name, j); \
      |             ^~~~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:885:13: note: in expansion of macro ‘PIN_FLOAT’
  885 |             PIN_FLOAT(&hal_data[j].debug_freq, HAL_OUT, module_name ".%d.stepgen.max-freq-khz", j);
      |             ^~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/hal_pin_macros.h:31:13: error: implicit declaration of function ‘hal_pin_s32_newf’ [-Wimplicit-function-declaration]
   31 |         r = hal_pin_s32_newf(dir, ptr, comp_id, name, j); \
      |             ^~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:890:9: note: in expansion of macro ‘PIN_S32’
  890 |         PIN_S32(&hal_data[j].jitter, HAL_OUT, module_name ".%d.jitter", j);
      |         ^~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:980:17: note: ‘#pragma message: Adding export functions. (watchdog)’
  980 |         #pragma message "Adding export functions. (watchdog)"
      |                 ^~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:984:13: error: too many arguments to function ‘hal_export_funct’
  984 |         r = hal_export_funct(watchdog_name, watchdog_process, &hal_data[j], 1, 1, comp_id);
      |             ^~~~~~~~~~~~~~~~
In file included from /usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:4:
/usr/include/linuxcnc/hal.h:807:5: note: declared here
  807 | int hal_export_funct(const char *name, void (*funct) (void *, long),
      |     ^~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:992:17: note: ‘#pragma message: Adding export functions. (process-send)’
  992 |         #pragma message "Adding export functions. (process-send)"
      |                 ^~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:996:13: error: too many arguments to function ‘hal_export_funct’
  996 |         r = hal_export_funct(process_send, udp_io_process_send, &hal_data[j], 1, 1, comp_id);
      |             ^~~~~~~~~~~~~~~~
/usr/include/linuxcnc/hal.h:807:5: note: declared here
  807 | int hal_export_funct(const char *name, void (*funct) (void *, long),
      |     ^~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:1004:17: note: ‘#pragma message: Adding export functions. (process-recv)’
 1004 |         #pragma message "Adding export functions. (process-recv)"
      |                 ^~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:1008:13: error: too many arguments to function ‘hal_export_funct’
 1008 |         r = hal_export_funct(process_recv, udp_io_process_recv, &hal_data[j], 1, 1, comp_id);
      |             ^~~~~~~~~~~~~~~~
/usr/include/linuxcnc/hal.h:807:5: note: declared here
  807 | int hal_export_funct(const char *name, void (*funct) (void *, long),
      |     ^~~~~~~~~~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c: At top level:
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:445:12: warning: ‘_receive’ defined but not used [-Wunused-function]
  445 | static int _receive(void *arg)
      |            ^~~~~~~~
/usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:203:17: warning: ‘counter’ defined but not used [-Wunused-variable]
  203 | static uint32_t counter = 0;
      |                 ^~~~~~~
In file included from /usr/src/stepper-ninja-hal/hal-driver/config.h:83,
                 from /usr/src/stepper-ninja-hal/hal-driver/transmission.h:5,
                 from /usr/src/stepper-ninja-hal/hal-driver/stepgen-ninja.c:13:
/usr/src/stepper-ninja-hal/hal-driver/kbmatrix.h:12:14: warning: ‘key_names’ defined but not used [-Wunused-variable]
   12 | static char *key_names[] = {"softkey-00",  // column 0 - row 0
      |              ^~~~~~~~~
gmake[4]: *** [/usr/src/stepper-ninja-hal/hal-driver/build-cmake/stepgen-ninja/Makefile:9: stepgen-ninja.o] Błąd 1
gmake[3]: *** [CMakeFiles/stepgen-ninja.dir/build.make:109: stepgen-ninja/stepgen-ninja.so] Błąd 2
gmake[2]: *** [CMakeFiles/Makefile2:91: CMakeFiles/stepgen-ninja.dir/all] Błąd 2
gmake[1]: *** [CMakeFiles/Makefile2:98: CMakeFiles/stepgen-ninja.dir/rule] Błąd 2
gmake: *** [Makefile:170: stepgen-ninja] Błąd 2
Please Log in or Create an account to join the conversation.
- fmueller
- Away
- New Member
-
Less
More
- Posts: 2
- Thank you received: 2
03 Oct 2026 17:20 - 03 Oct 2026 17:32 #350081
by fmueller
Replied by fmueller on topic Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface
Thanks for testing it and for posting the compiler output.
Your report exposed an incompatibility between the original Stepper-Ninja HAL driver and the new HAL API used by LinuxCNC 2.10. I have now added a compatibility layer that supports both the LinuxCNC 2.9 HAL API and the new 2.10 HAL API.
I released the fix as v0.1.1:
github.com/FredericM88/linuxcnc-sim/releases/tag/v0.1.1
I did not want to publish the fix based on compilation alone, so I also built LinuxCNC 2.10.0~pre2 as a Run-In-Place installation and tested the driver with HAL API 1.
The 2.10 tests included:
- loading and unloading the Stepper-Ninja HAL module
- the expected HAL pins and data types
- bidirectional UDP communication with the simulator
- homing using the simulated inputs
- XYZ motion
- G38.2 probing using the virtual probe input
- persistent material removal, including curved motion
I also added support for building the HAL module directly against a configured LinuxCNC Run-In-Place tree. The build system still supports installed LinuxCNC development files and keeps the source-only compile-check mode.
For an installed LinuxCNC development environment, the compatibility driver can be built with:
The simulator itself and the Stepper-Ninja UDP protocol were not changed for this fix.
If you have a chance to try v0.1.1 on your LinuxCNC 2.10 installation, I would be very interested in whether it now builds and loads correctly there as well. That would also give me an independent 2.10 test outside my development system.
Thanks again for trying the project so quickly and for providing the error log.
Your report exposed an incompatibility between the original Stepper-Ninja HAL driver and the new HAL API used by LinuxCNC 2.10. I have now added a compatibility layer that supports both the LinuxCNC 2.9 HAL API and the new 2.10 HAL API.
I released the fix as v0.1.1:
github.com/FredericM88/linuxcnc-sim/releases/tag/v0.1.1
I did not want to publish the fix based on compilation alone, so I also built LinuxCNC 2.10.0~pre2 as a Run-In-Place installation and tested the driver with HAL API 1.
The 2.10 tests included:
- loading and unloading the Stepper-Ninja HAL module
- the expected HAL pins and data types
- bidirectional UDP communication with the simulator
- homing using the simulated inputs
- XYZ motion
- G38.2 probing using the virtual probe input
- persistent material removal, including curved motion
I also added support for building the HAL module directly against a configured LinuxCNC Run-In-Place tree. The build system still supports installed LinuxCNC development files and keeps the source-only compile-check mode.
For an installed LinuxCNC development environment, the compatibility driver can be built with:
git clone https://github.com/FredericM88/linuxcnc-sim.git
cd linuxcnc-sim
git checkout v0.1.1

git clone https://github.com/atrex66/stepper-ninja.git ../stepper-ninja-hal
git -C ../stepper-ninja-hal checkout --detach eb7e5dfa2e76477e606a47038b07cca5e8a4b424

cmake -S compat/stepper-ninja -B build/compat-hal \
-DSTEPPER_NINJA_SOURCE="$PWD/../stepper-ninja-hal"

cmake --build build/compat-hal -j"$(nproc)"
ctest --test-dir build/compat-hal --output-on-failure

# Result:
build/compat-hal/stepgen-ninja.so
The simulator itself and the Stepper-Ninja UDP protocol were not changed for this fix.
If you have a chance to try v0.1.1 on your LinuxCNC 2.10 installation, I would be very interested in whether it now builds and loads correctly there as well. That would also give me an independent 2.10 test outside my development system.
Thanks again for trying the project so quickly and for providing the error log.
Last edit: 03 Oct 2026 17:32 by fmueller.
The following user(s) said Thank You: tuxcnc, tommylight
Please Log in or Create an account to join the conversation.
- tuxcnc
- Away
- Elite Member
-
Less
More
- Posts: 267
- Thank you received: 50
03 Oct 2026 19:54 #350084
by tuxcnc
Replied by tuxcnc on topic Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface
Seems works.
Please Log in or Create an account to join the conversation.
- LinuxCNC
- General LinuxCNC Questions
- Standalone LinuxCNC machine simulator using the Stepper-Ninja HAL interface
Time to create page: 0.334 seconds