Leadshine CS3E-D1008 not running smoothly [SOLVED]

More
3 years 10 months ago #258729 by petervg
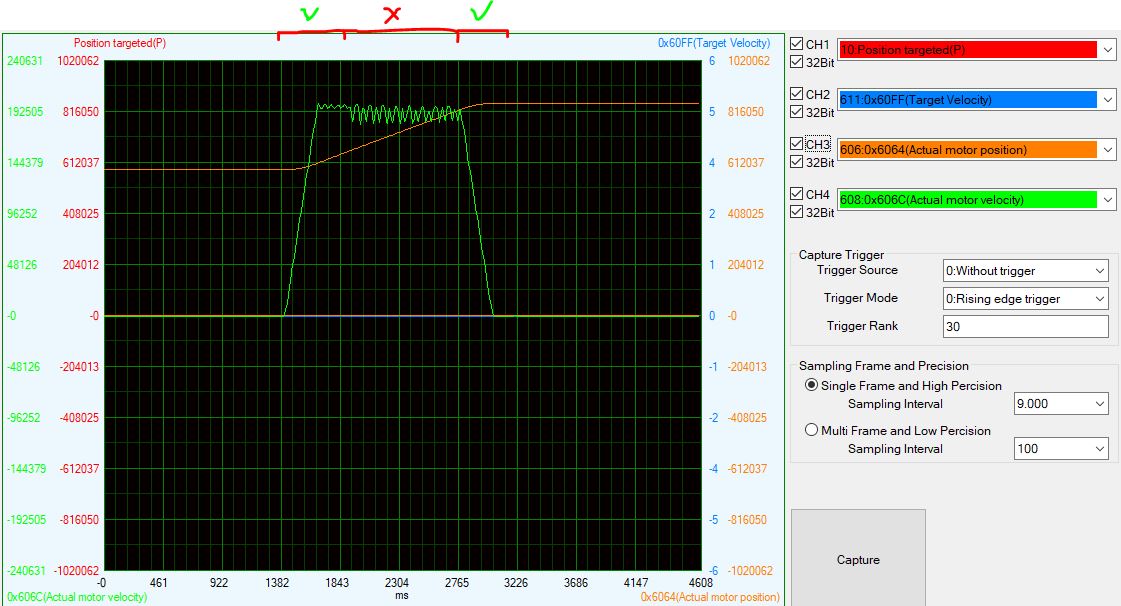
I'm using a fresh install of debian 11, RT kernel running (5.10.0-19-rt-amd64) compiled all from source and ethercat seems to work as it should (with an officially supported network card). I only have 1 drive and motor to test, so I took the sim_axis example and modified the X axis configuration to test the motor. When I try to jog the motor, the ramp up and first milliseconds of the coasting work great, but then the motor starts making funny noises and the rpm drops.


This is a graph from the motion control studio software where I can graph the internals of the drive, and you can clearly see the speed starts to fluctuate as in the video.
 

I've taken a look at the ethercat communications, but I have no TX errors and only 2 lost frames.

Could this be a ethercat configuration issue? If I run the motor using motion control studio (usb), the motor runs perfectly.

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #258732 by mwc
Looks like it's needing a bit D added to the PID to dampen the oscillations, but I probably wouldn't add too much until the motor is installed with some load on it.

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago - 3 years 10 months ago #258743 by petervg
My distributor said the same thing. but that wasn't it. We've tried disabling the PID in the drive by running the steppers in open loop and the same problem persists. And when running in closed loop, I can make the motors run from withing the leadshine software (usb) perfectly well, and that way they run great.

So far I think there is an issue with the ethercat interface, but this might very well be a bug in the leadshine drive...

 
Last edit: 3 years 10 months ago by petervg. Reason: typo

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #258744 by mwc
There are PID settings in LinuxCNC.
It's probably an issue with the ethercat loop fighting with the driver loop, so some tuning will likely be needed.
The following user(s) said Thank You: petervg

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #258751 by petervg
That's indeed something I didn't take a look at yet. My gut says it won't be related to PID because the problem is too consistent and repeatable but I hope I'm wrong :-). I'm going to need to catch up to some documentation reading and tinker a bit with these settings.

Thanks for the tip!!

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #258763 by db1981
Is this position or velocity control by linuxcnc?

Is the command value from linuxcnc fluctuation too or stays it at constant level while the actual motor velocity is fluctuating ?

Please Log in or Create an account to join the conversation.

Time to create page: 0.396 seconds
Powered by Kunena Forum