- Posts: 22
- Thank you received: 30

 (
AliExpress Link
)
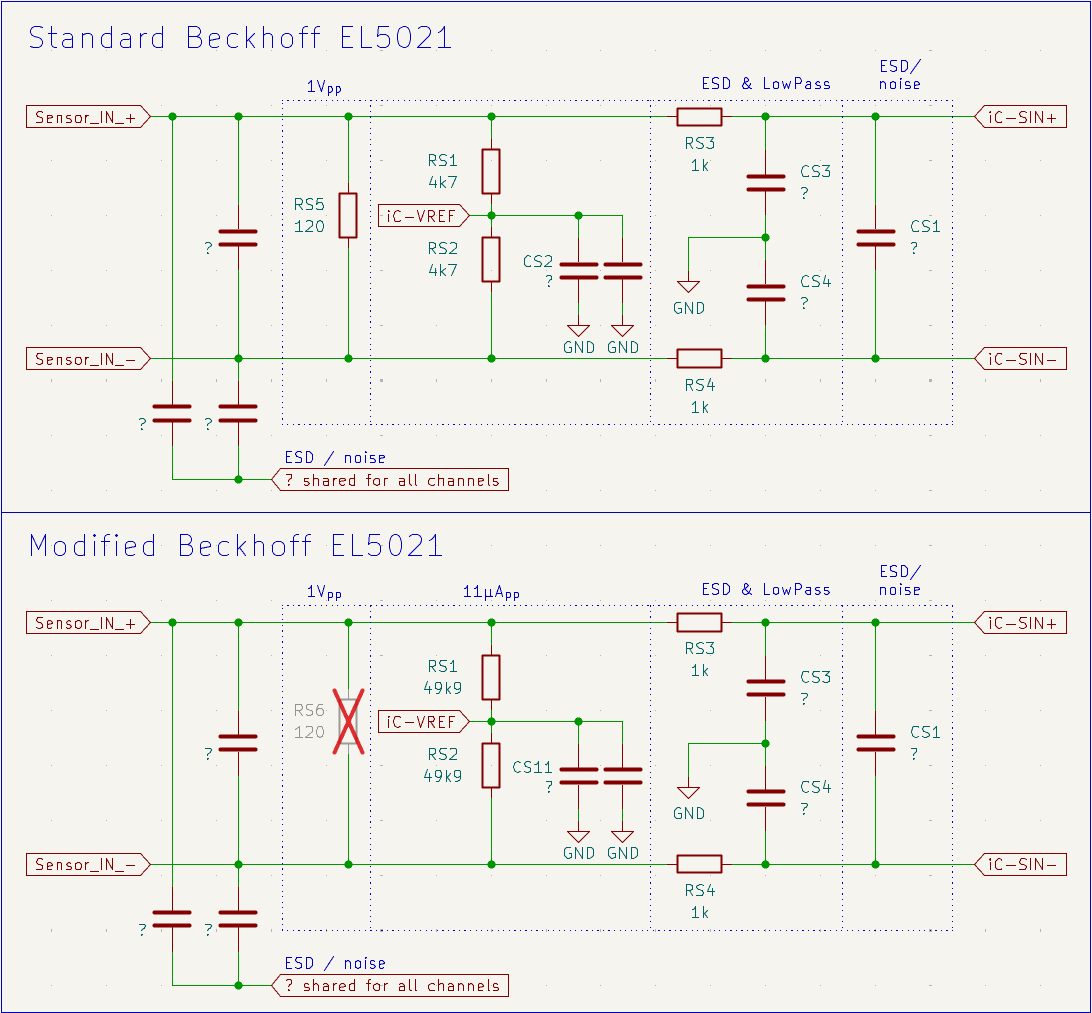
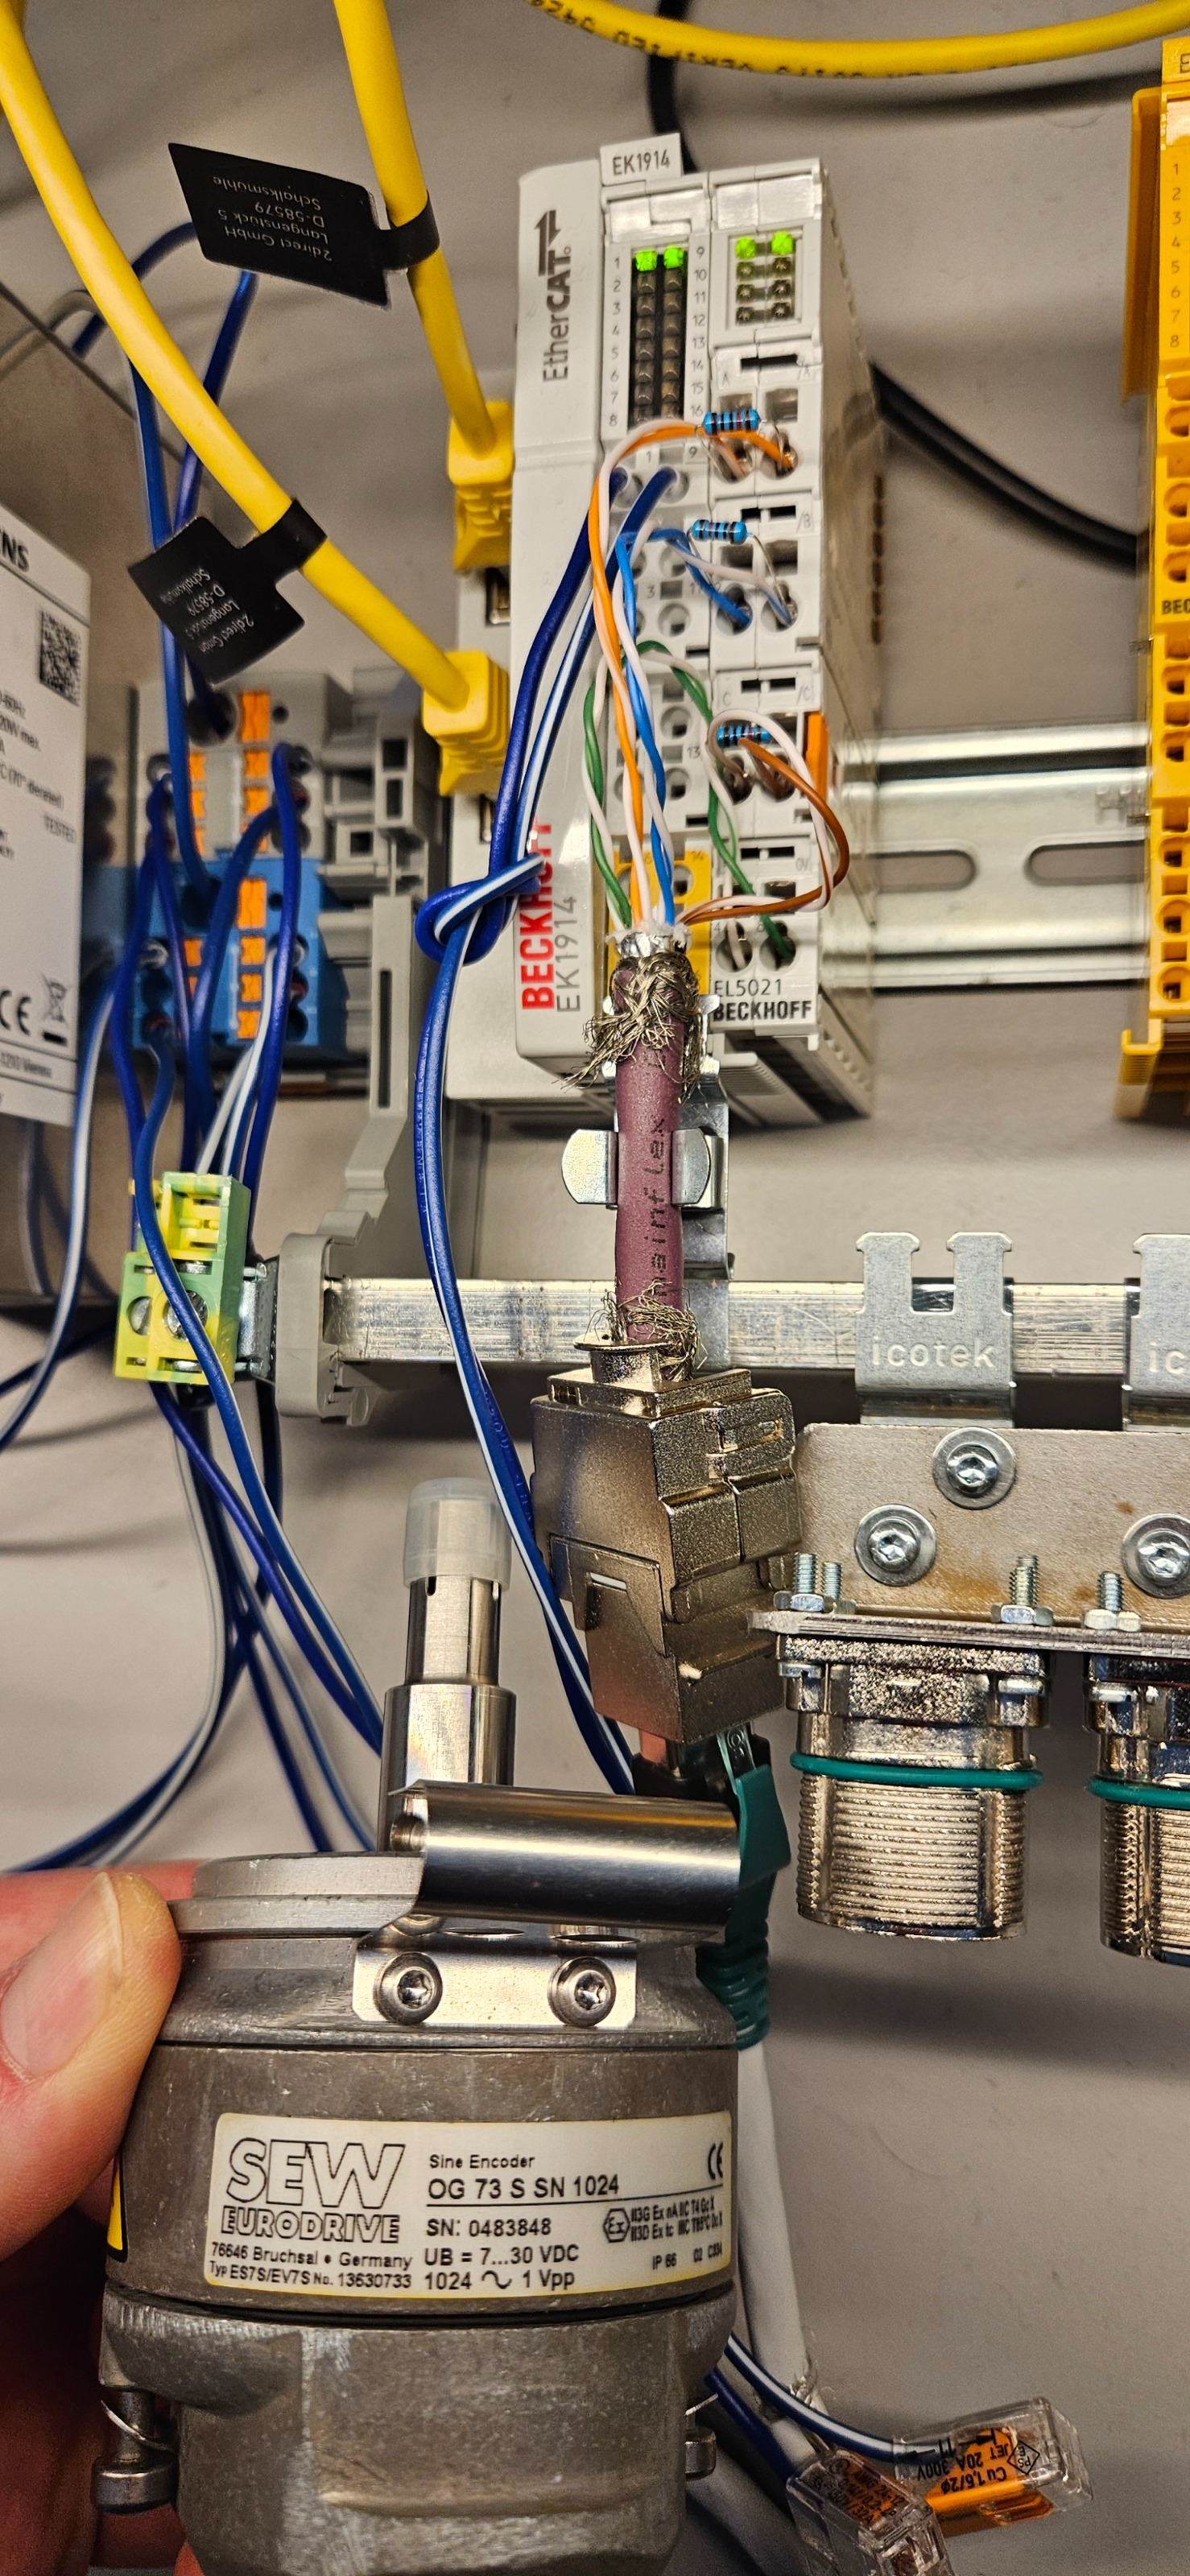
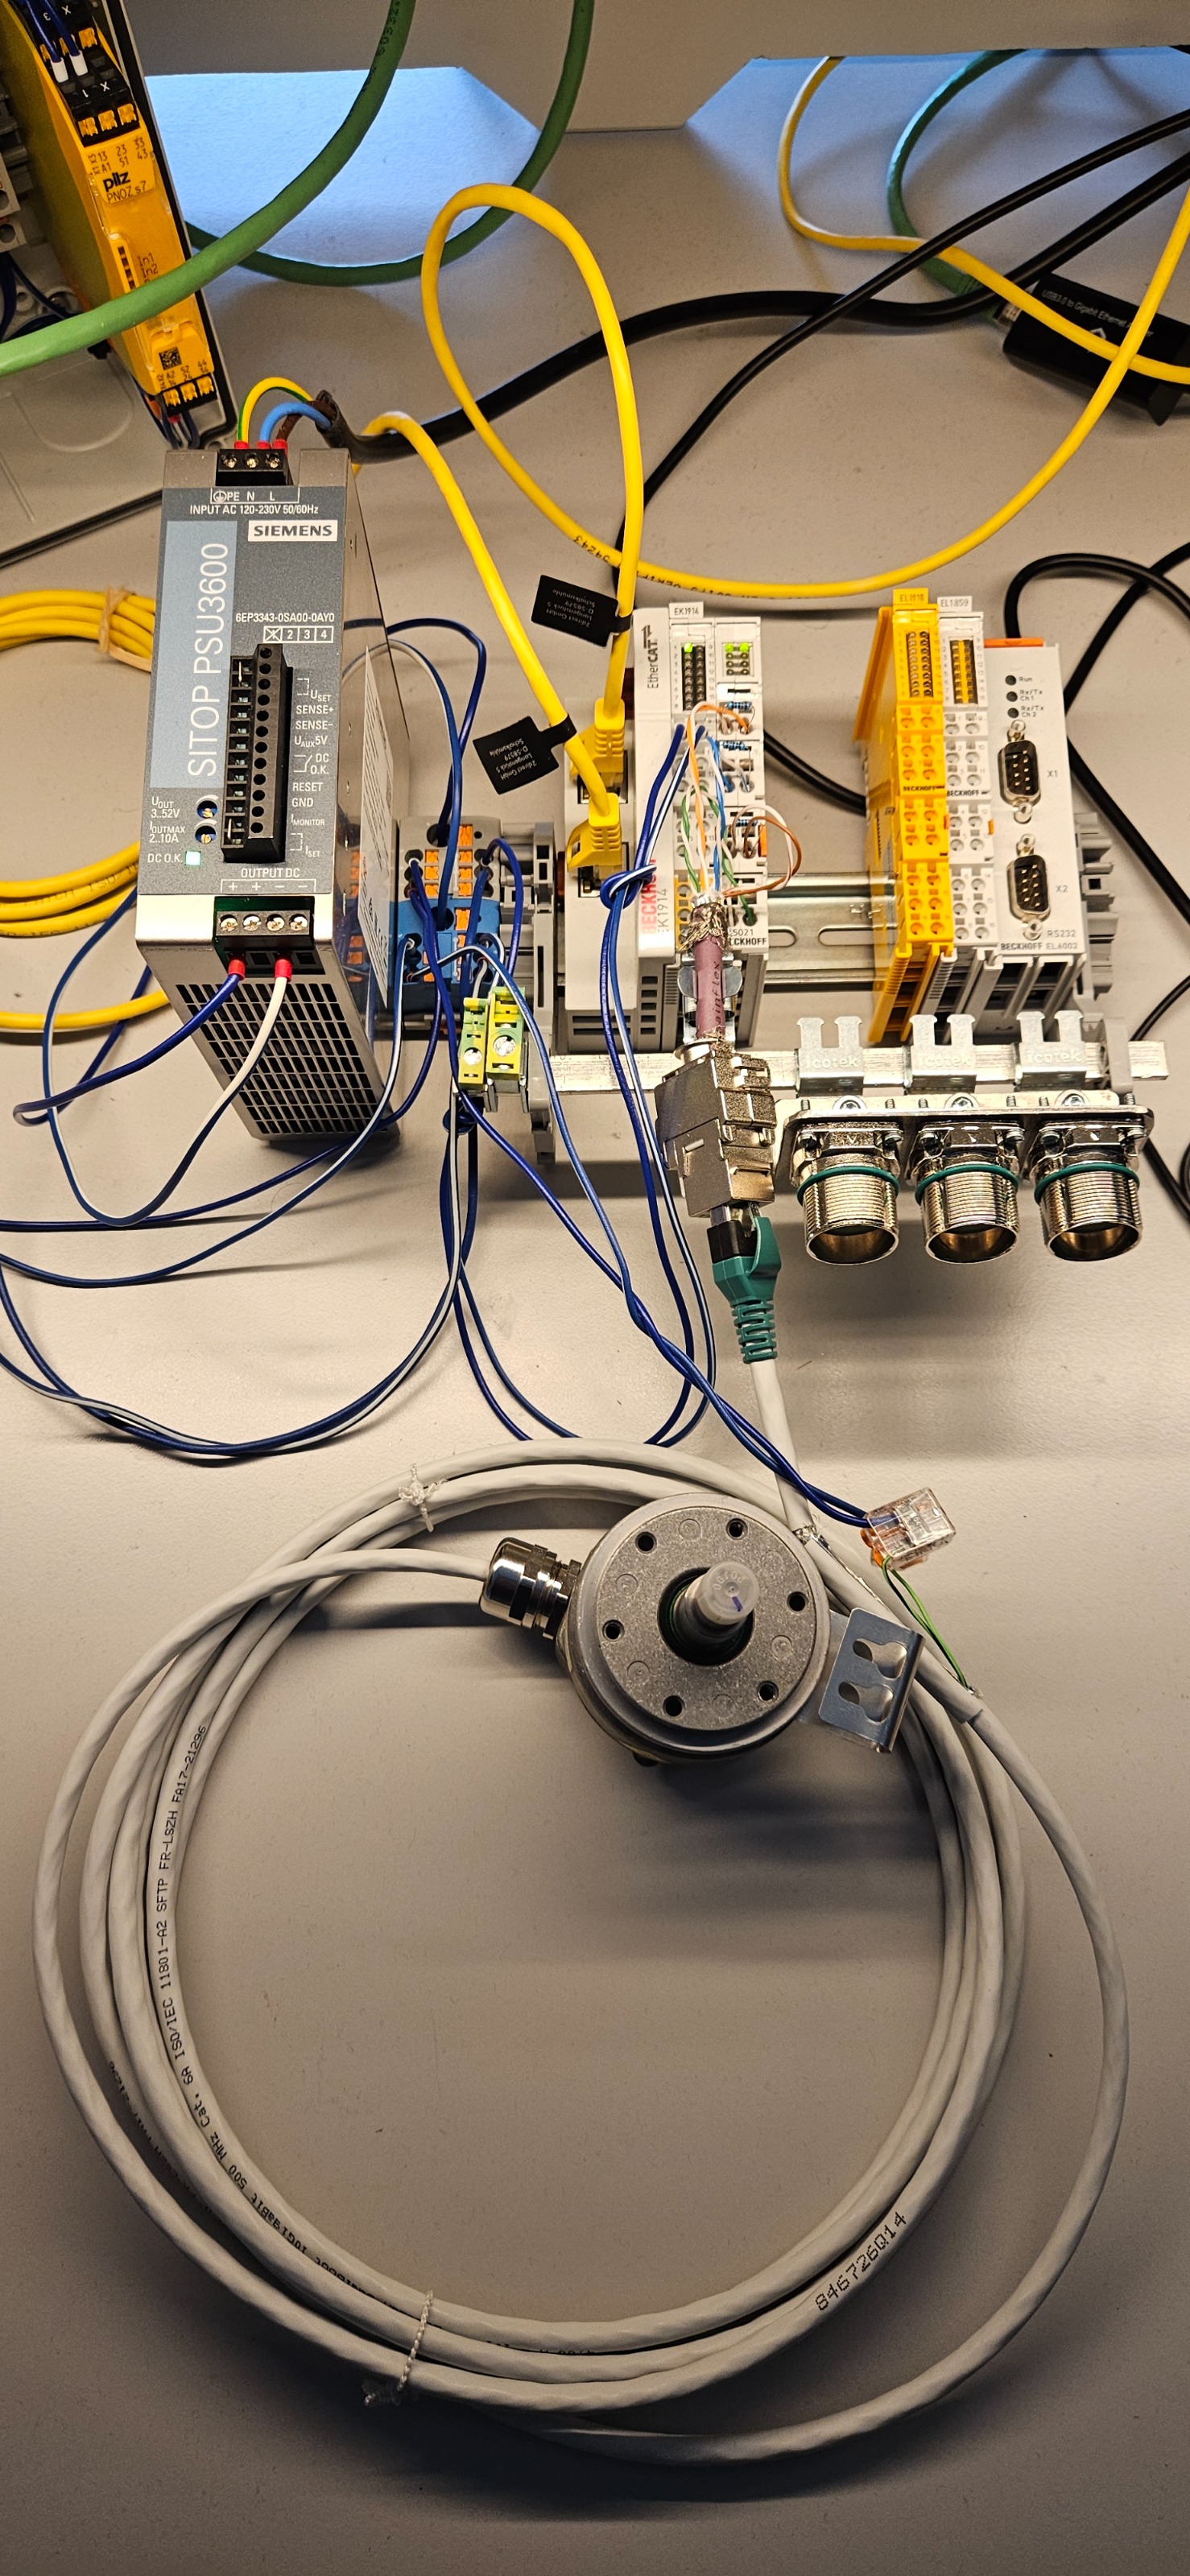
 So, yes, an EL5021 Beckhoff terminal can actually read 11µA_pp signals and you only have to modify 9 resistors in total. A rudimentary schematic is attached
 I'm not able to measure the capacitance of the capacitors due to the installed resistors within the circuit, but their values shouldn't really matter (maybe an RC low-pass filter is no longer tuned as it should be, but that shouldn't cause problems here - I hope). I documented the very first test of the modified terminal and uploaded the video to YouTube.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
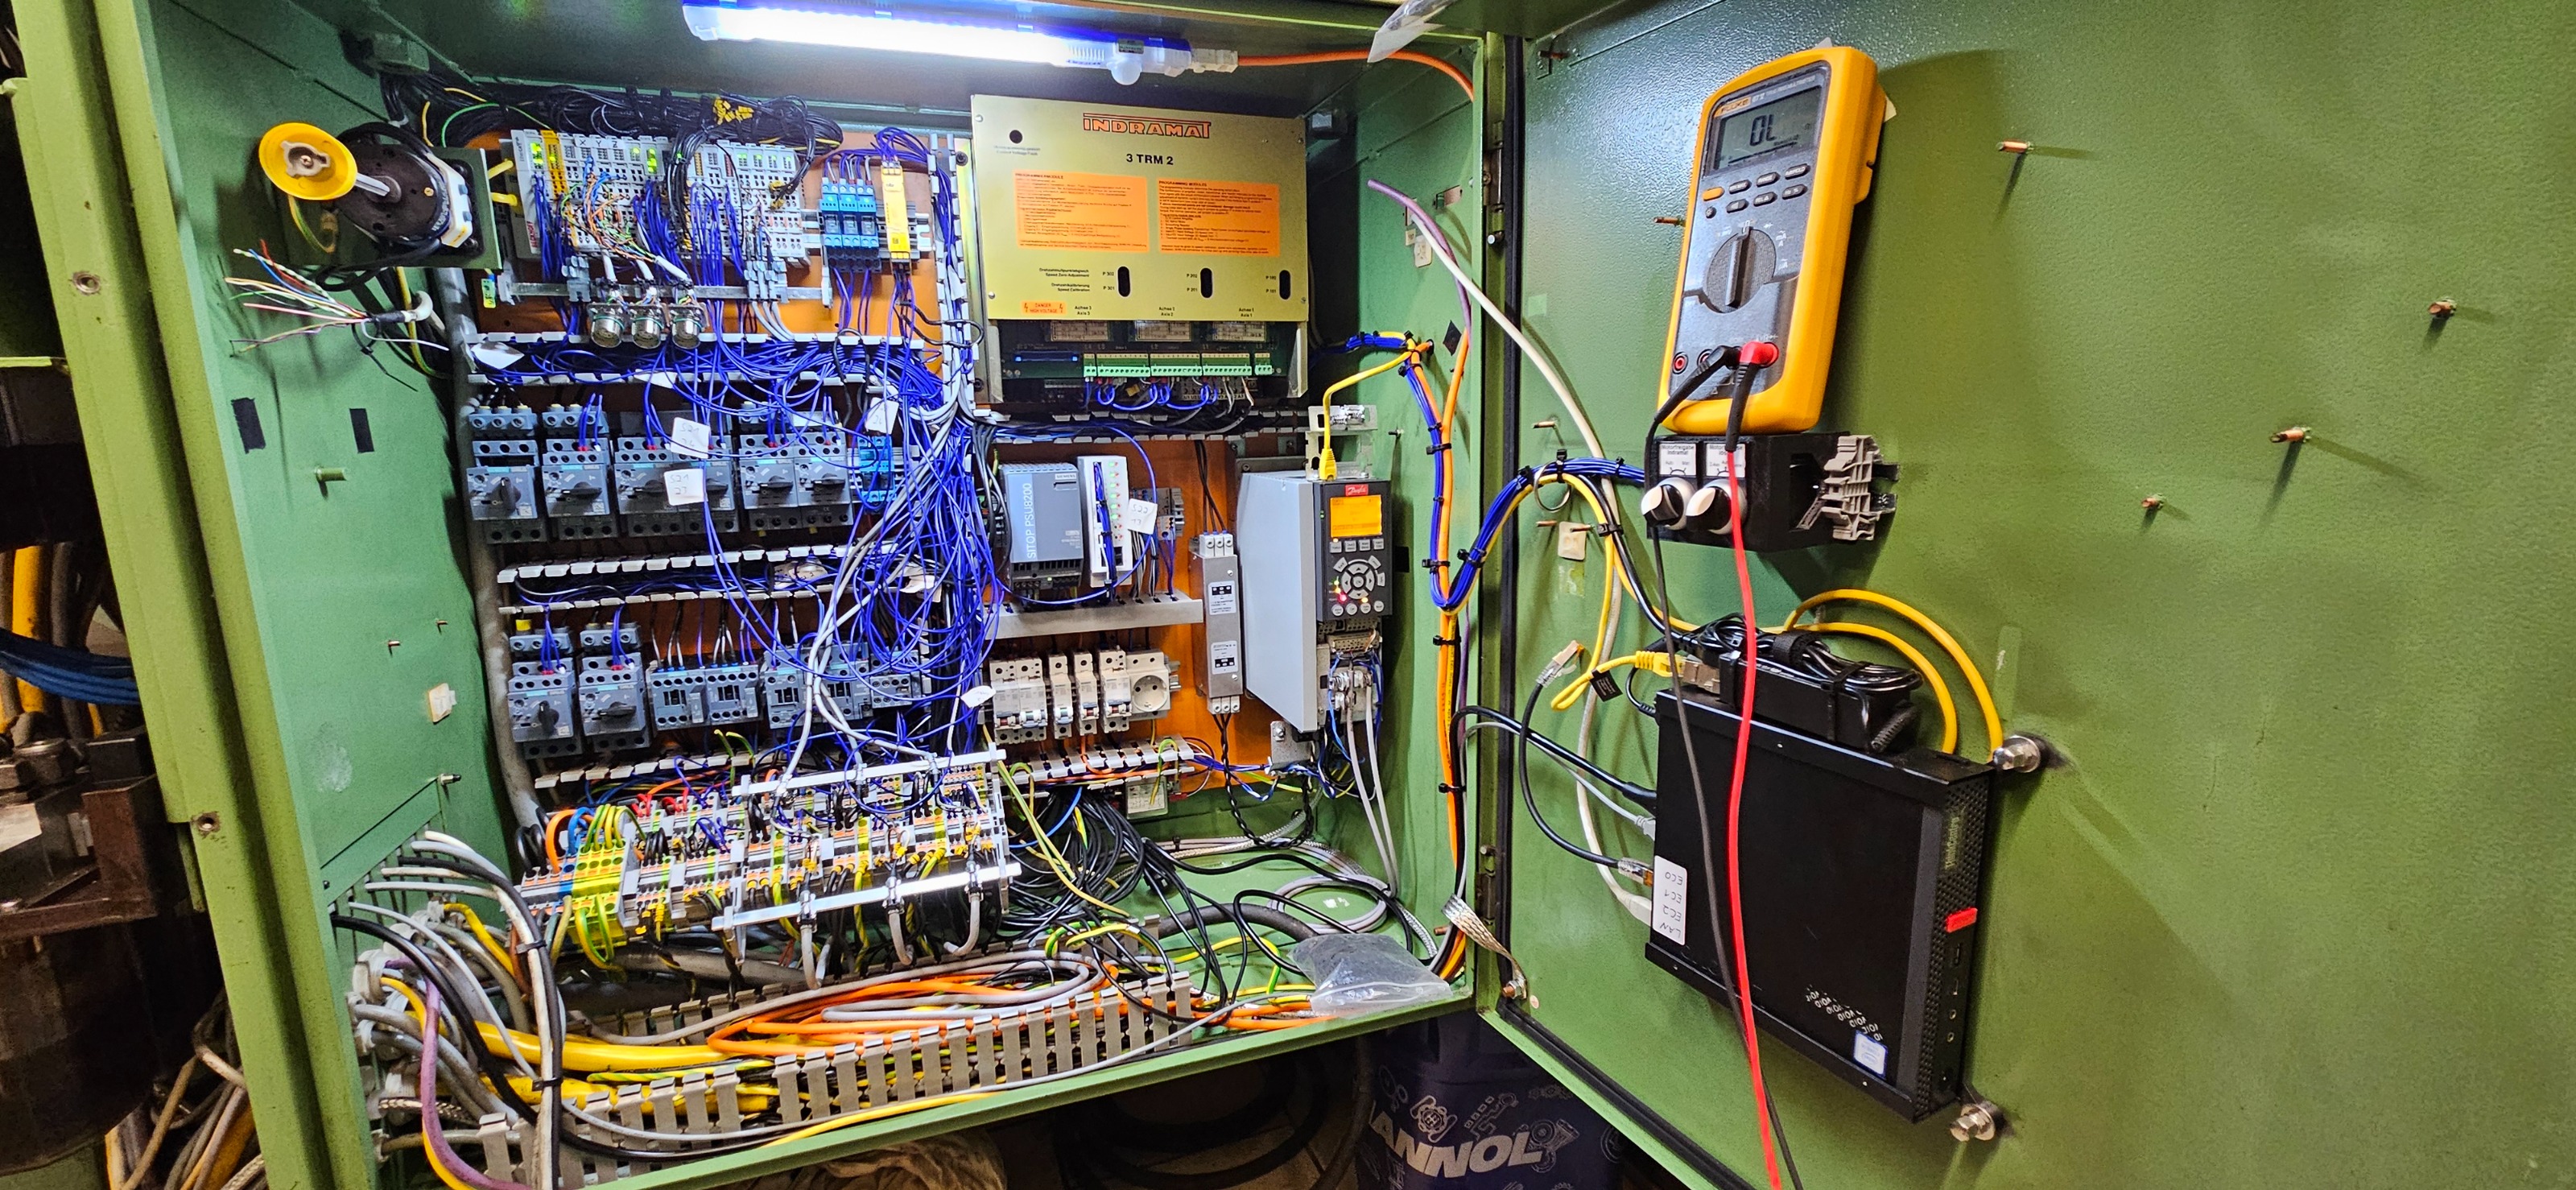
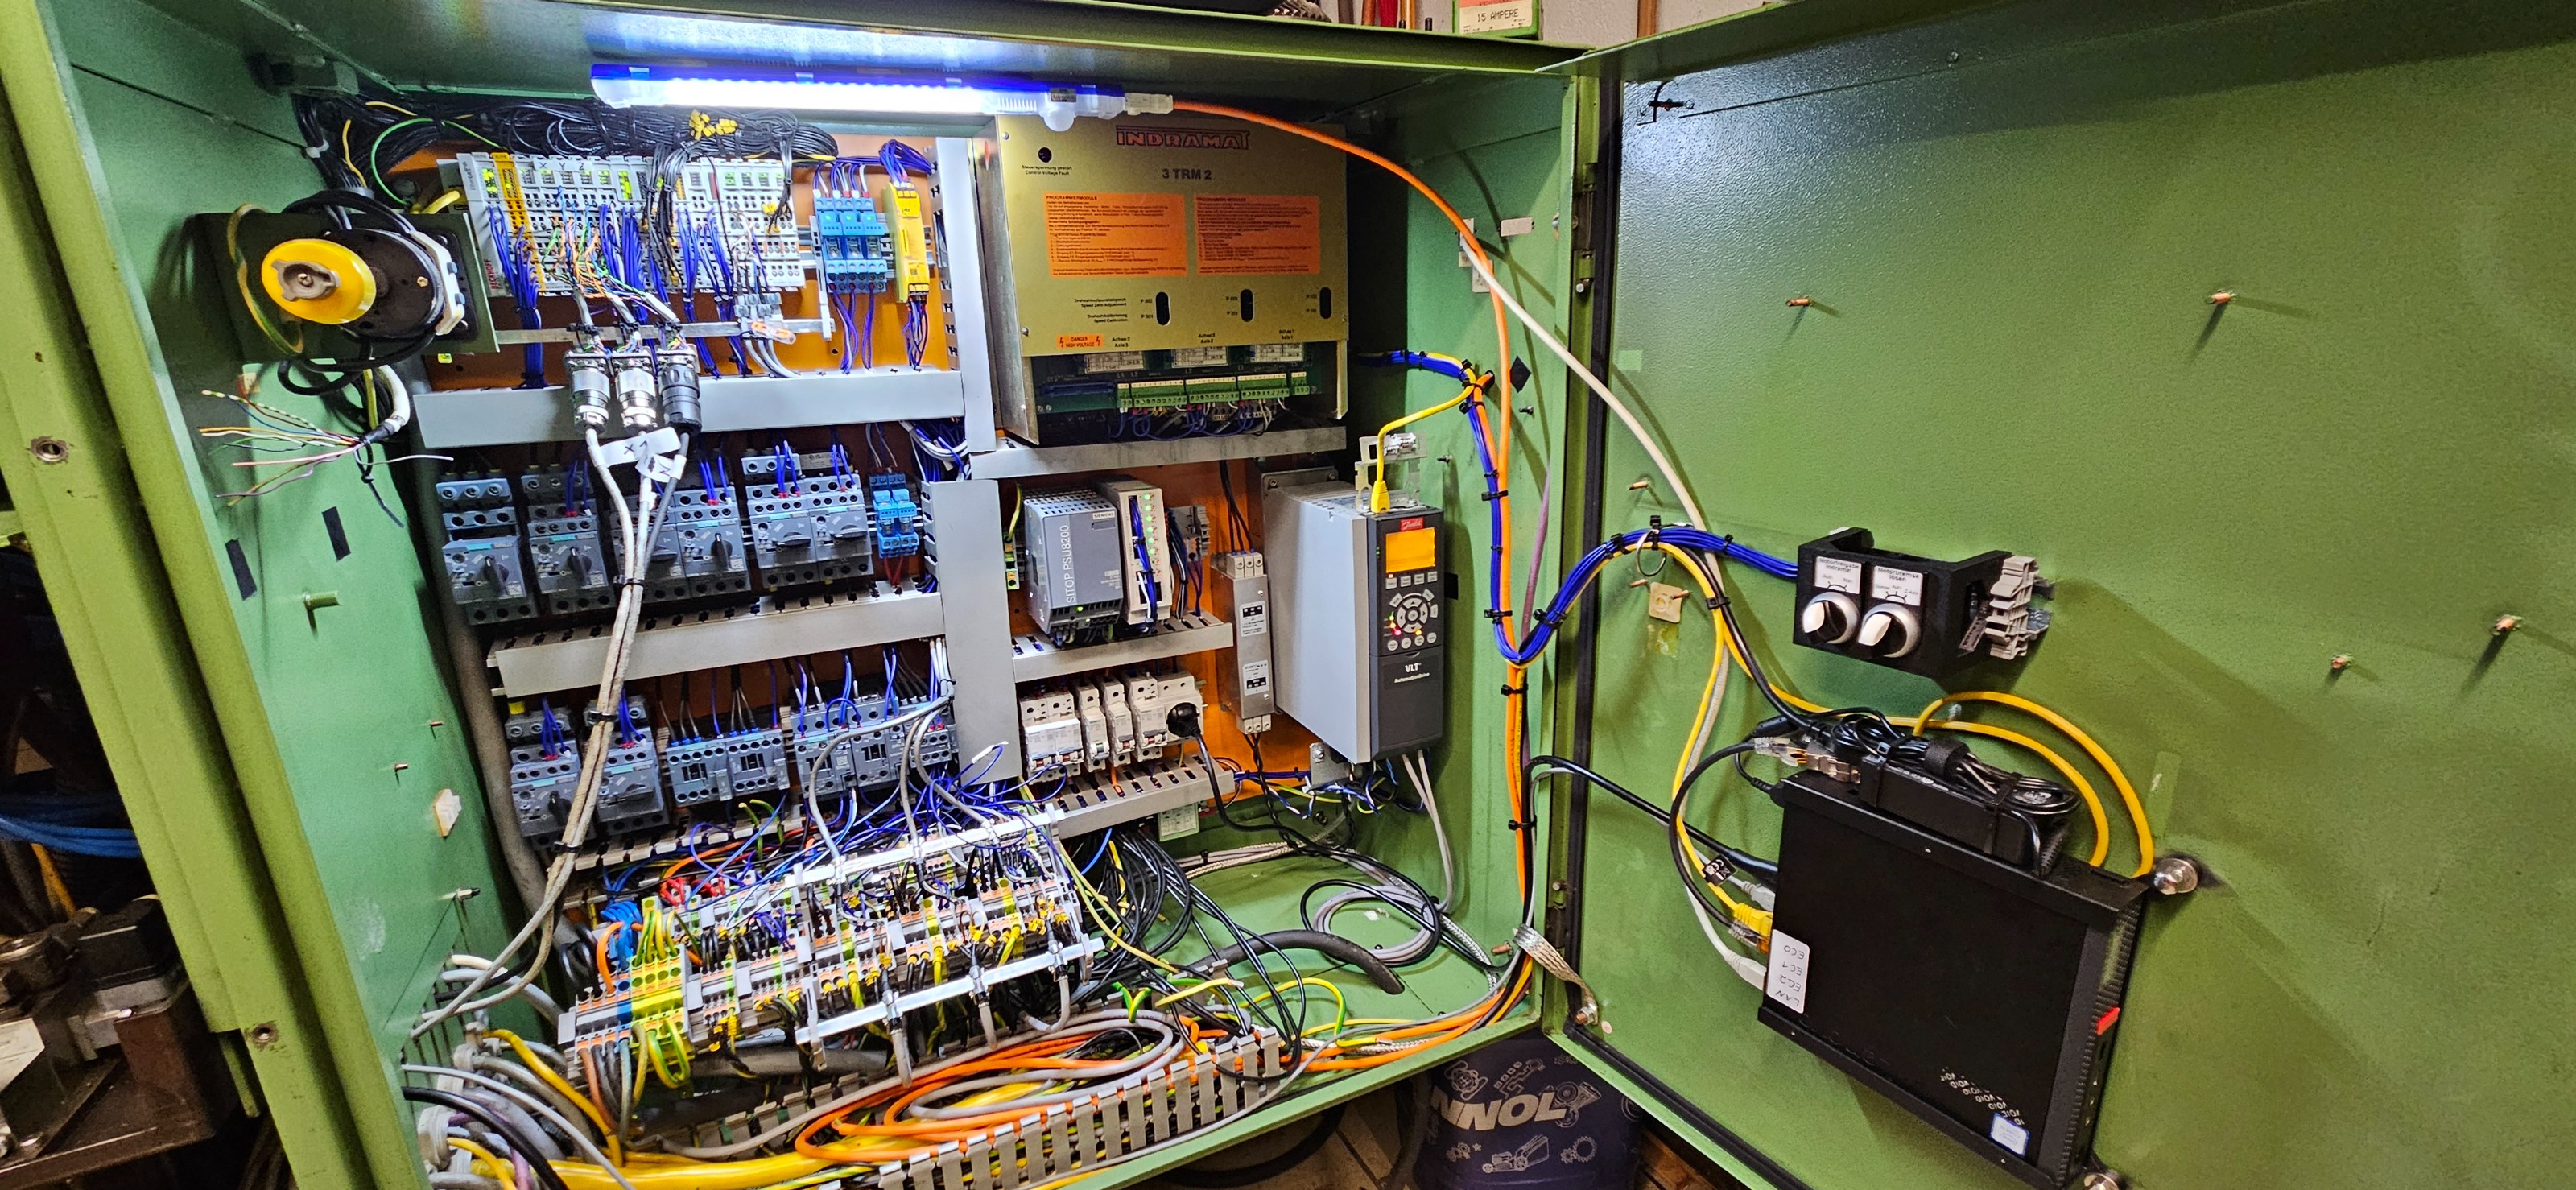
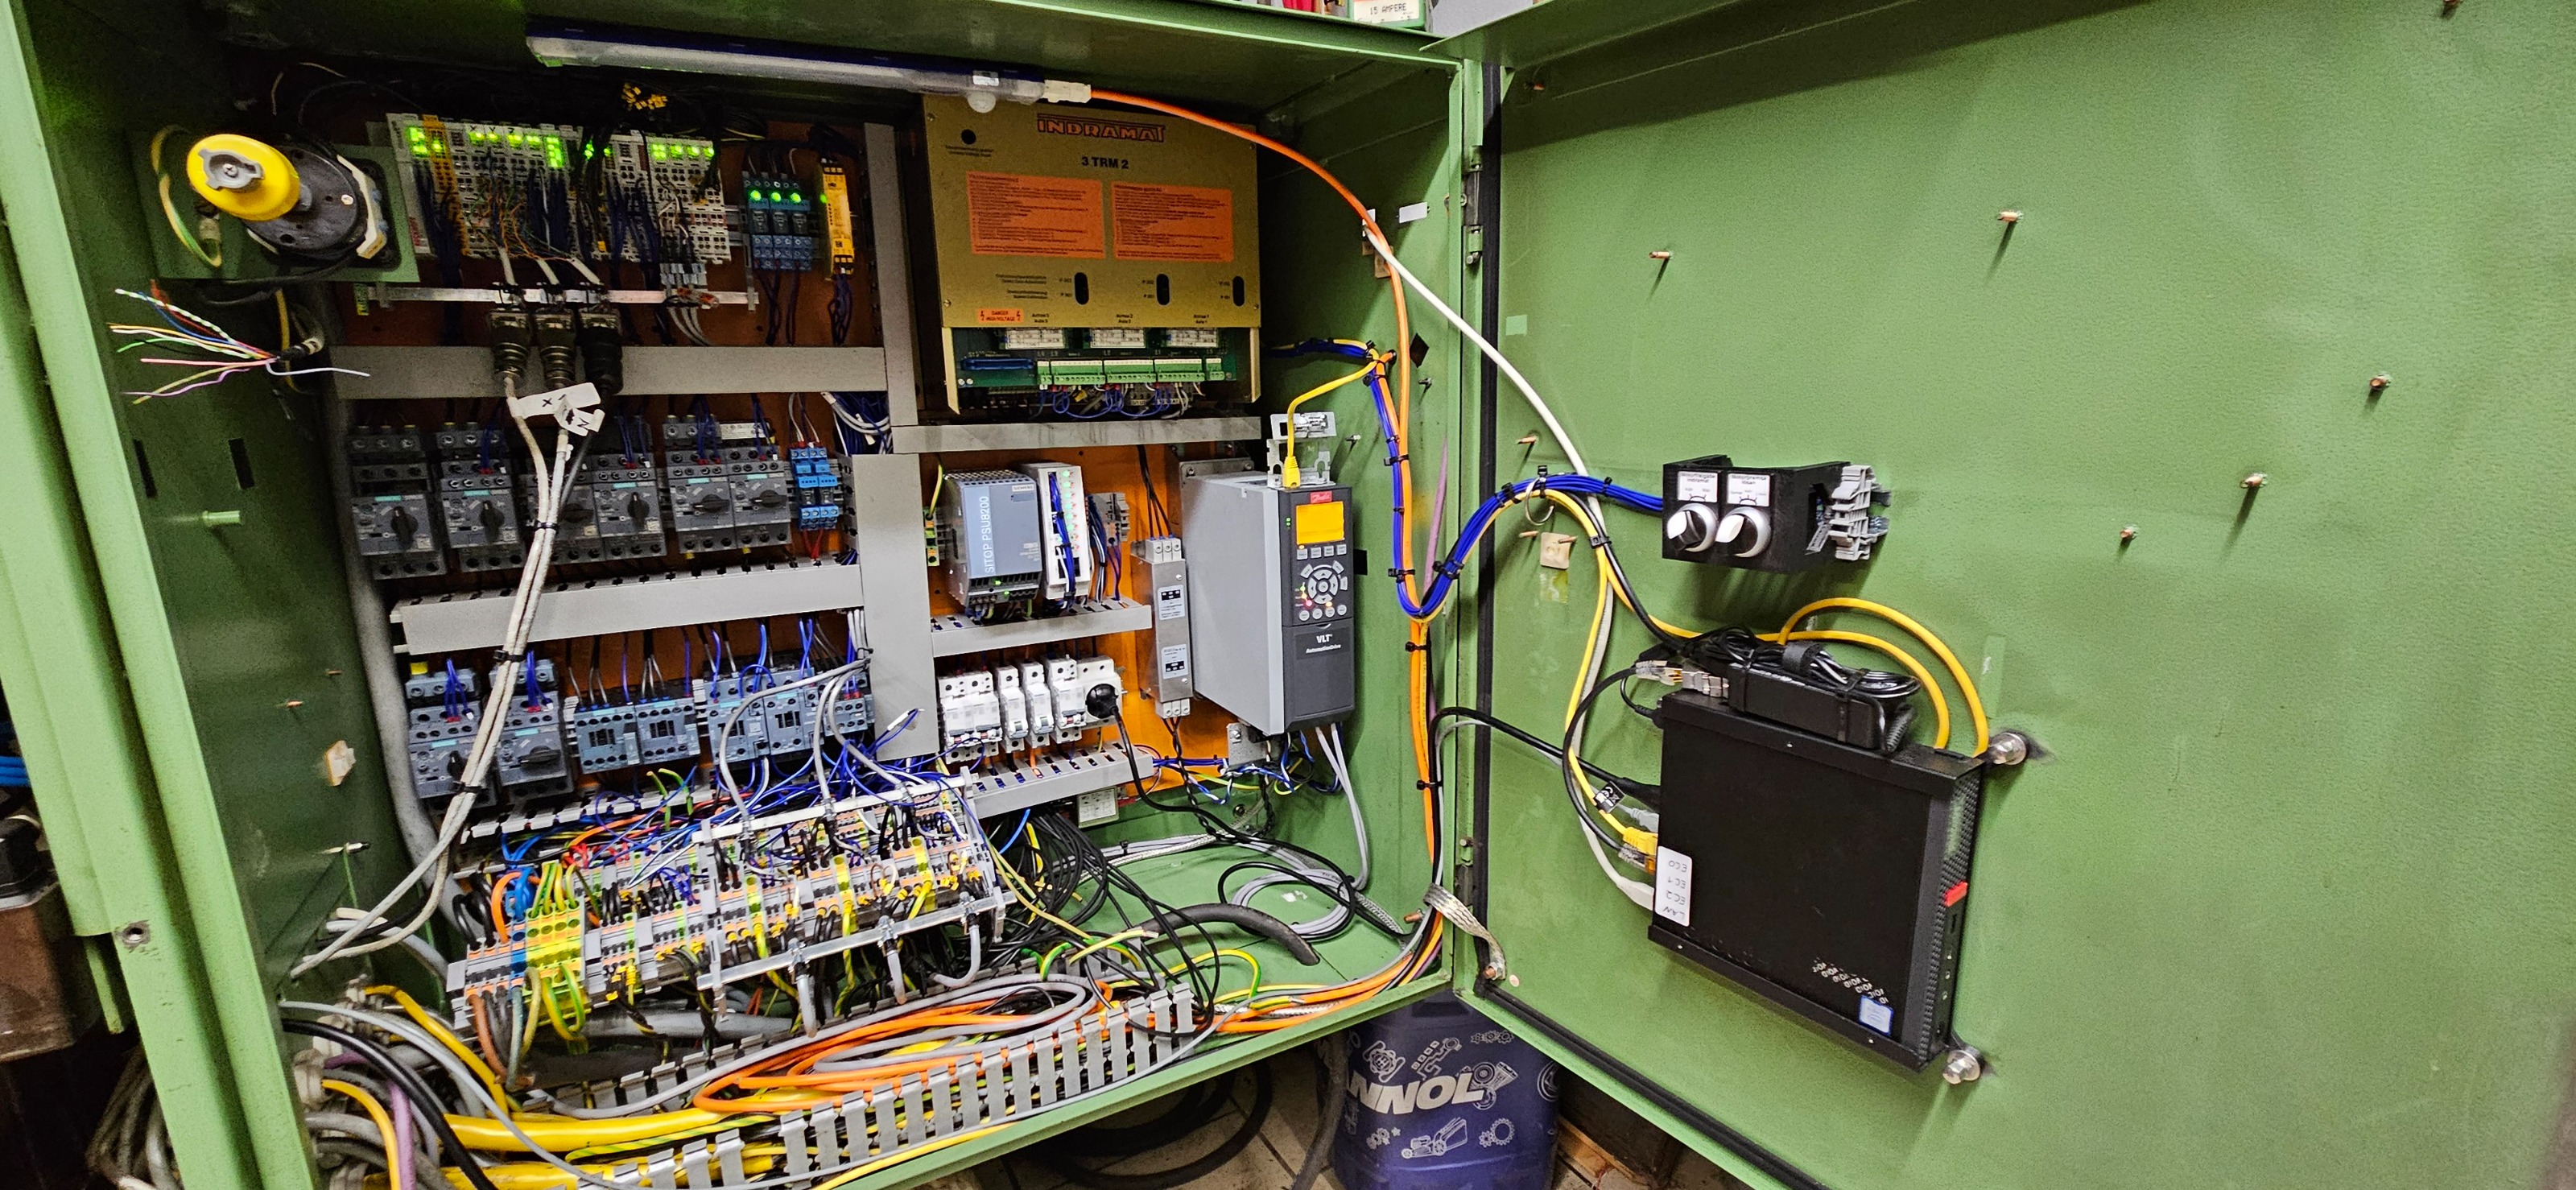
. In the remaining time in between, all electronics of the control cabinet were removed (only the Indramat and the corresponding transformers have stayed) and the ancient components were replaced. Due to the new variable frequency drive, most of the original electronics weren't needed anymore. Therefore, a whole rebuild of the cabinet was the most logical thing to do. For now, the cabinet is mostly finished and just in need of a cleanup.We are also using the aforementioned modified EL5021 terminals for the X, Y, and Z glass scales. Due to their minimum interpolation setting of 10 bit (=1024), we are theoretically able to read each 20 µm glass scale down to a resolution of around 20 nm. We do not believe that we are actually that accurate by any means, but we are indeed able to register every single move of each axis. Even if it is just caused by a finger pressing slightly on an axis. In the hot summer months, we also saw the mill getting bigger/smaller due to thermal expansion. Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.