ROS LinuxCNC Link

More
5 years 6 months ago #206790 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

Here is my report :

I compiled Ros from source for debian 11. Everything went ok.
Attached my howto install documentation.

After compiling (time consuming) it would not start Ros. Somehow it will not run.
The bash script's where set executable etc. Nothing happens.

In the meantime i studied several Ros examples, including the c++ code examples.

Ok. I have a conclusion. For me it's a non-productive software solution.

The experience i have beside Ros has much more power and speed to become very productive and professional.
So for me i leave Ros as it is, with respect for the developper team and Ros users. It has a reprository with many star's.
The following user(s) said Thank You: DPFlex

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago - 5 years 5 months ago #207922 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

A tiny update.

I did some work in the meantime.

1. Created a embedded linux install version for robots.
2. Created a advanched s-curve motion planner. We need this for nice moves.
3. Created a realtime path planner wich behaves like a video player with 1000 frames a second. :laugh: This is really a big thing.
4. Created a c++ halviewer. We have now full control. :blink:
5. Now creating the different robot, cnc machine teach in functions for 3d usage.

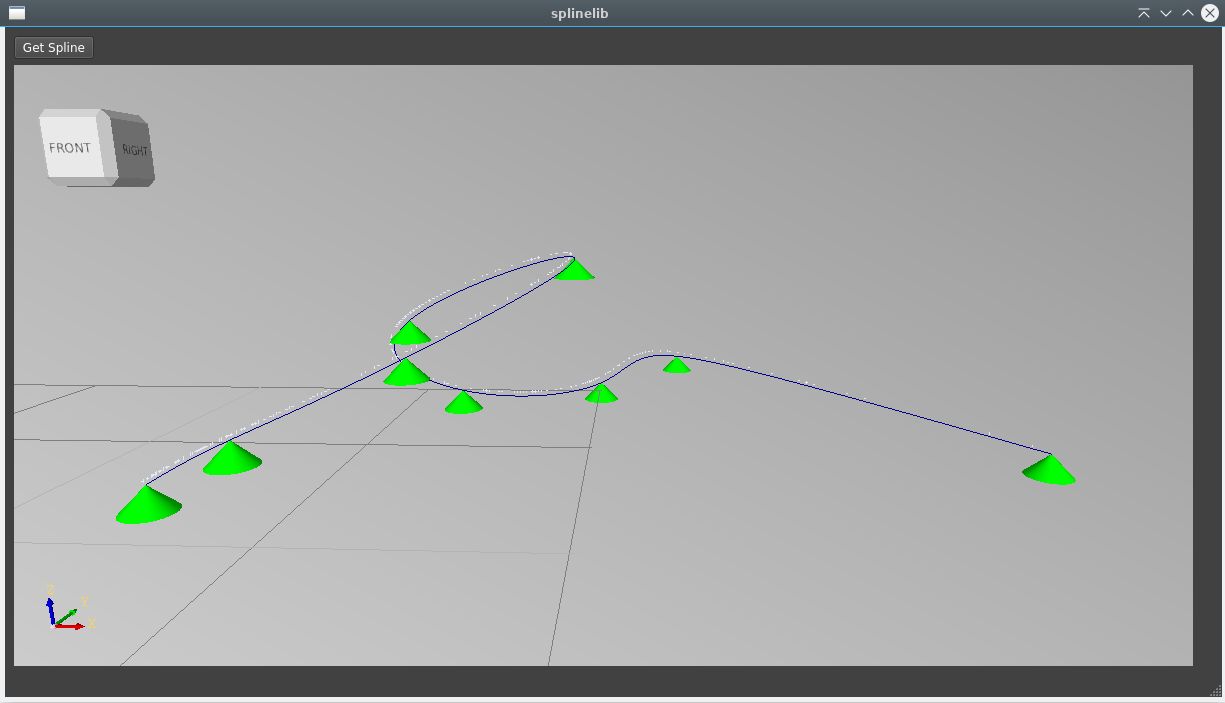
This is how the robot path will be when doing a rapid move, green = "teach in points". The path is of type spline.


One thing i really would like to have is a 3d arc motion path. I was working on this for many hours, but no succes so far. :silly:
My math level for this 3d arc is too tiny at the moment, and i found no usefull examples.
The arc teach in, contains from 3 points.

At the moment when using a G2 or G3 you can do this only in one plane at a time.
A G2-3d or a G3-3d does not have to be related to a plane or matrix. It can be a free motion performed from any machine angle.
It could be used by 3d milling operations.

[Edit]

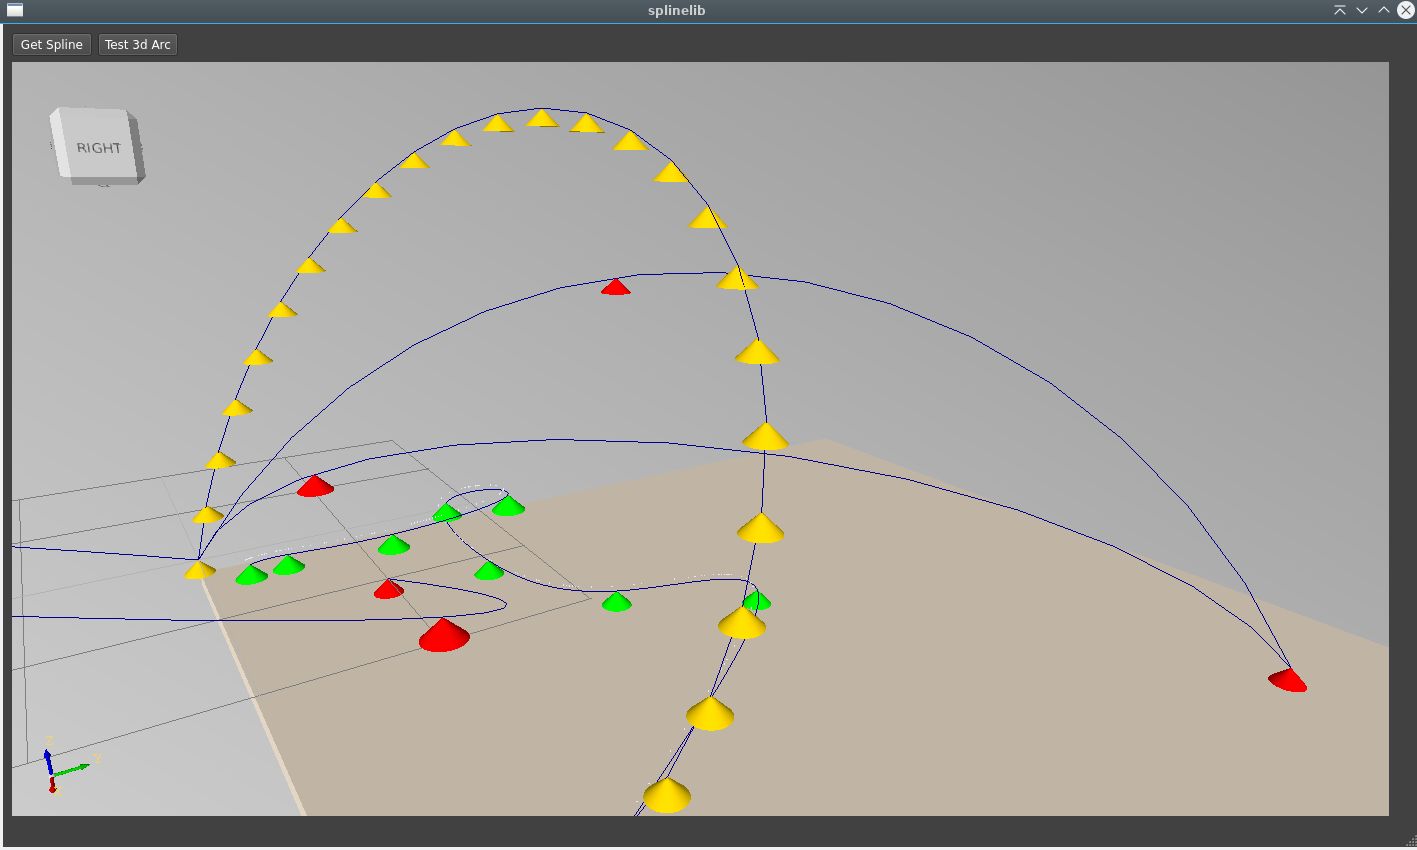
After some research i could get the 3d arc waypoints.


The arc waypoints are retrieved from a function in the opencascade library.
The complete function as in the picture for the yellow cones :
Code:
void Opencascade::test_arc(gp_Pnt point1,gp_Pnt point2,gp_Pnt point3){ //https://www.youtube.com/watch?v=gdSOTQkmHwk //point1={0,0,0}; //point2={10,10,0}; //point3={20,0,0}; Handle(Geom_TrimmedCurve) aArcOfCircle = GC_MakeArcOfCircle(point1,point2,point3); TopoDS_Edge aEdge2 = BRepBuilderAPI_MakeEdge(aArcOfCircle); GeomAdaptor_Curve acrv(aArcOfCircle); TColgp_Array1OfPnt pkte(1, 25); GCPnts_UniformAbscissa algo(acrv, 25); if(algo.IsDone() && algo.NbPoints() > 0) { int n = algo.NbPoints(); std::cout<<"total points:"<<n<<std::endl; std::cout<<"abscissa dist:"<<algo.Abscissa()<<std::endl; for(int i=1; i<algo.NbPoints(); i++){ double param = algo.Parameter(i); gp_Pnt p = aArcOfCircle->Value(param); //std::cout<<"Px:"<<p.X()<< " Py:" << p.Y() << " Pz:" << p.Z() <<std::endl; CreateArrow(p.X(),p.Y(),p.Z(),Quantity_NOC_GOLD,0,1); } } //display the edge Handle(AIS_Shape) aisBody2 = new AIS_Shape(aEdge2); m_context->SetColor(aisBody2,Quantity_NOC_BLUE4,Standard_False); m_context->SetMaterial(aisBody2,Graphic3d_NOM_PLASTIC,Standard_False); m_context->Display(aisBody2,Standard_False); }

At this stage, we know everything to get a robot teach in program running.
Last edit: 5 years 5 months ago by Grotius.
The following user(s) said Thank You: tommylight, robins

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago #207962 by andypugh
Replied by andypugh on topic ROS LinuxCNC Link

Grotius wrote: One thing i really would like to have is a 3d arc motion path. I was working on this for many hours, but no succes so far.


There is a (very stale) Arbirtrary Arcs branch:

github.com/LinuxCNC/linuxcnc/tree/arbitrary-arc

As far as I am aware, as long as the centre point is specified, only 2 arcs are possible. Without a defined plane I am not sure how you determine clockwise or anticlockwise, I suspect that if all three of IJK were specified then you would have to declare that the shortest arc will always be chosen, regardless of G2 or G3 choice. (and a centre on a straight line between start and end, ie a 180 degree arc, is simply disallowed.

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago #208021 by andypugh
Replied by andypugh on topic ROS LinuxCNC Link

Grotius wrote: I did some work in the meantime.
1. Created a embedded linux install version for robots.
2. Created a advanched s-curve motion planner. We need this for nice moves.
3. Created a realtime path planner wich behaves like a video player with 1000 frames a second. :laugh: This is really a big thing.
4. Created a c++ halviewer. We have now full control. :blink:
5. Now creating the different robot, cnc machine teach in functions for 3d usage.


Where do you buy these 50-hour days?
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago #208055 by tommylight
The following user(s) said Thank You: Grotius

Please Log in or Create an account to join the conversation.

More
5 years 5 months ago - 5 years 5 months ago #208082 by Grotius
Replied by Grotius on topic ROS LinuxCNC Link
Hi,

Cyborg here again. :woohoo:

Without a defined plane I am not sure how you determine clockwise or anticlockwise,
That is defined by point order. I now have the 3p 3d arc ready for teach in.
Waypoints out ok.
We don't have to know arc centre. We can reflect a euler angle on the 3d arc if needed in the future.

Where do you buy these 50-hour days?
I changed some priorities in life a few years ago.
Most of the time, my time is related to an old Egyptian filosofi.

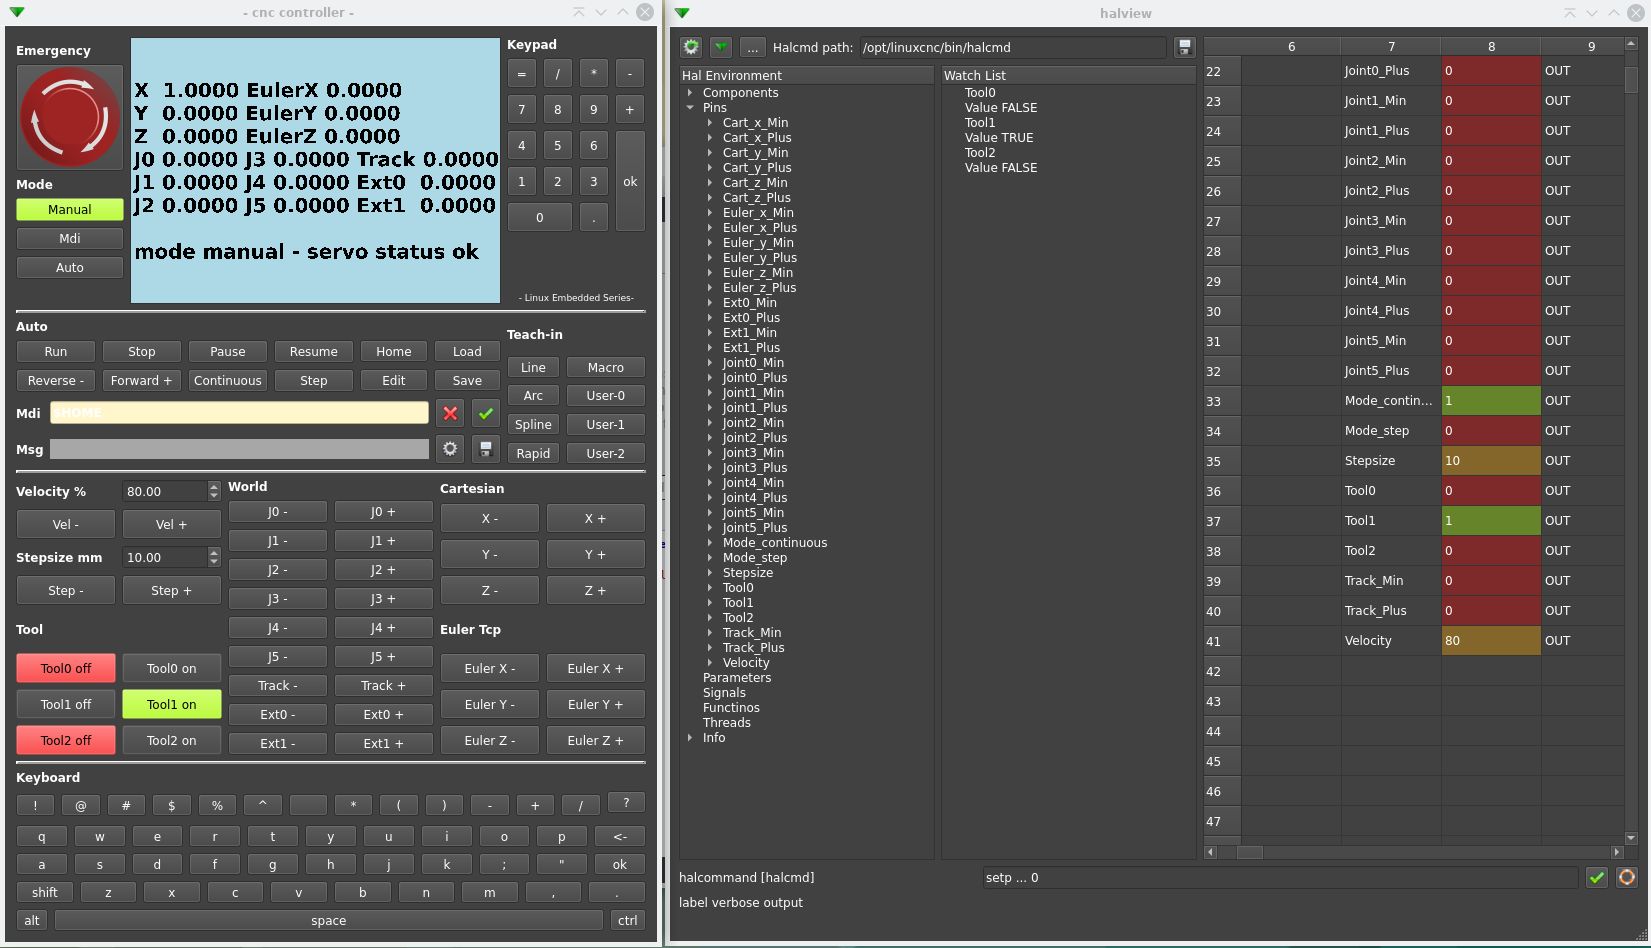
Now finishing the teach pendant.
Let me know if the button's, layout etc is ok. Then i can finish it.

The old display is done with some magic.

Last edit: 5 years 5 months ago by Grotius.
The following user(s) said Thank You: tommylight, Aciera, DPFlex

Please Log in or Create an account to join the conversation.

Time to create page: 0.177 seconds
Powered by Kunena Forum