Hi Arciera,
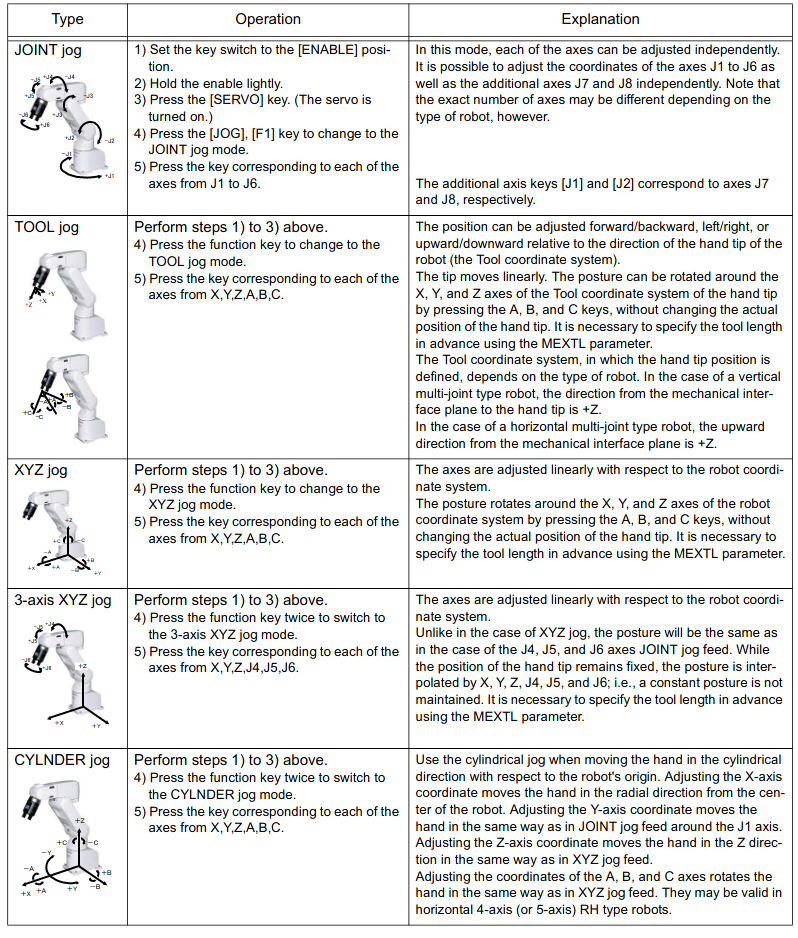
1. Could you also implement rotations (ABC) in Cartesian and TCP modes using the opencascade kinematics?
A common implementation is the roll pitch yaw, but i like the euler angles above roll pitch yaw. The euler angles rotates the tool center point inline with the world frame axis.
2. Is there a way to switch between World (joint), Cartesian and TCP modes and execute moves in the respective modes in GCode?
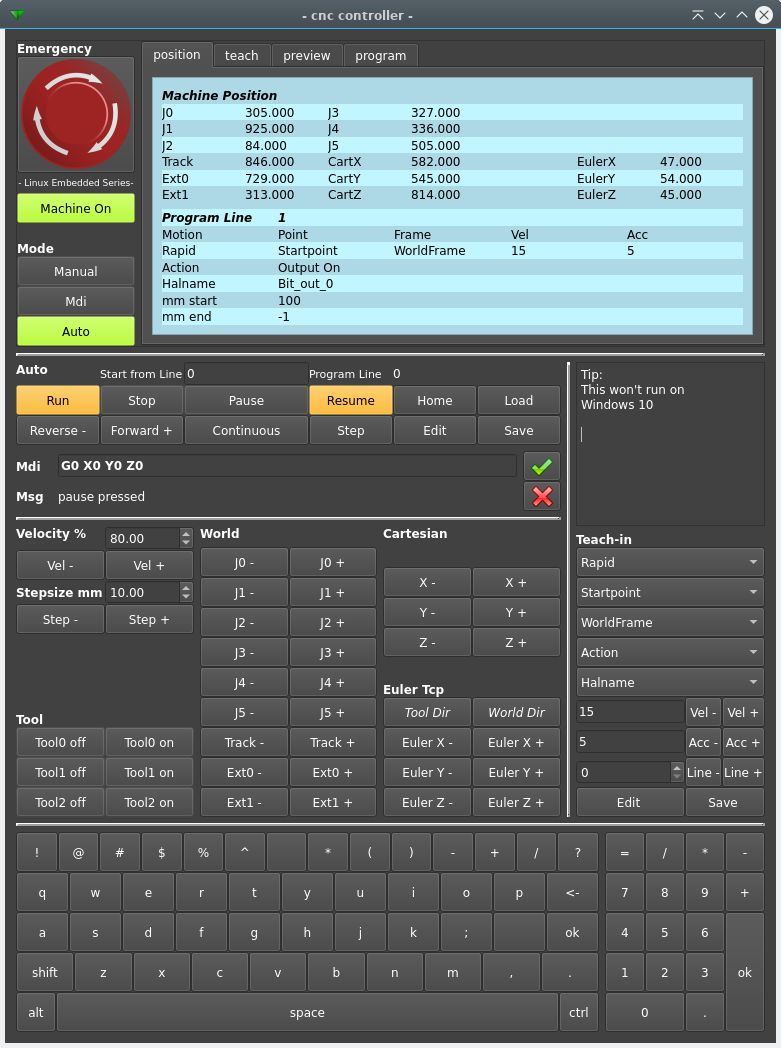
I remember this question. So far as i can see there is no need to switch between modes. All modes are active at the same time. Except moving inline with the tool oriantation. This could be a extra button to activate.
If you press X+, the robot moves along the x world frame. For y and z the same.
If you press Euler X+ the robot rotates about tool center point in direction of the world frame axis x.
If you press J0+ the robot rotates about axis 0.
You can do above sequences without selecting a mode. When pressing a button, the other values will be calculated.
Arciera, if you mean something else, maybe provide a scetch so i can understand your comments even more.
There will be coded a kdl kinematics improvement wich performs anti locking and optimalisation of robot joint positions.
Maybe 300-600 lines of code. 2 day's work.
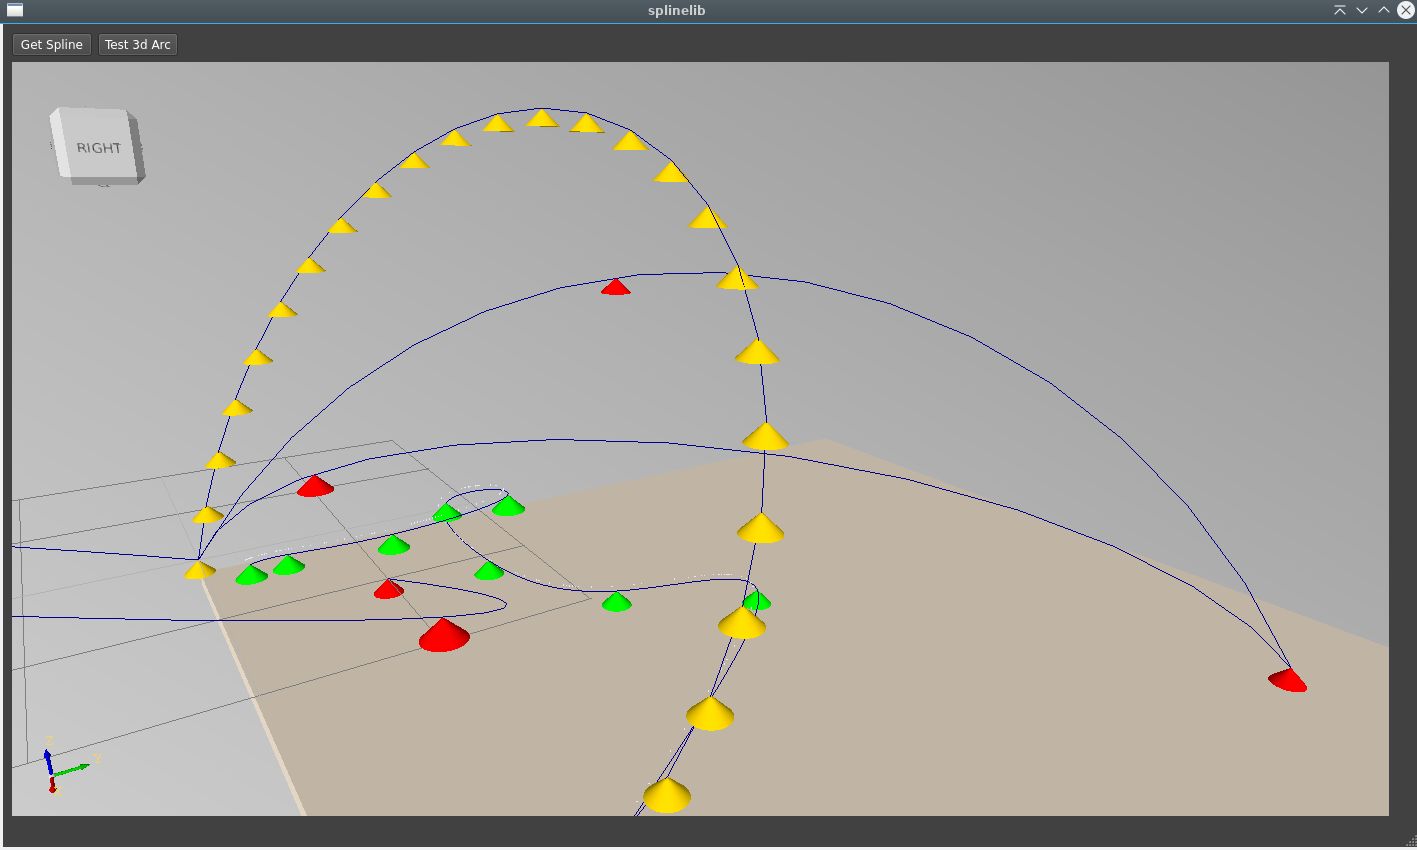
You did not see it, but the teach in function is really cool. It show your teach in path in the old screen. In fact the old screen is a
modern implementation of 3d opencascade. This widget can also show gcode etc.
For performing a gcode you can input a mdi command. What we can do is make a gcode input accelerator dialog that pop's up when
pressing the mdi line.
We need as much as idea's now. In this stage edit's are quite easy.
Impressive as usual but I have two questions:
Thank you! Coding become's easyer when you have some experience. My next programming project, will be something completely different. It will be a linux virus scanner. It's quite complex, but i did some debootstraps, chrooting, distro's (debian kali) and system.d's
to get some insights. If this suceed's maybe it can prevent something big in the future.

Or maybe not. :blink: