
- Posts: 532
- Thank you received: 327

Please Log in or Create an account to join the conversation.
It seems the code is running one ruckig per axis. Those are independent, so different axis progress with different speeds, leading to more or less arbitrary path derivations. Large enough path derivation trips the following error. This approach simply can't work even in principle.
You can use encoders for position feedback with Linuxcnc, there's a bunch of threads about it.
Yes I understand that. I have that on my mill. However that is not the issue. The problem is that for some reason the addition of the ruckig runner instances has somehow/somewhere generated a following error condition within in open stepper system. So we need to unpick where/why/how that is happening. As where things stand the code is great in the sim and dead in the water on physical kit, well specifically my phyiscal kit. Unless someone has tested this latest code line on physical kit and has it working. If so I REALLY want to see what their config setup is.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
The TP from Rob Ellenberg uses trapezoidal velocity profile, but updating position isn't the only thing that happens there that assumes constant acceleration, i.e. path blending is optimized, that optimization doesn't apply if you change speed profile.
@Rmu,
The planner Joco is tested, is the original planner written by Rob Ellenberg. Integrated are 3 ruckig runners.
The trajectory planner updates next position by a trapezium vel profile. The velocity profile of the ruckig runners is of type
scurve. So there is a difference. But the difference is tiny because of the 1ms cycle. This approach works in simulation and there is even published a video proof of it.
This approach simply can't work even in principle.
I don't agree with your statement. It's proved working.
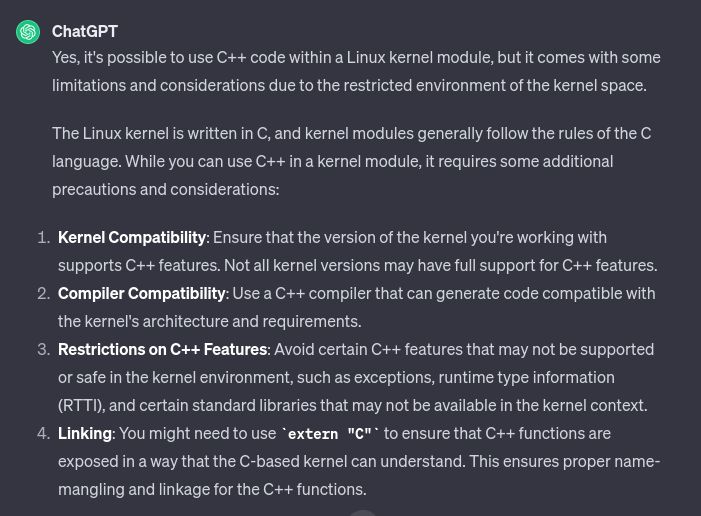
in RTAI, realtime stuff is running as kernel module, and C++ is not possible in kernel modules. Nor can you link shared libraries. Hiding the C++ stuff behind extern "C" is not enough.
I also disagree with this statement you made here.
Using c++ in kernel modules is almost my daily task.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
