Ethercat drive configuration woes

More
3 years 10 months ago #259032 by mwc
I also dug out a screen capture device.

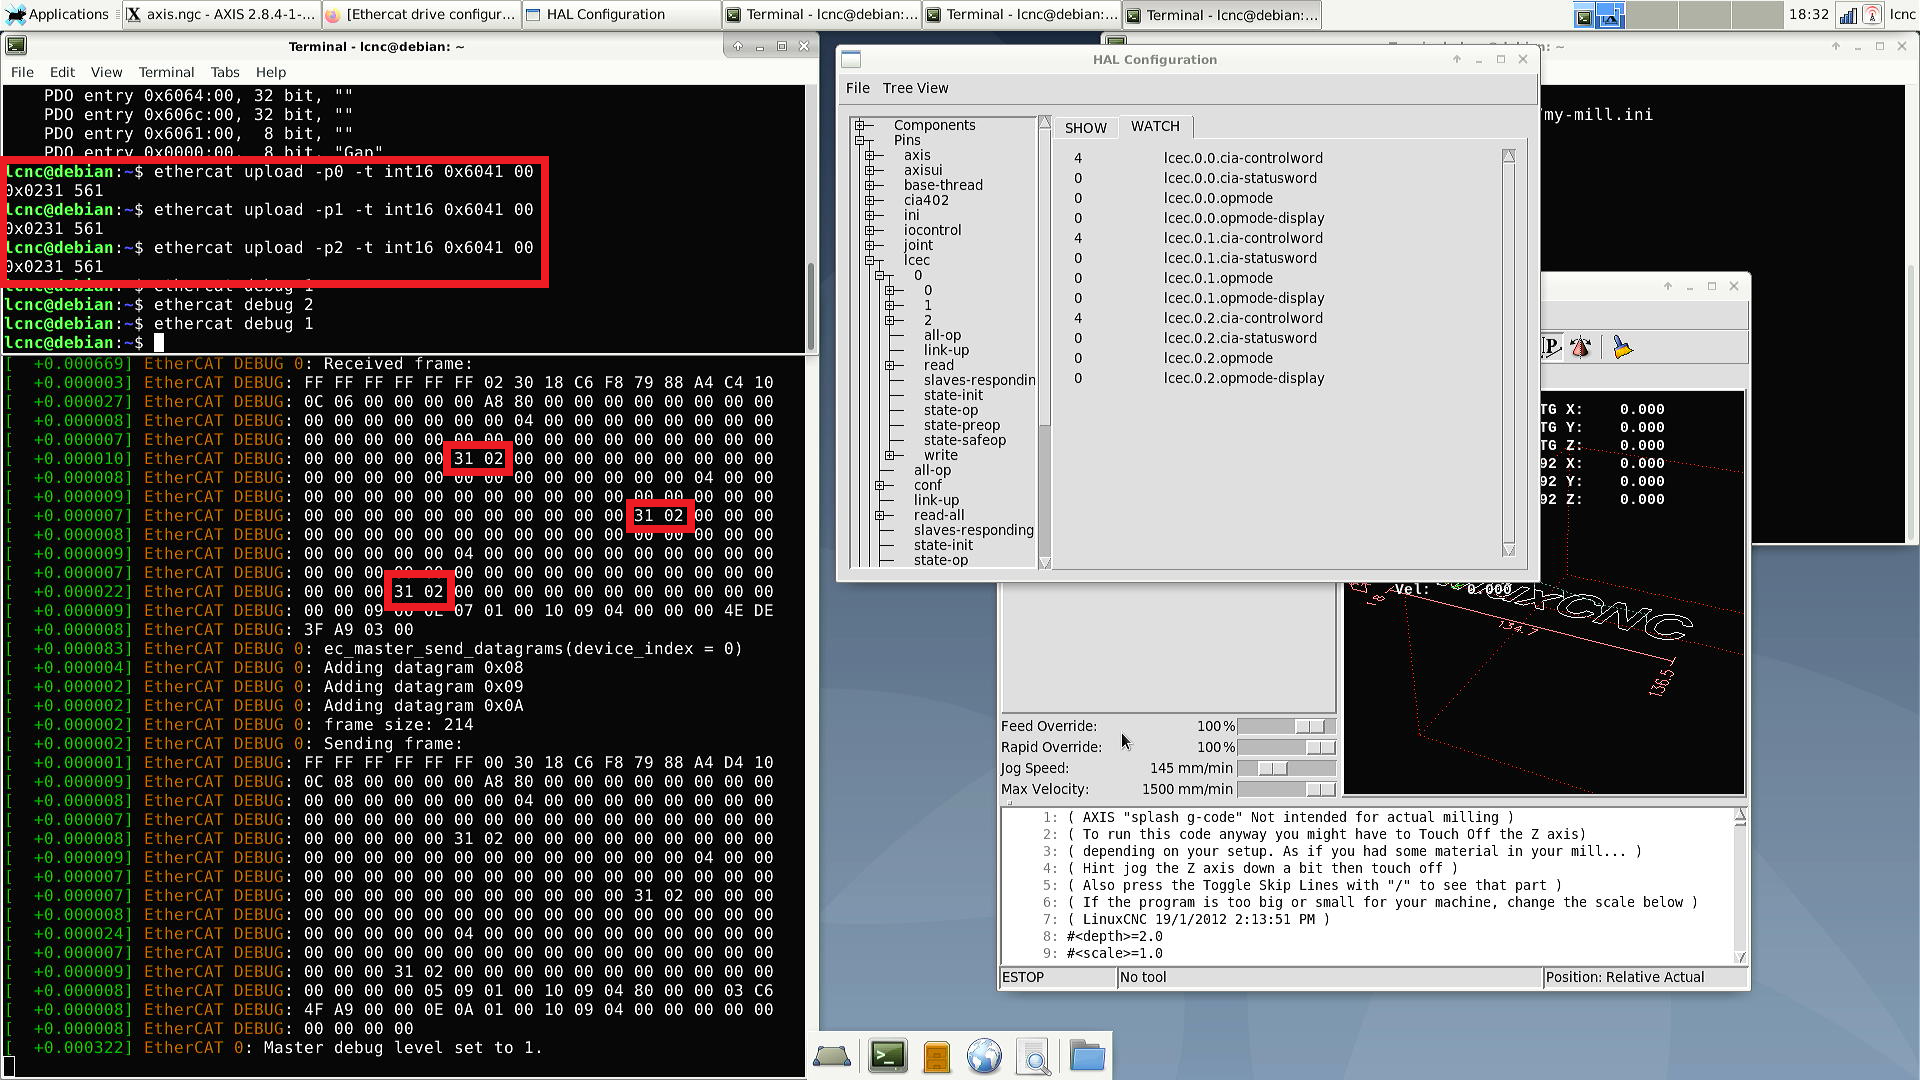
This is when LinuxCNC is loaded with the drives connected/powered on -
 
As you can see, LinuxCNC reports statusword as 0, yet a direct read via the terminal shows it as 0X0231, and the values are shown in the frame data.


And I took a screen recording of what happens if you load LinuxCNC before connecting/powering on the drives -

All values get read correctly, and the drives/motors can be enabled/moved. If you disable the drives (machine off), you can turn the motors by hand, the position is updated in LinuxCNC DROs.

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #259047 by db1981
Hmm, this is a complete new (and good) behaviour of the ethercat master.
But we don't know yet, what they also did change in the api and methods.
In normal Case lcec_conf should stop with errors...

We will have no Lcnc Projekt in the next months at work, to get time for checking this.

I would recommend, to use the "old" TAG 1.5.2 from the ethlerlab master. This is the branch linuxcnc-ethercat is coded on.


About your drive, i've never got an slave with pdos at SM0/1, this is unknown to me.
Do you get pdos at SM0/1 on all 3 drives or only at the first one.

I have noticed the EK1101 in your xml file, what happens to the drives if you place the ek as first slave in the row?
The following user(s) said Thank You: wazza77, mwc

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #259052 by mwc
I think I might leave this setup as it is for now. It's only a testing setup to try LinuxCNC and EtherCAT, although it may eventually get fitted to my little milling machine.
The real reason for testing this, is I'd like to use EtherCAT on a router that is currently a pile of metal in the workshop, but that will be using servos.


How would I change to the older ethercat master?

All drives report the same pdos.

IIRC the EK1101 came online without any issue, but I've only got an Encoder module for it (EL5xxx IIRC), and I don't have any encoders to test it just now, so I'm not sure if the values that showed in Hal config were active or not.
Although I might be able to use a linear scale on my CMM to provide an encoder...

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #259055 by wazza77
I should have my drive up and running tonight. It is on Rpi4 4gb following Hakan's guide: forum.linuxcnc.org/ethercat/42048-notes-...spberry-pi-4?start=0 , and use the etherlab master: github.com/icshwi/etherlabmaster , as recommended
I only have one drive but I also have a EK1100, with a EL1809,EL2809. of another machine that I can use while I'm waiting for the ones I ordered to arrive. I'm just at the point of making my .hal files and .xml files.

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #259180 by wazza77
I can confirm that LinuxCNC starts without the drive connected. currently can't get out of Estop but I believe I just have to change my configuration. I don't have a lot of time tonight to do testing but I will see what I can get done

Please Log in or Create an account to join the conversation.

More
3 years 10 months ago #259181 by wazza77
Ok, I am getting exactly the same behaviour if I start LinixCNC with the drive connected I get the same issue with the status word etc. if I start LinuxCNC and then connect the drive I get no problems and can jog the drive etc.

Please Log in or Create an account to join the conversation.

Time to create page: 0.241 seconds
Powered by Kunena Forum