- Configuring LinuxCNC
- Advanced Configuration
- EtherCAT
- StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler
StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler
- Muecke
-
 Topic Author
- Offline
- Platinum Member
-

Less
More
- Posts: 892
- Thank you received: 94
17 Nov 2026 14:45 #350788
by Muecke
Replied by Muecke on topic StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler
Hallo Hakan,die Installation mit Unterstützung der KI war eigentlich recht einfach. :-)Da ich bisher den IgH EtherCAT Master (EtherLab) verwendet habe, hat die KI mein System auf den EtherCAT Userspace Master v1.5 umgestellt.Dabei wurde Folgendes geändert:
/iBetriebsart: Kernel → Userspace
[*]Netzwerkanbindung: ec_r8169 → r8169 mit RAW-Übertragung
Leider gibt es bei der Einrichtung meiner beiden A6-Servotreiber noch Probleme.ecatsetup 0.21 erkennt die beiden Treiber zwar, ordnet ihnen aber nicht automatisch das CiA-402-Profil zu. Stattdessen wurden beide zunächst als „generic“ eingerichtet.Die KI hat daraufhin die gespeicherte YAML-Konfigurationsdatei manuell angepasst. Nachdem ich diese wieder geladen hatte, wurden beide Antriebe korrekt als CiA-402-Geräte angezeigt. Allerdings bekomme ich die Motoren nicht dauerhaft freigegeben. :-(Beim Versuch, die Freigabe zu aktivieren, wechseln sie teilweise kurz auf „Operation enabled“, springen aber sofort wieder zurück.Zusätzlich erscheinen im Ereignisprotokoll immer wieder EtherCAT-Kommunikationsfehler wie:Ehrlich gesagt beschäftige ich mich inzwischen seit Tagen mit den Servos und bin mittlerweile wirklich mit den Nerven am Ende. Ich bin kurz davor, das ganze Projekt in die Tonne zu treten. :-(Die passenden Bilder werde ich gleich noch hochladen. Dafür muss ich allerdings erst das System wechseln.Vielleicht wäre es einfacher, wenn wir uns direkt per E-Mail austauschen könnten?
wenn das Forum errichbar ist Dann könnte ich dir auch die Konfigurationsdateien und Protokolle zuschicken.Vielen Dank für deine Unterstützung! :-)Gruß
Mücke
/iBetriebsart: Kernel → Userspace
[*]Netzwerkanbindung: ec_r8169 → r8169 mit RAW-Übertragung
Leider gibt es bei der Einrichtung meiner beiden A6-Servotreiber noch Probleme.ecatsetup 0.21 erkennt die beiden Treiber zwar, ordnet ihnen aber nicht automatisch das CiA-402-Profil zu. Stattdessen wurden beide zunächst als „generic“ eingerichtet.Die KI hat daraufhin die gespeicherte YAML-Konfigurationsdatei manuell angepasst. Nachdem ich diese wieder geladen hatte, wurden beide Antriebe korrekt als CiA-402-Geräte angezeigt.
Allerdings bekomme ich die Motoren nicht dauerhaft freigegeben. :-(Beim Versuch, die Freigabe zu aktivieren, wechseln sie teilweise kurz auf „Operation enabled“, springen aber sofort wieder zurück.Zusätzlich erscheinen im Ereignisprotokoll immer wieder EtherCAT-Kommunikationsfehler wie:ERROR working counter zero
WARN Datagram ... was SKIPPED
WARN ... datagrams UNMATCHEDwenn das Forum errichbar ist Dann könnte ich dir auch die Konfigurationsdateien und Protokolle zuschicken.Vielen Dank für deine Unterstützung! :-)Gruß
Mücke
Please Log in or Create an account to join the conversation.
- Hakan
- Away
- Platinum Member
-
Less
More
- Posts: 1344
- Thank you received: 497
17 Nov 2026 17:46 - 17 Nov 2026 17:50 #350791
by Hakan
Replied by Hakan on topic StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler
Hi Mücke,
Thanks for the detailed report, and please don't give up: we know both problems.
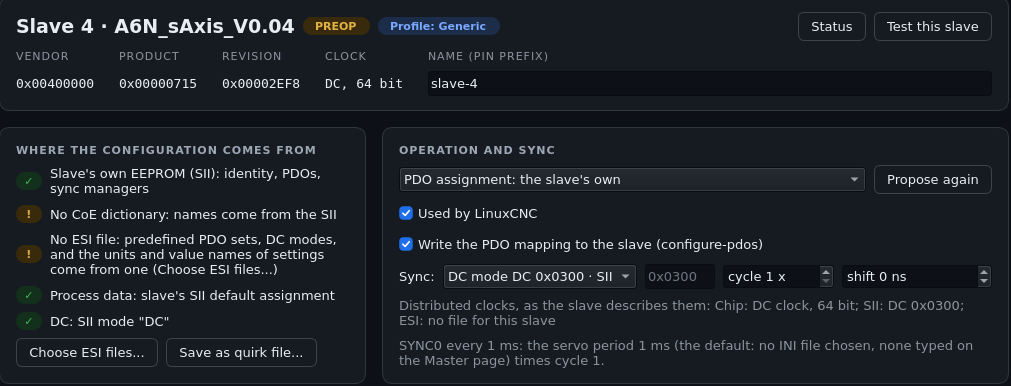
1. ecatsetup 0.21 has a bug that makes the A6 show up as "generic" and drop out right after "Operation enabled". I found and fixed it yesterday with a simulated A6. The A6's default PDOs don't contain 0x6060/0x6061, so 0.21 enabled the drive in operation mode 0. The fixed version writes the mode by SDO and checks it, and it recognises the A6 as a CiA 402 drive by itself.
2. "working counter zero / SKIPPED / UNMATCHED" means frames are being lost. On every such cycle ecat shuts the drives down for safety, so that alone is enough to keep the enable from holding.
Before I release the fix, I'd like to see your setup, so that the new version covers your problem too. Could you please send me:
- the report from ecatsetup: "Save report" in the Slave Status window, or "ecatsetup --report". If you can, make it right after a try where the enable dropped
- your ethercat.yaml and your INI file
- the output of:
systemctl is-enabled ethercat; systemctl is-active ethercat; lsmod | grep -E "ec_|r8169"; uname -a
(the old IgH master must not run any more, or two masters share the network card)
3. Check that you set DC mode 0x300, it's the only mode this drive supports.
Send the report to This email address is being protected from spambots. You need JavaScript enabled to view it. I'll delete this email address as soon as we have contact.
Thanks for the detailed report, and please don't give up: we know both problems.
1. ecatsetup 0.21 has a bug that makes the A6 show up as "generic" and drop out right after "Operation enabled". I found and fixed it yesterday with a simulated A6. The A6's default PDOs don't contain 0x6060/0x6061, so 0.21 enabled the drive in operation mode 0. The fixed version writes the mode by SDO and checks it, and it recognises the A6 as a CiA 402 drive by itself.
2. "working counter zero / SKIPPED / UNMATCHED" means frames are being lost. On every such cycle ecat shuts the drives down for safety, so that alone is enough to keep the enable from holding.
Before I release the fix, I'd like to see your setup, so that the new version covers your problem too. Could you please send me:
- the report from ecatsetup: "Save report" in the Slave Status window, or "ecatsetup --report". If you can, make it right after a try where the enable dropped
- your ethercat.yaml and your INI file
- the output of:
systemctl is-enabled ethercat; systemctl is-active ethercat; lsmod | grep -E "ec_|r8169"; uname -a
(the old IgH master must not run any more, or two masters share the network card)
3. Check that you set DC mode 0x300, it's the only mode this drive supports.
Send the report to This email address is being protected from spambots. You need JavaScript enabled to view it. I'll delete this email address as soon as we have contact.
Attachments:
Last edit: 17 Nov 2026 17:50 by Hakan.
Please Log in or Create an account to join the conversation.
- Configuring LinuxCNC
- Advanced Configuration
- EtherCAT
- StepperOnline A6 EtherCAT – Servo-Tuning unter LinuxCNC / Hoher Schleppfehler
Time to create page: 0.750 seconds