LinuxCNC-RIO - RealtimeIO for LinuxCNC based on FPGA (ICE40 / ECP5)

More
1 year 3 months ago #331438 by meister
was my mistake, normally I give a warning/error if a pin is used twice, but I had once installed that you can use input pins more than once and forgot to check if both pins are marked as input.

is fixed in dev branch
The following user(s) said Thank You: epineh

Please Log in or Create an account to join the conversation.
More
1 year 3 months ago #331440 by epineh
I still have a weird issue that I am thinking is my hardware somehow, I can connect in the test GUI, see inputs, quadrature encoders and toggle outputs, but the terminal window keeps saying received data have wrong header. I have triple checked pins for conflicts. Apart from the terminal spamming that message it seems to test OK. 
Unfortunately LinuxCNC won't get out of estop, and spams wrong header size.

I am still treating it as my hardware, going to setup a different PC, I took out the Tang Nano that is in my milling machine and flashed it but the fault persists. If not the PC, I'll start swapping out PCB's from my two working machines.

Worst part is it was all working nicely last night.

Please Log in or Create an account to join the conversation.

More
1 year 3 months ago #331441 by meister
if the testgui works, the hardware and gateware should be ok.

the c/riocomp.c must always match the gateware.
so if you have made changes to the config.json and start your LinuxCNC GUI on a different computer or from a different directory, it cannot establish a connection because the protocol no longer matches.

another reason may be that linuxcnc is trying to connect to the wrong IP.

you can look in the riocomp.c to see which ip is there:

#define UDP_IP “192.168.11.194”

and check in config.json whether UDP is really being used:

"protocol": "UDP",

Please Log in or Create an account to join the conversation.

More
1 year 3 months ago #331510 by epineh
I did a complete re-install and made sure I selected the right board starting config, and now everything works as normal. I must have accidentally started with a tangBOB starting config instead of the TangNano9K, or something along those lines, so as I was re-installing linux/checking hardware I brought the problem along with the original JSON file every time I tried fault finding.

If nothing else I can serve as a bad example !
Cheers.
Russell.

Please Log in or Create an account to join the conversation.

More
1 year 3 months ago #331685 by epineh
I've been playing with the WLED plugin, got a string of 5 led's working for various things, that is really cool.

I thought I'd try add a blink function to one of them. I see that only the WLED_Expansion allows me to assign an LED from another plugin, but when I try I get the compile error

Procedural assignment to a non register "LED_BLUE" is not permitted.

Any idea what I'm doing wrong

Please Log in or Create an account to join the conversation.

More
1 year 3 months ago #331758 by Tim Bee
Dear meister:

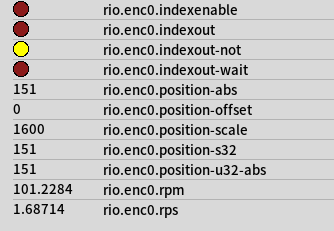
When I tested the encoder plugin I found that the indicated position seemed to be the number of revolutions. When the encoder rotated one revolution, the position increased by one number. I was sure that my scale configuration was correct because the rpm displayed the correct value. I let the motor run at 100rpm and the encoder plugin displayed about 100rpm. My encoder came from the simulated encoder of the servo motor driver.


Please Log in or Create an account to join the conversation.

Time to create page: 0.451 seconds
Powered by Kunena Forum
