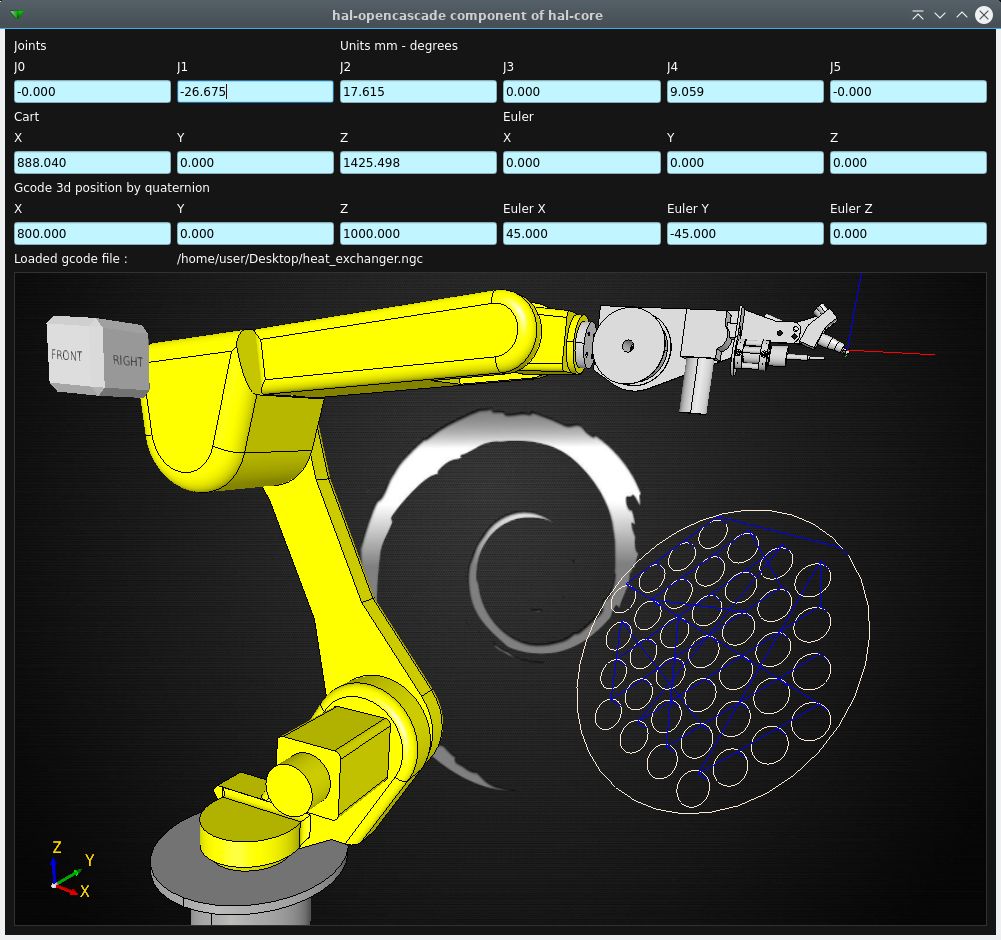
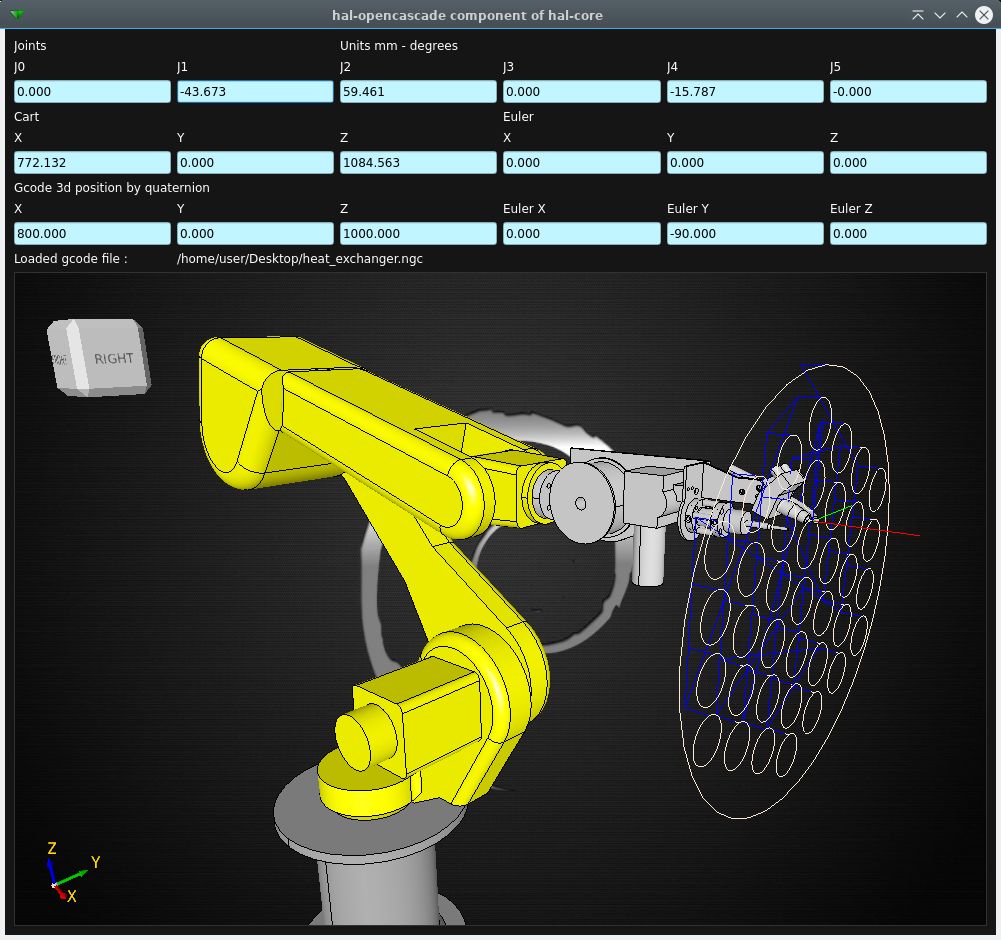
Grotius, that is looking really good!
I have some different mesa hardware that I need to wire in to the robot before I can test it. The current hardware is the 7c80 with a raspberry pi, but I had boot up power problems with that so I switched to a normal PC and an ethernet card. This will have more rendering/processing power as well.
I can bench test the boards before I wire them in the machine to simulate the motion though to keep the project on track.
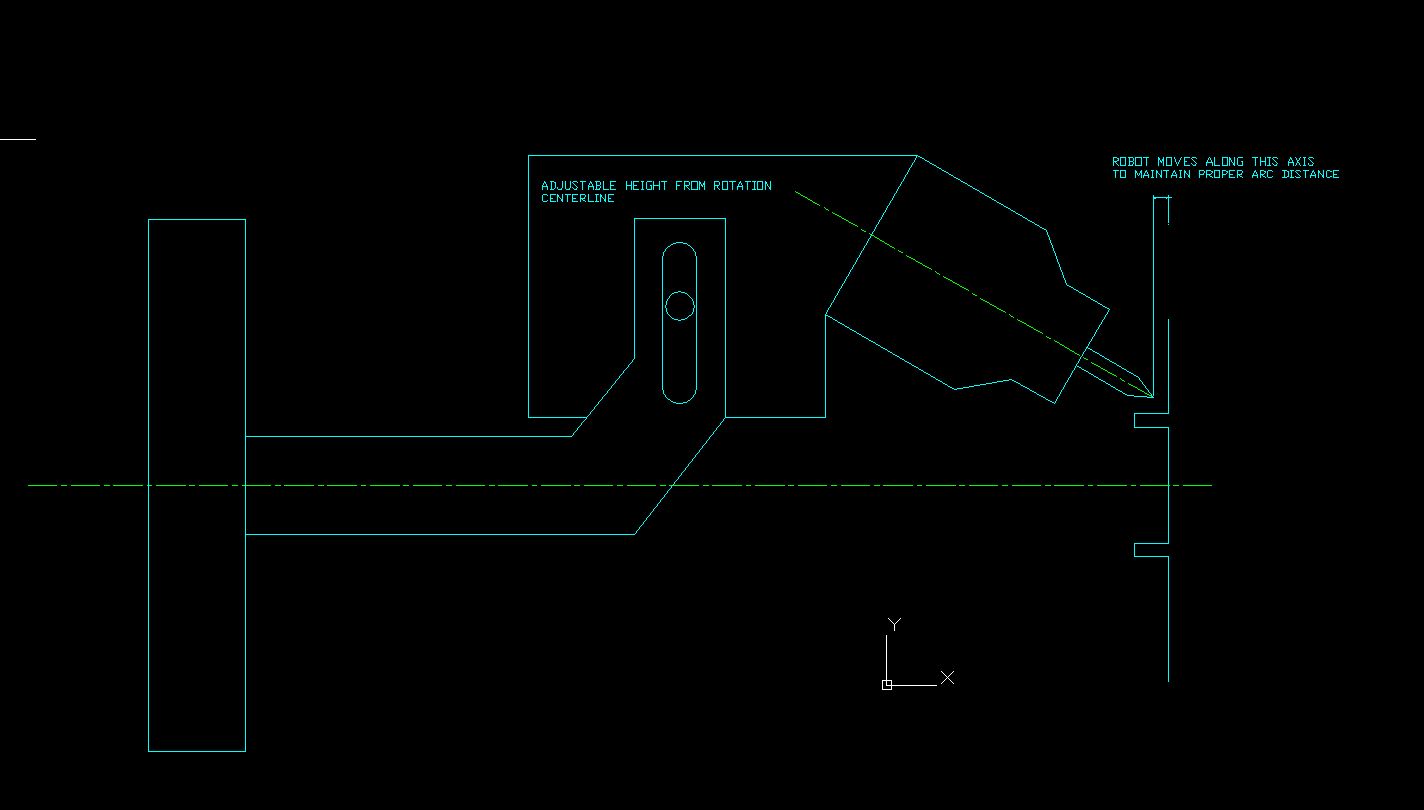
So the way I currently have the welding head setup is:
- The welding amperage is set on the welding machine
- Wire feeder is a DC motor connected to a drive to the mesa card and set with HAL
- Robot moves to the estimated hole location
- A 3D probe is used to center the welding head to the tube
- Welding feed is with the 6th axis rotation
- TIG tungsten to weld puddle distance is adjusted automatically by monitoring the arc voltage with a mesa ADC and adjusting the X position to maintain the setting
- There is also a preheat/postheat stage that strikes the arc and waits a set amount of time before the wire will start feeding in the weld and the rotation starts.
Hope that makes sense
I also have one of these wireless pendants for positioning the robot and I was thinking I might be able to use it to navigate the computer GUI instead of using a mouse/keyboard?
linuxcnc.org/docs/2.8/html/man/man1/xhc-whb04b-6.1.html