Hi guys
(ps for those that don't want to read the whole message here is a question for you... what does a torque ripple look like?)
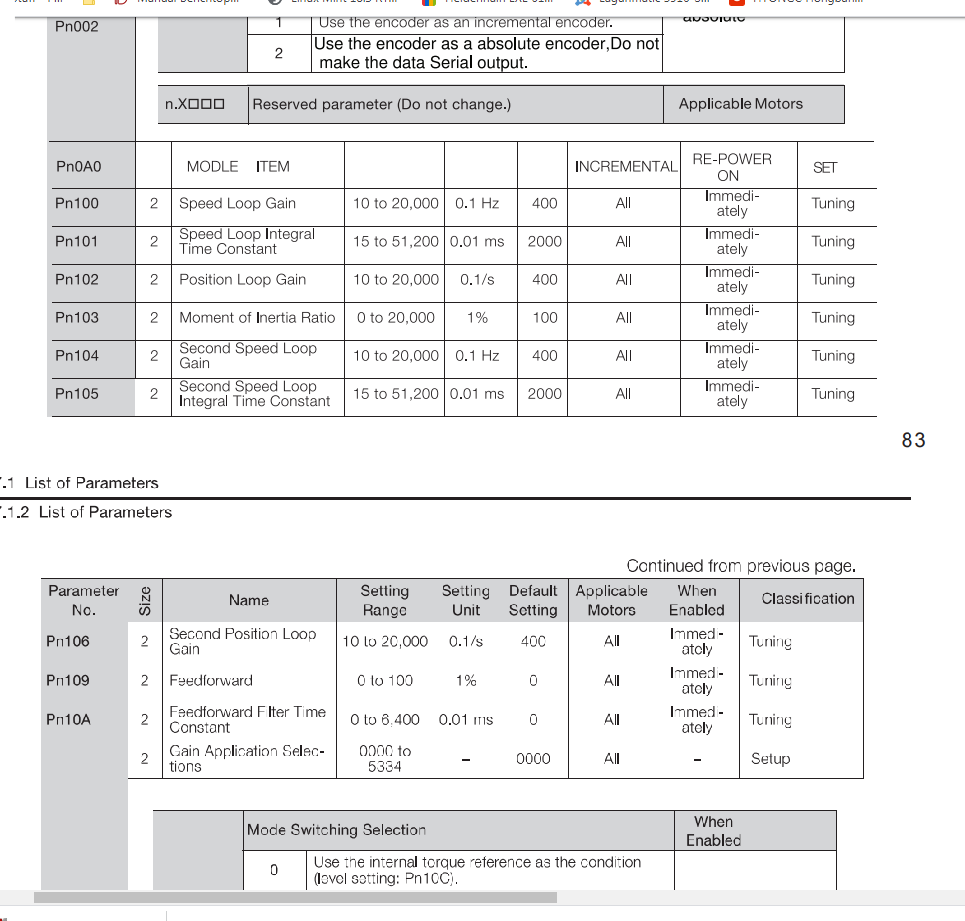
Got a update for everyone here.. I have been having some sort of success with my tuning efforts after 3 days and about 30 hrs mucking around with values haha. I am getting a feel for what works.
feed forward was a very important parameter to increase. It is at its max value of 100 percent now.
I have gotten the following error down to .03 mm at 8000mm/min rapid speed.
and at 1000mm/min feedrate the max following error is 0.0018 mm though there is a spike up to 0.005 mm at the very start.
But as the video shows I am getting a annoying noise at low speed. I am not sure what it is, but changing the tuning values doesn't seem to change it too much. I assume it is high frequency harmonics. I have tried changing the velocity gain and also tried changing the position gain but haven't had any success. also I tried changing the velocity speed intergral time constant ( I think this is the same as Intregral) changing it to all sorts of values. I haven't brought them all down together...
apart from the sound the tuning in pretty good and I am happy with it. once I close the loop properly to linuxcnc with the 7i89 encoder board I might use a little bit of (intergral) to cut down any last little errors.
On these servos I have very high ppr absolute encoders that can output a incremental encoder pulse at whatever PPR I choose. So I started at 2500 ppr then changed to 10000 ppr
and finally I have changed to 25000 ppr which the mesa card seems to handle fine. remembering that is is quadrature signals and gets multiplied by 4 in linuxcnc. so that is 1,00,000 ppr (running through a 16 mm pitch ballscrew. so divide the total ppr by 16 to get a scale of 6250 which counts fine.
I saw someones reply on the emc user list and he was running a 7000 ppr encoder at 3000 rpm so I thought so long as I stay under that I will be fine..
But the higher encoder count seemed to stop encoder dithering I think. just that last little bit of accuracy not that it is really needed but it was just a parameter lol and the resolution was there free for the taking.
Currently at 8000mm/min max rapid my machine servo motor max speed is only 500 rpm and the servo max rated rpm is 1500 rpm so I can go quite a bit higher with the rapids if I want. It seems fast enough for now though
accelerations are set at 1500 mm/s2 I think in the ini file
But this high pitch harmonics would be really nice to get rid of! I know I can turn everything down but that will stop my nice and close position loop. and am definitely a fair way away from any bad oscillations. I turned the gains up for fun and that experience was a fair bit different than this sound.
Is it possible that I have a torque ripple?
or can you suggest any ideas to reduce the noise and harmonics. I have some notch filters that I can use on the servo drive but initial testing just seems worst.
regards
Andrew