New Trajectory Planner - Testers/programs wanted

More
12 years 9 months ago #42559 by skunkworks
is there a chance we could play with your configs?

sam

Please Log in or Create an account to join the conversation.

More
12 years 9 months ago #42560 by Todd Zuercher
Maybe. What would you like me to mess with? Would you like me to post my config?

I might have a stepper machine I could play with some as well. It's Z and W axis are fixed at a close spacing, so we don't use it for double carving. We use it more like a 2 postion tool changer.

Please Log in or Create an account to join the conversation.

More
12 years 9 months ago #42568 by rellenberg
Hi Todd,
Thanks for running this test for us! It would help debugging if I could run your config in simulation. Looking at the the position log of both Z and W should reveal any issues.

Another question on a hunch: is the servo control done on dedicated hardware?

-Rob

Please Log in or Create an account to join the conversation.
More
12 years 9 months ago #42570 by Todd Zuercher
Here is my config.

Please Log in or Create an account to join the conversation.
More
12 years 9 months ago #42576 by skunkworks
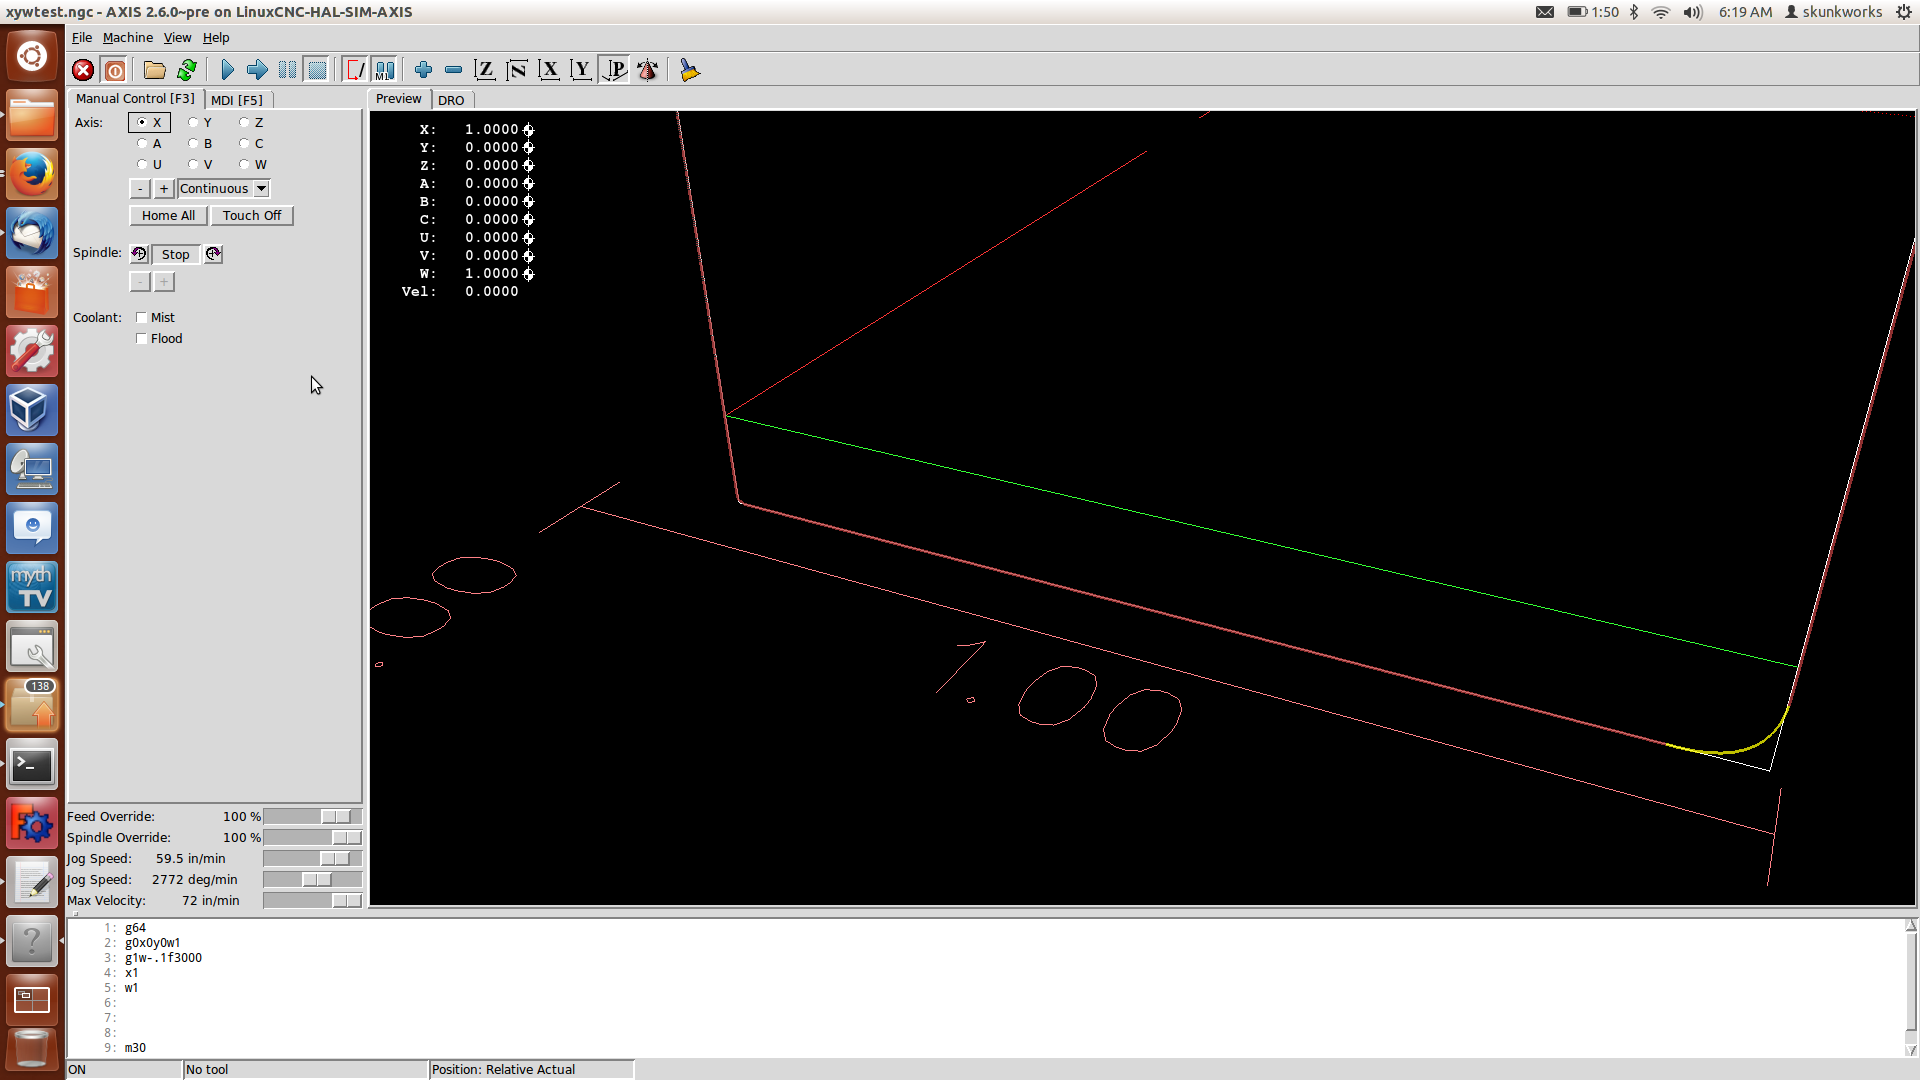
Ok -I think I am seeing it. I am using the sim axisabcxyzuvw config with the circular blends added to the ini file..

this simple program
g64
g0x0y0w1
g1w-.1f3000
x1
w1
m30

you can see in the first screen shot - the left corner isn't blended. (compared to the right) I assume this is quite a constraint violation but I have not added acc readout for the w axis yet. I assume your sytem is step/dir servos? (I could see that type of system just overshooting at the violation and recovering)

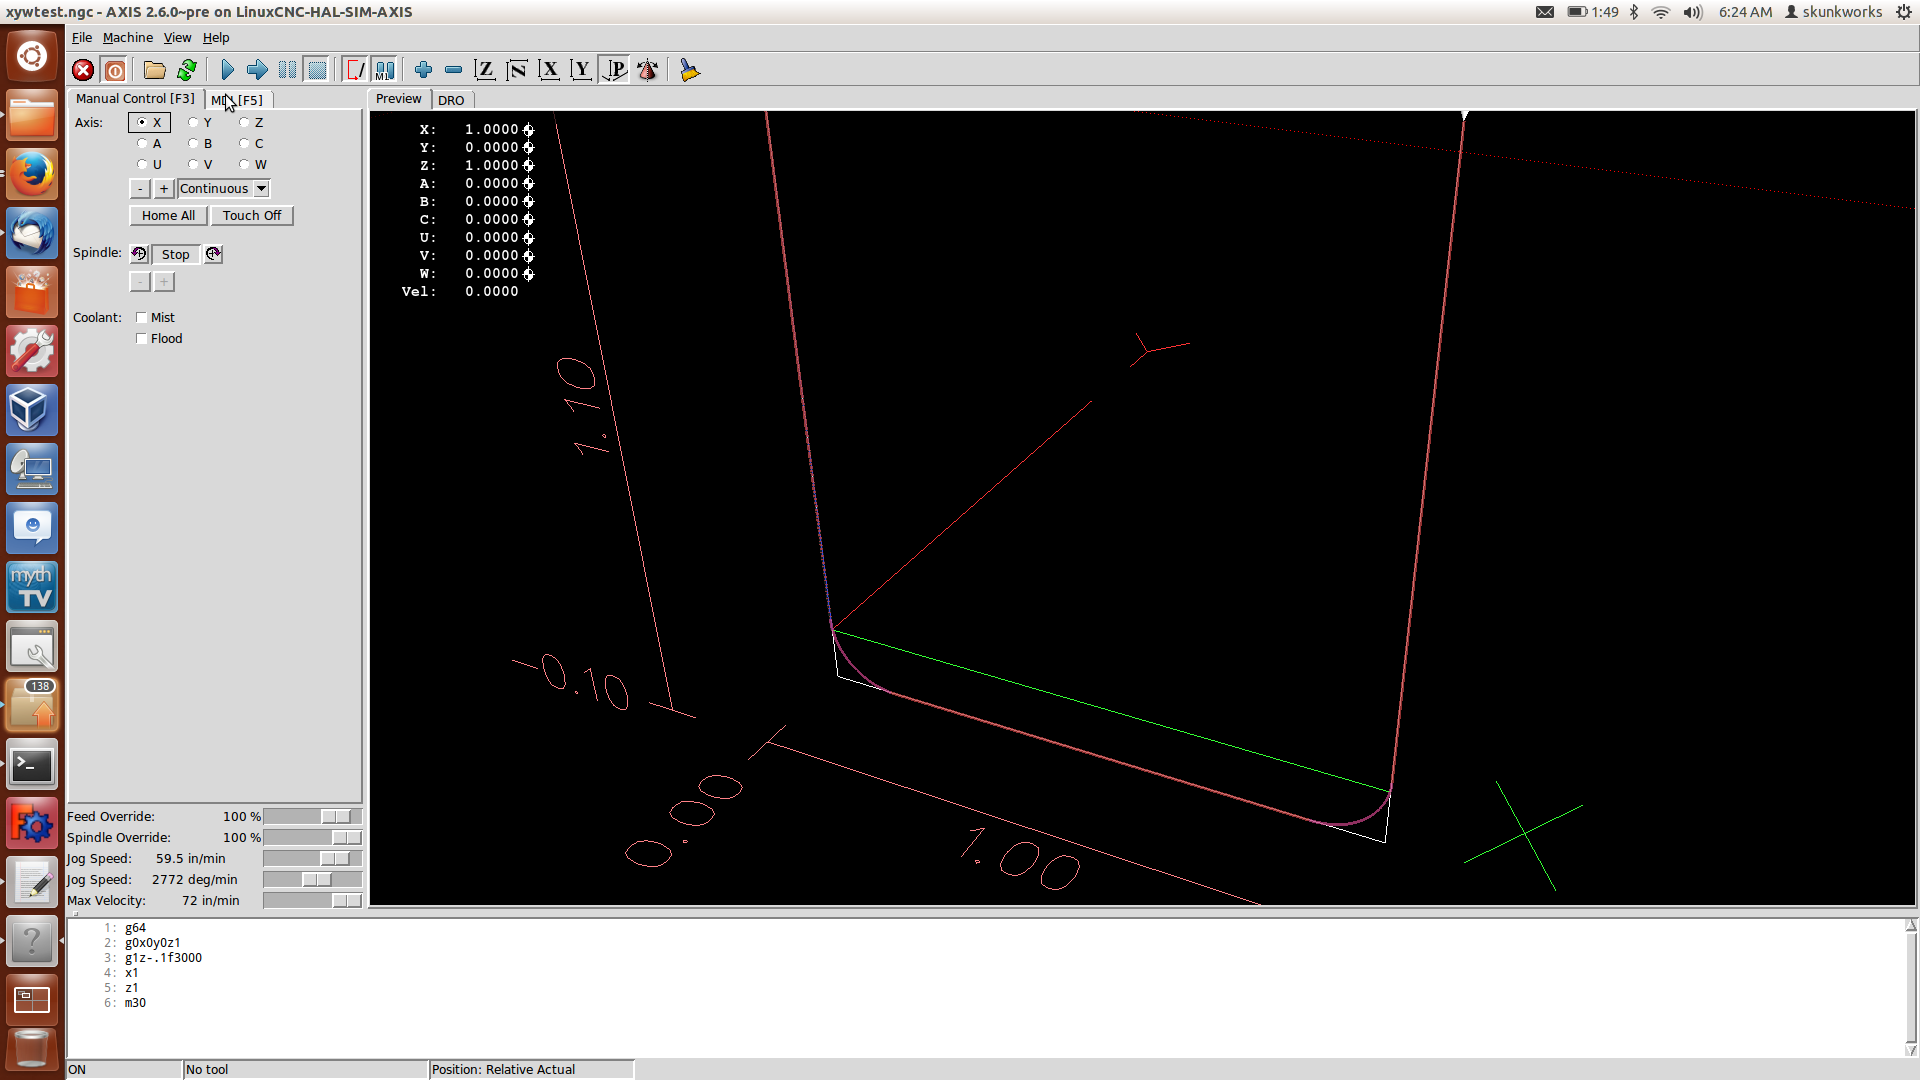
Here is the program run with z instead of w
g64
g0x0y0z1
g1z-.1f3000
x1
z1
m30

you can see it blends both the left and right corner.

sam

Please Log in or Create an account to join the conversation.

More
12 years 9 months ago #42579 by Todd Zuercher
My config is analog torque mode servo using a Mesa 5i25/7i77 combo to interface with some Teknic servo drives. So LinuxCNC is closing both the position and velocity loops. Hence why my servo period is 2.35kHz, as fast as I could get this PC to run. Wish I could have gotten it about twice as fast. I would have felt a little better about tuning it. This is the last time I will buy drives that can not do velocity input. In hinde sight I should have set this up with step dir, and encoder feed back, for digital velocity command, but I realy wanted to try setting up an analog system. I did digital on another machine with a 5i25/7i85 setup after this and it worked very nicely.

Please Log in or Create an account to join the conversation.

Time to create page: 0.147 seconds
Powered by Kunena Forum
