Hi,
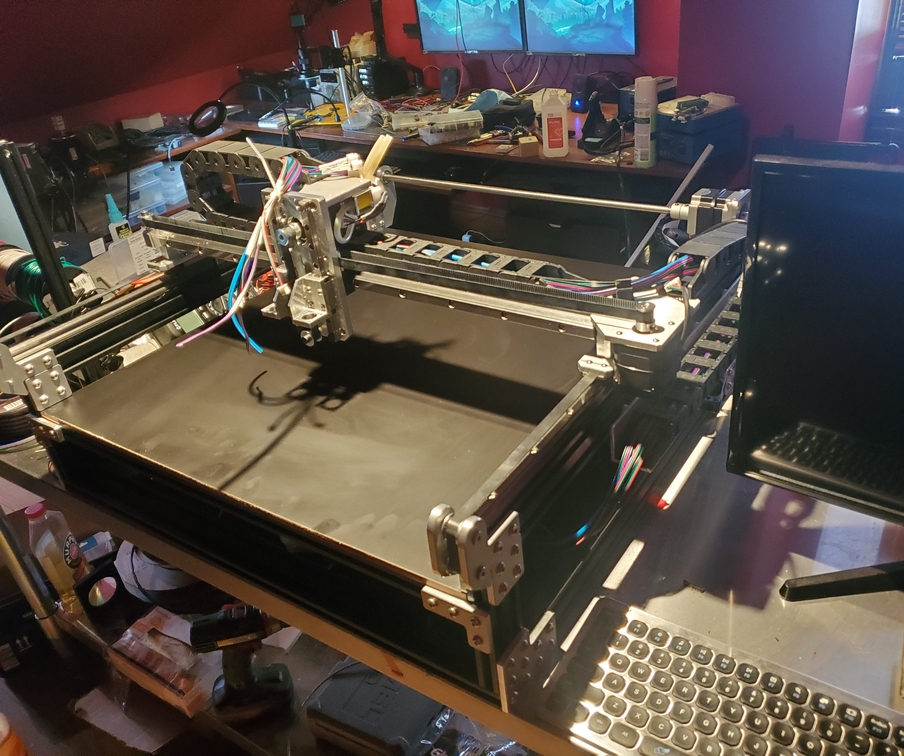
I'm working on something similar and have progressed to the point where I can get OpenPNP to successfully connect to 2x LinuxCNC machines using linuxcncrsh and move all axes (X, Y, Z x4 and C x4). My goal is to place just over 7000 LEDs (0404) on a 275mm circular LED display board and with that in mind, I will have 4x nozzles. Unlike most, I really don't like the idea of using a PC, they are really not up to sitting in dusty/dirty machine shops and the ones that are, are pretty expensive. My solution is to use a RaspberryPi (actually an BananaPi-M5, almost the identical, but currently much cheaper and available to buy!), although currently I am running LinuxCNC in simulation mode on virtual machines.
OpenPNP supports lots of nozzles, LinuxCNC however only supports 9 axes, as OpenPNP with 4 nozzles takes 8 of those axes for the nozzles alone, I have decided to split the system into 3. The first SBC (RaspberryPi or equivalent) to run OpenPNP, the second to run the X and Y axes , actuators, etc and the third to control the nozzles. Unfortunately, OpenPNP only supports one upward facing camera which means it can only orient one nozzle at a time and I really want to orient all 4 nozzles simultaneously. This is something I will have to work on, but being a programmer, should be something I can do.
I built one of the LumenPNP machines over a year ago now, I found it flimsy and slow. I wanted to attach (a now somewhat old) video of my setup, but I can't, I may upload it to YouTube later (link below). It was running off a PC/smoothie board at that time, but the movements are pretty quick. I want to go faster, but will definitely need bigger steppers and ultimately servos.
I have found that useful information on any of this is sparse and I am only too happy to help where I can.