
Mach3 -> Camtronics -> Parallel P Replacement

More
6 years 7 months ago #161733 by tommylight

rdeeming wrote: To be perfectly transparent here, I actually had to look up qtvcp.. That's how shallow my knowledge of linuxcnc is right now. :-)

You are moving slowly towards the deep end ! :)

Please Log in or Create an account to join the conversation.
More
6 years 7 months ago #161743 by PCW

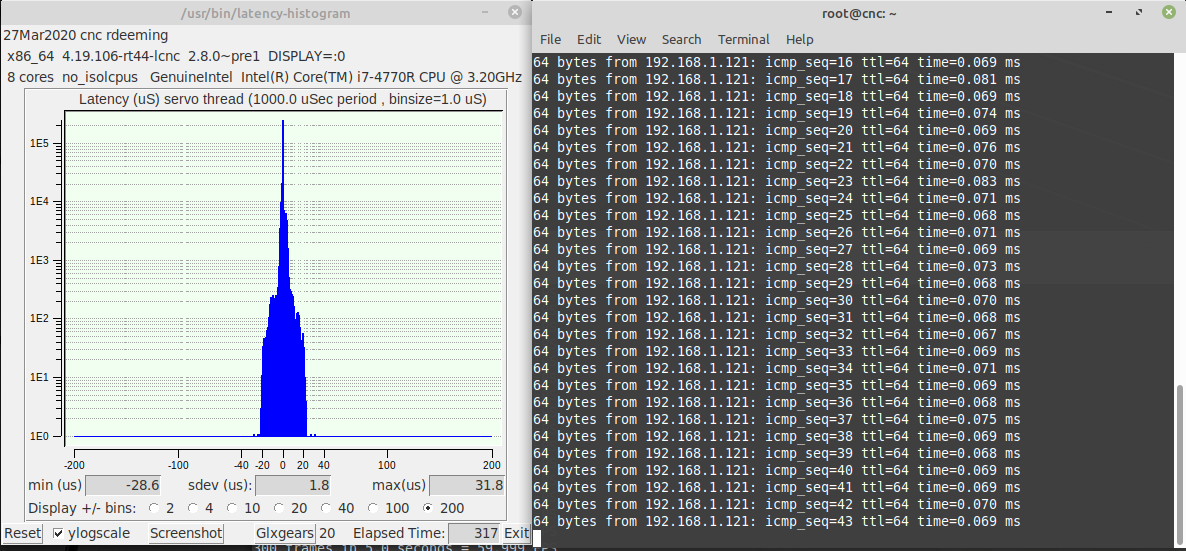
rdeeming wrote: Is what I am building on projected to be a problem down the road for a 3 axis config?


It should not really be an issue, worst case is that it cannot do a 1 KHz servo thread, but 750 0r 500 Hz is OK for most
applications

Please Log in or Create an account to join the conversation.

More
6 years 7 months ago #161745 by rdeeming
I dug another system out of the basement.

Please Log in or Create an account to join the conversation.
More
6 years 7 months ago #161752 by rdeeming

Please Log in or Create an account to join the conversation.

More
More
6 years 7 months ago #161999 by rdeeming
Currently when sending G01 X.5 F1 the X servo sits there and jitters.

Today...

I "think" my best strategy is to take the generated pncconf file and mash it to the converted working mach3 config file using stepconf.

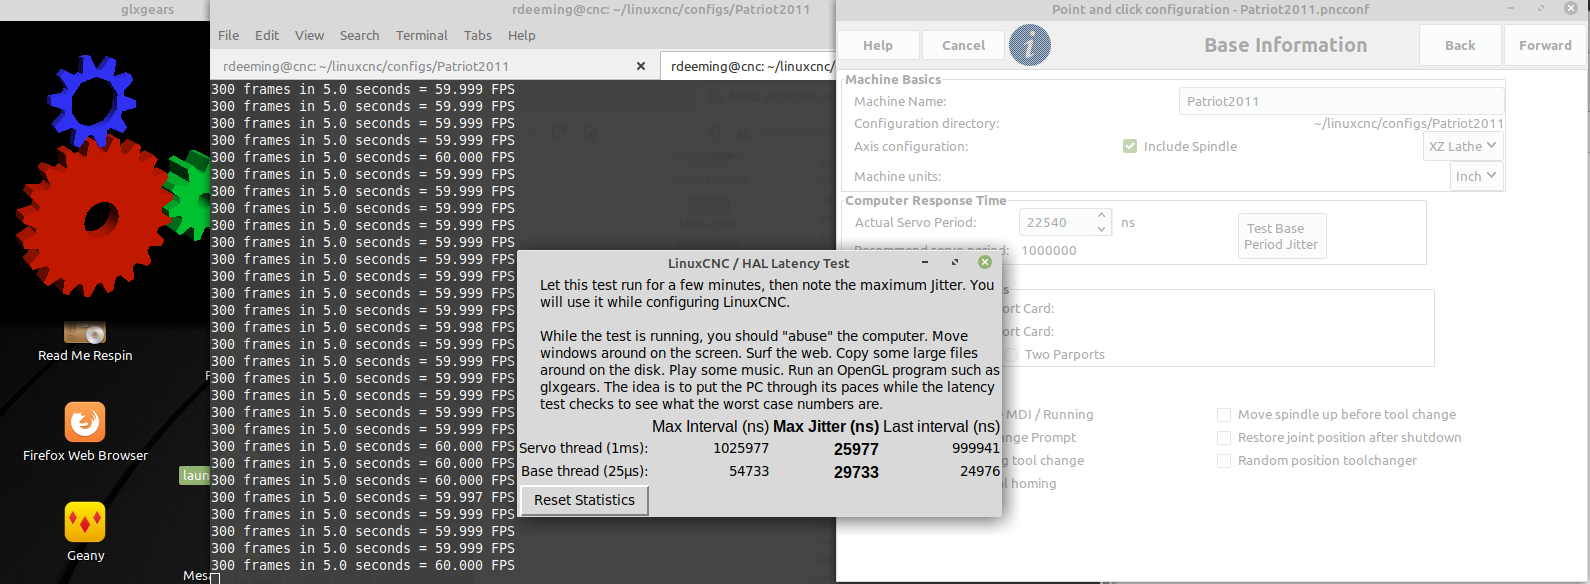
Attached are results of the hal latency test.

What number should I enter for "Actual Server Period".

Reading the LinuxCNC 2.8 HTML Stepper Configuration Wizard 4. Latency Test.
Figure 3. and what is stated below 9075 does not make sense to me.

pncconf help mentions to "choose the servo period"
The LinuxCNC / HAL Latency Test has a row "Servo thread (1ms): and the column Max Jitter in (ns)

Am I supposed to come up with a different number than 25977 for the "Actual Servo Period"?

When starting LinuxCNC it fails with that number. Setting it to the recommended 1000000 it starts with no errors.

Please Log in or Create an account to join the conversation.

Time to create page: 0.357 seconds
Powered by Kunena Forum