Replacing Advanced Motion Controls "brush type 12A8 with "Axcent" amplifier

More
6 years 3 weeks ago - 6 years 3 weeks ago #185139 by new2linux
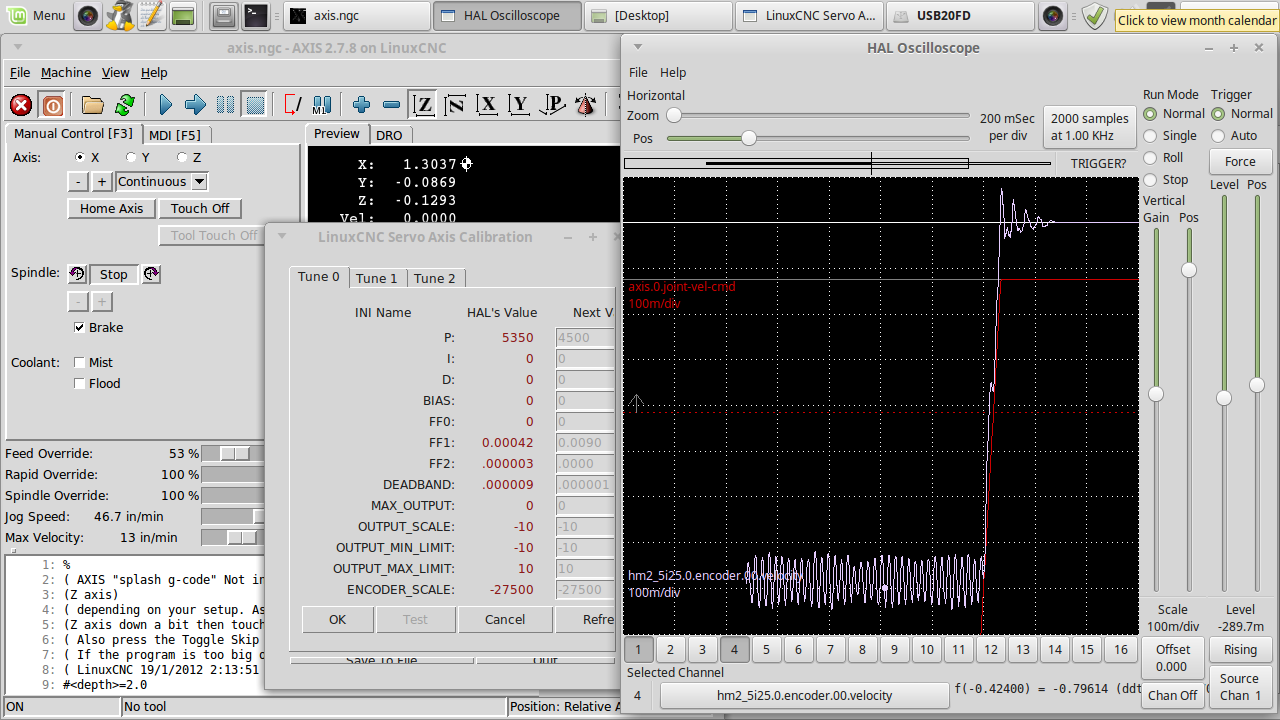
This is most recent, 46.7"/min. some how the original text from this post may not appear.

many thanks!
Last edit: 6 years 3 weeks ago by new2linux. Reason: add pic; EDIT; P=5350 Edit:Removed pic.

Please Log in or Create an account to join the conversation.

More
6 years 3 weeks ago #185237 by Todd Zuercher
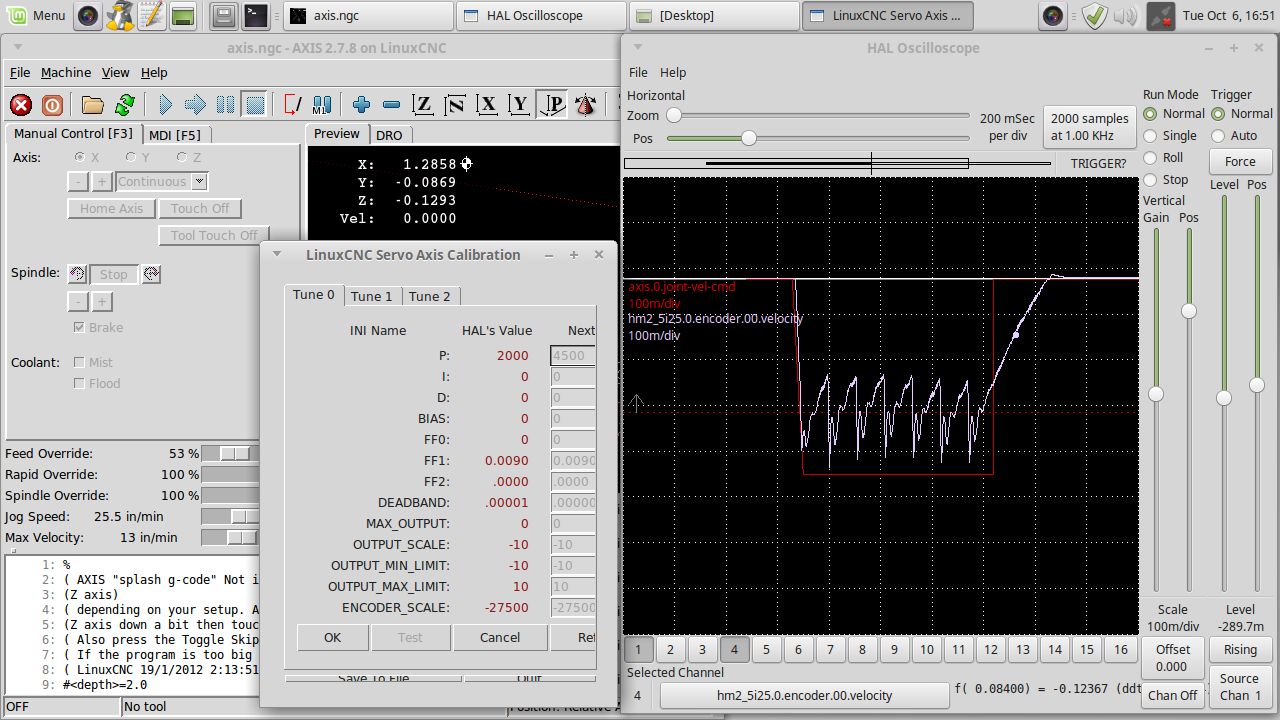
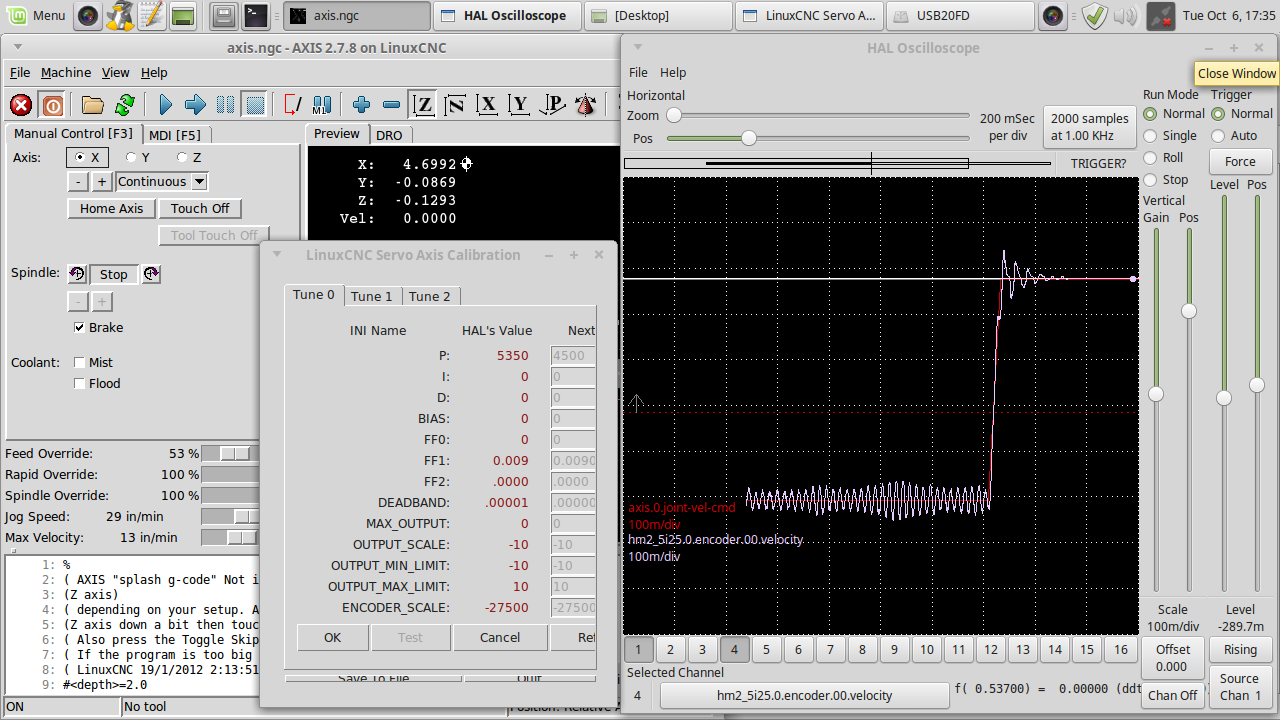
Ok, now with P set to 2000, increase the FF1 until the average velocity feedback matches the commanded velocity during the cruse part of the move.

You need to dial in the feed forwards better before cranking up the P. When the P is set very high it makes it very hard to see what the feed forward terms are doing as you tune them.

The cyclic error during cruse is a little disappointing. Can you describe the mechanics of the axis? Also the drive may need better tuning. Is the drive receiving any form of feedback from the motor for calculating velocity (tach, encoder)?
The following user(s) said Thank You: new2linux

Please Log in or Create an account to join the conversation.
More
6 years 3 weeks ago - 6 years 3 weeks ago #185257 by new2linux
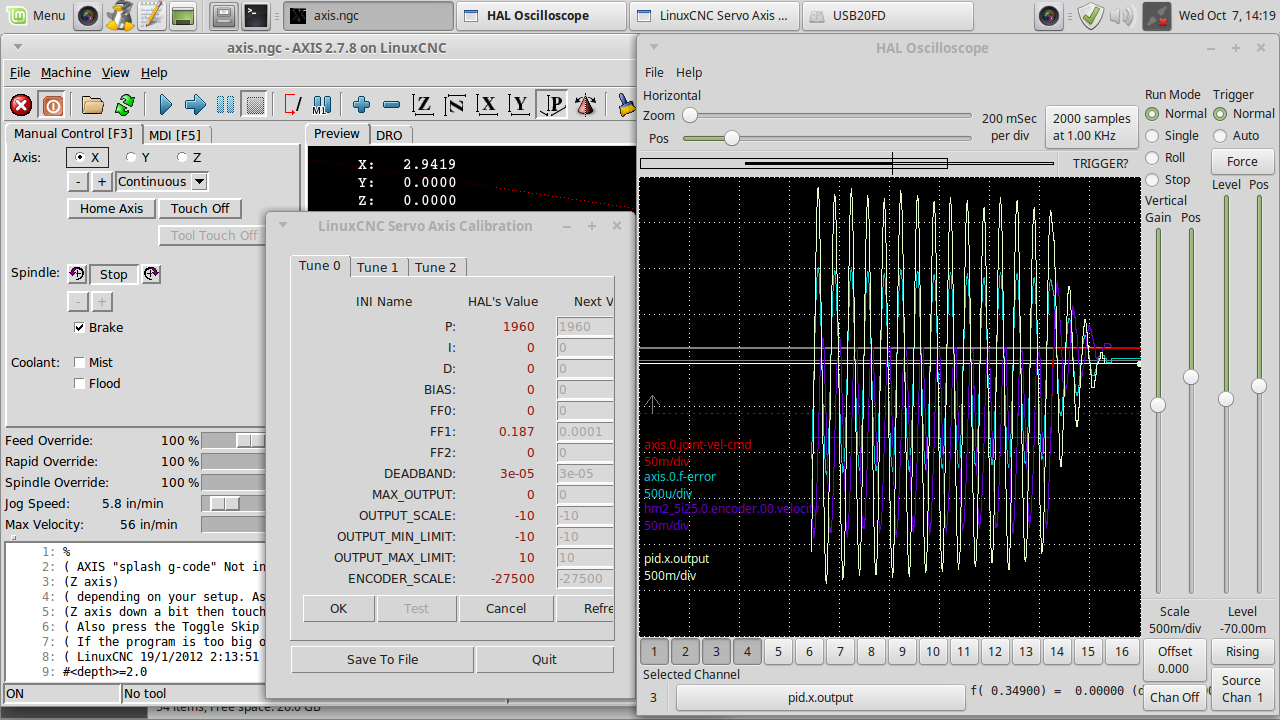
Todd, Thank you. The pic shows the setting as per prior post, need to verify is this ok. The feed is low (10"/min), if I set it higher will have joint error. This axis is the "x" axis of Bridgeport Mill. The motors have encoders (2000 count seems correct) built in. Will it help to add the other channels?

Many thanks!

Edit: When testing axis in question I only compare (or take pic) if the direction is the same (facing machine "x axis" moves to the left) as the other tests.
Last edit: 6 years 3 weeks ago by new2linux.

Please Log in or Create an account to join the conversation.

More
6 years 3 weeks ago #185263 by Todd Zuercher
Yes, showing the f-error and the PID output could be helpful.

Is the servo drive receiving any form of feedback from the motor?
The following user(s) said Thank You: new2linux

Please Log in or Create an account to join the conversation.

More
6 years 3 weeks ago - 6 years 3 weeks ago #185277 by new2linux
Todd, Many thanks. The mill is set up with encoders, the DRO works, how would I check further? The pic shows P=1960 FF1=.187; Feed 5.8"/min. There seems to be this spot in P it will work well with feed. Can't seem to get faster feed rate w/o motor jerking (lack of better term)(verizon is not working well today or yesterday, you type and then it will show up while you wait!) I did not include other channels this pic but will next time.

Edit:Please note D=8 I am reworking this now.

This is P=1960 FF1=.187; Feed 5.8"/min

Last edit: 6 years 3 weeks ago by new2linux.

Please Log in or Create an account to join the conversation.

More
6 years 3 weeks ago #185280 by tommylight

Todd Zuercher wrote:
Is the servo drive receiving any form of feedback from the motor?

This is the second time Todd is asking the same thing and never got the answer from you !!!!
The following user(s) said Thank You: new2linux

Please Log in or Create an account to join the conversation.

Time to create page: 0.121 seconds
Powered by Kunena Forum